NEET Ug . NEET Physics . Physics . System of Particles and Rotational Motion
Chapter 7: System of Particles and Rotational Motion
Ch 7
NEET Physics
NEET Ug
Introduction to Rigid Body Motion
Key Concepts
- Rigid body: Body with fixed shape; distances between particles remain constant.
- Pure translational motion: All particles move with the same velocity at any instant.
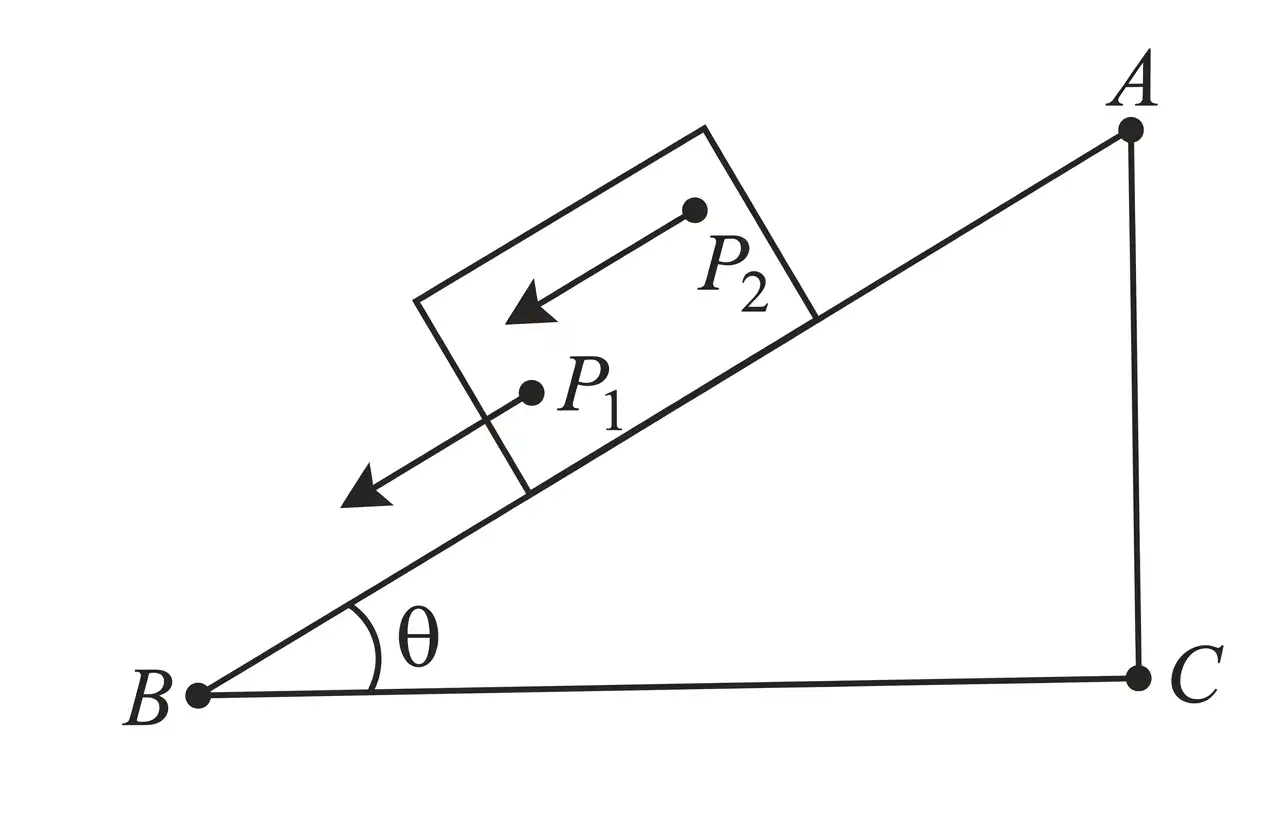
- Example: Block sliding down an inclined plane with forces P1 (gravity component) and P2 (normal force).
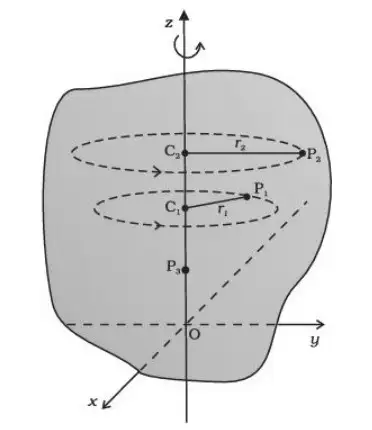
- Rotational motion: Body rotates about a fixed axis; particles move in circles perpendicular to the axis.
- Radius of rotation: Perpendicular distance of a point from the axis.
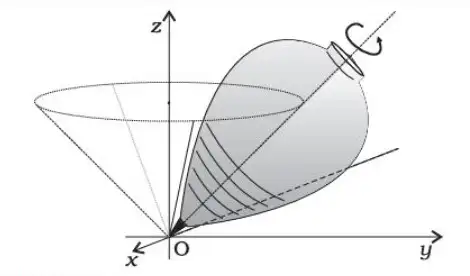
- Axis of rotation may be fixed or moving (e.g., spinning top with precession).
- Motion types: Pure translation, pure rotation (pivoted), or combination of both.
Solved Examples
Ex 1
- Block of mass 5 kg slides down an inclined plane at angle θ=30°.
- Find the component of gravitational force down the slope: P1 = mg sin θ = 5 × 9.8 × sin 30° = 24.5 N.
Ex 2
- Point P1 at radius r1=0.2 m rotates about z-axis with angular velocity ω=10, rad/s.
- Calculate linear speed: v = rω = 0.2 × 10 = 2 m/s.
Practice Set
Q1
In pure translational motion, the velocity of all particles is:
- A) Different
- B) Zero
- C) Same
- D) Varies with position
Q2
A rigid body rotates about a fixed axis. The path of each particle is:
- A) Straight line
- B) Ellipse
- C) Circle
- D) Parabola
Q3
A spinning top's axis sweeps out a cone. This motion is called:
- A) Precession
- B) Nutation
- C) Translation
- D) Rotation
Answer Key
- Q1: C - All particles have the same velocity in pure translation.
- Q2: C - Particles move in circles around the axis in rotation.
- Q3: A - The axis movement around vertical is precession.
Memory Aids
- Rigid body = fixed shape, no particle distance change.
- Translation = same velocity for all particles.
- Rotation = particles move in circles about axis.
- Precession = axis sweeps a cone (spinning top).
Key Concepts
- Rigid body: Body with fixed shape; distances between particles remain constant.
- Pure translational motion: All particles move with the same velocity at any instant.
- Example: Block sliding down an inclined plane with forces P1 (gravity component) and P2 (normal force).
- Rotational motion: Body rotates about a fixed axis; particles move in circles perpendicular to the axis.
- Radius of rotation: Perpendicular distance of a point from the axis.
- Axis of rotation may be fixed or moving (e.g., spinning top with precession).
- Motion types: Pure translation, pure rotation (pivoted), or combination of both.
Solved Examples
Ex 1
- Block of mass 5 kg slides down an inclined plane at angle θ=30°.
- Find the component of gravitational force down the slope: P1 = mg sin θ = 5 × 9.8 × sin 30° = 24.5 N.
Ex 2
- Point P1 at radius r1=0.2 m rotates about z-axis with angular velocity ω=10, rad/s.
- Calculate linear speed: v = rω = 0.2 × 10 = 2 m/s.
Practice Set
Q1
In pure translational motion, the velocity of all particles is:
- A) Different
- B) Zero
- C) Same
- D) Varies with position
Q2
A rigid body rotates about a fixed axis. The path of each particle is:
- A) Straight line
- B) Ellipse
- C) Circle
- D) Parabola
Q3
A spinning top's axis sweeps out a cone. This motion is called:
- A) Precession
- B) Nutation
- C) Translation
- D) Rotation
Answer Key
- Q1: C - All particles have the same velocity in pure translation.
- Q2: C - Particles move in circles around the axis in rotation.
- Q3: A - The axis movement around vertical is precession.
Memory Aids
- Rigid body = fixed shape, no particle distance change.
- Translation = same velocity for all particles.
- Rotation = particles move in circles about axis.
- Precession = axis sweeps a cone (spinning top).
Motion Types of Rigid Bodies
Key Concepts
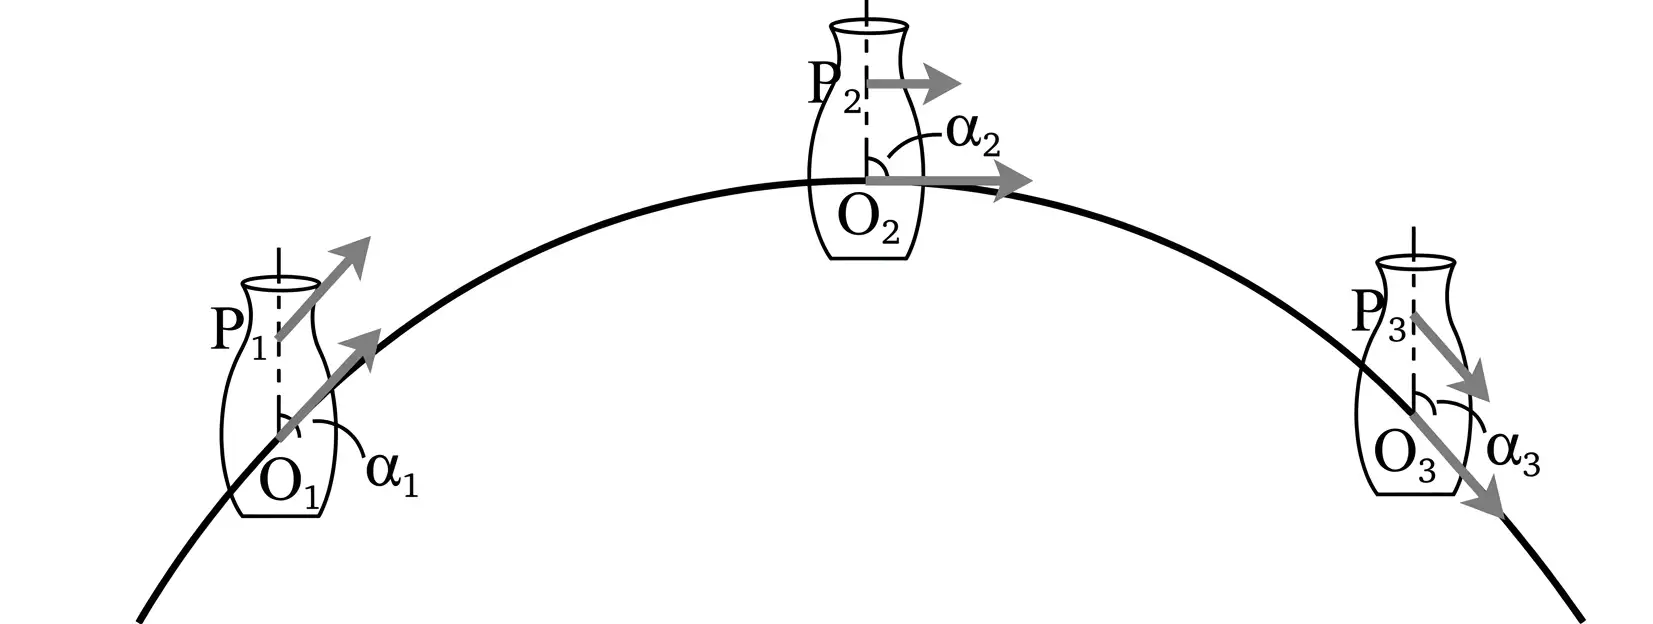
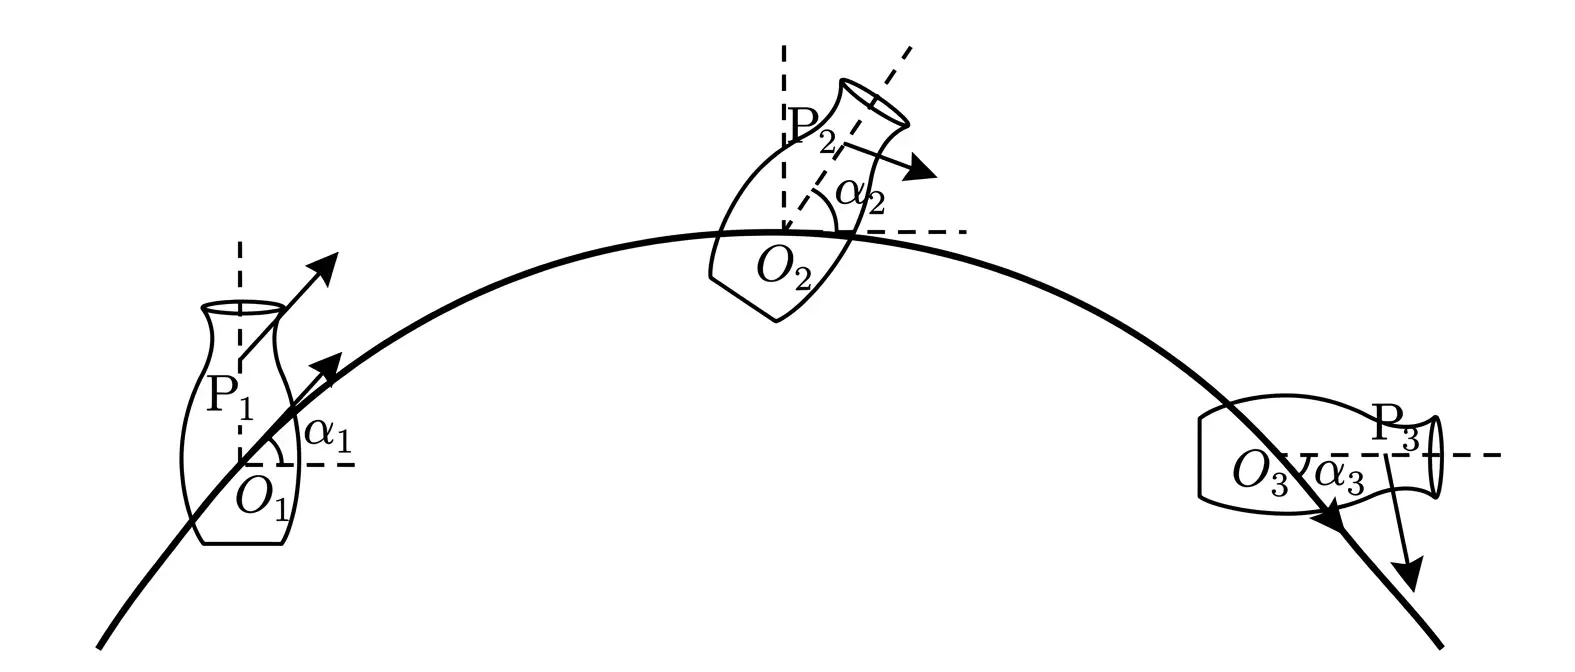
- Pure translation: All particles have same velocity v and acceleration α; α1 = α2 = α3.
- Combination of translation and rotation: Velocities and accelerations differ; α1 ≠ α2 ≠ α3.
- Pivoted/fixed rigid body motion is pure rotation.
Solved Examples
Ex 1
- Rigid body moves with pure translation: velocity of all points = 5 m/s.
- Acceleration α1 = α2 = α3 = 2 m/s2.
Ex 2
- Rigid body moves with combined motion; velocity at point O = 3 m/s, at point P = 5 m/s.
- Angles α1 ≠ α2 ≠ α3 indicate rotation plus translation.
Practice Set
Q1
In pure translational motion, acceleration of particles is:
- A) Different
- B) Zero
- C) Same
- D) Varies with position
Q2
In combined translation and rotation, velocities of points O and P are:
- A) Equal
- B) Different
- C) Zero
- D) Constant
Q3
Which motion occurs if a rigid body is pivoted?
- A) Pure translation
- B) Combination of translation and rotation
- C) Pure rotation
- D) No motion
Answer Key
- Q1: C - All particles have same acceleration in pure translation.
- Q2: B - Velocities differ in combined motion.
- Q3: C - Pivoted body undergoes pure rotation.
Memory Aids
- Pure translation: equal velocity & acceleration.
- Combined motion: different velocities & angles.
- Pivoted body = pure rotation.
Key Concepts
- Pure translation: All particles have same velocity v and acceleration α; α1 = α2 = α3.
- Combination of translation and rotation: Velocities and accelerations differ; α1 ≠ α2 ≠ α3.
- Pivoted/fixed rigid body motion is pure rotation.
Solved Examples
Ex 1
- Rigid body moves with pure translation: velocity of all points = 5 m/s.
- Acceleration α1 = α2 = α3 = 2 m/s2.
Ex 2
- Rigid body moves with combined motion; velocity at point O = 3 m/s, at point P = 5 m/s.
- Angles α1 ≠ α2 ≠ α3 indicate rotation plus translation.
Practice Set
Q1
In pure translational motion, acceleration of particles is:
- A) Different
- B) Zero
- C) Same
- D) Varies with position
Q2
In combined translation and rotation, velocities of points O and P are:
- A) Equal
- B) Different
- C) Zero
- D) Constant
Q3
Which motion occurs if a rigid body is pivoted?
- A) Pure translation
- B) Combination of translation and rotation
- C) Pure rotation
- D) No motion
Answer Key
- Q1: C - All particles have same acceleration in pure translation.
- Q2: B - Velocities differ in combined motion.
- Q3: C - Pivoted body undergoes pure rotation.
Memory Aids
- Pure translation: equal velocity & acceleration.
- Combined motion: different velocities & angles.
- Pivoted body = pure rotation.
Key Concepts
- Rigid body: Body with fixed shape; distances between particles remain constant.
- Pure translational motion: All particles move with the same velocity at any instant.
- Example: Block sliding down an inclined plane with forces P1 (gravity component) and P2 (normal force).
- Rotational motion: Body rotates about a fixed axis; particles move in circles perpendicular to the axis.
- Radius of rotation: Perpendicular distance of a point from the axis.
- Axis of rotation may be fixed or moving (e.g., spinning top with precession).
- Motion types: Pure translation, pure rotation (pivoted), or combination of both.
Solved Examples
Ex 1
- Block of mass 5 kg slides down an inclined plane at angle θ=30°.
- Find the component of gravitational force down the slope: P1 = mg sin θ = 5 × 9.8 × sin 30° = 24.5 N.
Ex 2
- Point P1 at radius r1=0.2 m rotates about z-axis with angular velocity ω=10, rad/s.
- Calculate linear speed: v = rω = 0.2 × 10 = 2 m/s.
Practice Set
Q1
In pure translational motion, the velocity of all particles is:
- A) Different
- B) Zero
- C) Same
- D) Varies with position
Q2
A rigid body rotates about a fixed axis. The path of each particle is:
- A) Straight line
- B) Ellipse
- C) Circle
- D) Parabola
Q3
A spinning top's axis sweeps out a cone. This motion is called:
- A) Precession
- B) Nutation
- C) Translation
- D) Rotation
Answer Key
- Q1: C - All particles have the same velocity in pure translation.
- Q2: C - Particles move in circles around the axis in rotation.
- Q3: A - The axis movement around vertical is precession.
Memory Aids
- Rigid body = fixed shape, no particle distance change.
- Translation = same velocity for all particles.
- Rotation = particles move in circles about axis.
- Precession = axis sweeps a cone (spinning top).
Key Concepts
- Rigid body: Body with fixed shape; distances between particles remain constant.
- Pure translational motion: All particles move with the same velocity at any instant.
- Example: Block sliding down an inclined plane with forces P1 (gravity component) and P2 (normal force).
- Rotational motion: Body rotates about a fixed axis; particles move in circles perpendicular to the axis.
- Radius of rotation: Perpendicular distance of a point from the axis.
- Axis of rotation may be fixed or moving (e.g., spinning top with precession).
- Motion types: Pure translation, pure rotation (pivoted), or combination of both.
Solved Examples
Ex 1
- Block of mass 5 kg slides down an inclined plane at angle \(\theta=30^\circ\).
- Find the component of gravitational force down the slope: \(P_1 = mg \sin \theta = 5 \times 9.8 \times \sin 30^\circ = 24.5\,\text{N}\).
Ex 2
- Point \(P_1\) at radius \(r_1=0.2\,m\) rotates about z-axis with angular velocity \(\omega=10\,\text{rad/s}\).
- Calculate linear speed: \(v = r \omega = 0.2 \times 10 = 2\,\text{m/s}\).
Practice Set
Q1
In pure translational motion, the velocity of all particles is:
- A) Different
- B) Zero
- C) Same
- D) Varies with position
Q2
A rigid body rotates about a fixed axis. The path of each particle is:
- A) Straight line
- B) Ellipse
- C) Circle
- D) Parabola
Q3
A spinning top's axis sweeps out a cone. This motion is called:
- A) Precession
- B) Nutation
- C) Translation
- D) Rotation
Answer Key
- Q1: C - All particles have the same velocity in pure translation.
- Q2: C - Particles move in circles around the axis in rotation.
- Q3: A - The axis movement around vertical is precession.
Memory Aids
- Rigid body = fixed shape, no particle distance change.
- Translation = same velocity for all particles.
- Rotation = particles move in circles about axis.
- Precession = axis sweeps a cone (spinning top).
Motion Types of Rigid Bodies
Key Concepts
- Pure translation: All particles have same velocity v and acceleration α; α1 = α2 = α3.
- Combination of translation and rotation: Velocities and accelerations differ; α1 ≠ α2 ≠ α3.
- Pivoted/fixed rigid body motion is pure rotation.
Solved Examples
Ex 1
- Rigid body moves with pure translation: velocity of all points = 5 m/s.
- Acceleration α1 = α2 = α3 = 2 m/s2.
Ex 2
- Rigid body moves with combined motion; velocity at point O = 3 m/s, at point P = 5 m/s.
- Angles α1 ≠ α2 ≠ α3 indicate rotation plus translation.
Practice Set
Q1
In pure translational motion, acceleration of particles is:
- A) Different
- B) Zero
- C) Same
- D) Varies with position
Q2
In combined translation and rotation, velocities of points O and P are:
- A) Equal
- B) Different
- C) Zero
- D) Constant
Q3
Which motion occurs if a rigid body is pivoted?
- A) Pure translation
- B) Combination of translation and rotation
- C) Pure rotation
- D) No motion
Answer Key
- Q1: C - All particles have same acceleration in pure translation.
- Q2: B - Velocities differ in combined motion.
- Q3: C - Pivoted body undergoes pure rotation.
Memory Aids
- Pure translation: equal velocity & acceleration.
- Combined motion: different velocities & angles.
- Pivoted body = pure rotation.
Key Concepts
- Pure translation: All particles have same velocity \(v\) and acceleration \(\alpha\); \(\alpha_1 = \alpha_2 = \alpha_3\).
- Combination of translation and rotation: Velocities and accelerations differ; \(\alpha_1 \neq \alpha_2 \neq \alpha_3\).
- Pivoted/fixed rigid body motion is pure rotation.
Solved Examples
Ex 1
- Rigid body moves with pure translation: velocity of all points = 5 m/s.
- Acceleration \(\alpha_1 = \alpha_2 = \alpha_3 = 2\,\text{m/s}^2\).
Ex 2
- Rigid body moves with combined motion; velocity at point O = 3 m/s, at point P = 5 m/s.
- Angles \(\alpha_1 \neq \alpha_2 \neq \alpha_3\) indicate rotation plus translation.
Practice Set
Q1
In pure translational motion, acceleration of particles is:
- A) Different
- B) Zero
- C) Same
- D) Varies with position
Q2
In combined translation and rotation, velocities of points O and P are:
- A) Equal
- B) Different
- C) Zero
- D) Constant
Q3
Which motion occurs if a rigid body is pivoted?
- A) Pure translation
- B) Combination of translation and rotation
- C) Pure rotation
- D) No motion
Answer Key
- Q1: C - All particles have same acceleration in pure translation.
- Q2: B - Velocities differ in combined motion.
- Q3: C - Pivoted body undergoes pure rotation.
Memory Aids
- Pure translation: equal velocity & acceleration.
- Combined motion: different velocities & angles.
- Pivoted body = pure rotation.
Centre of Mass
Key Concepts
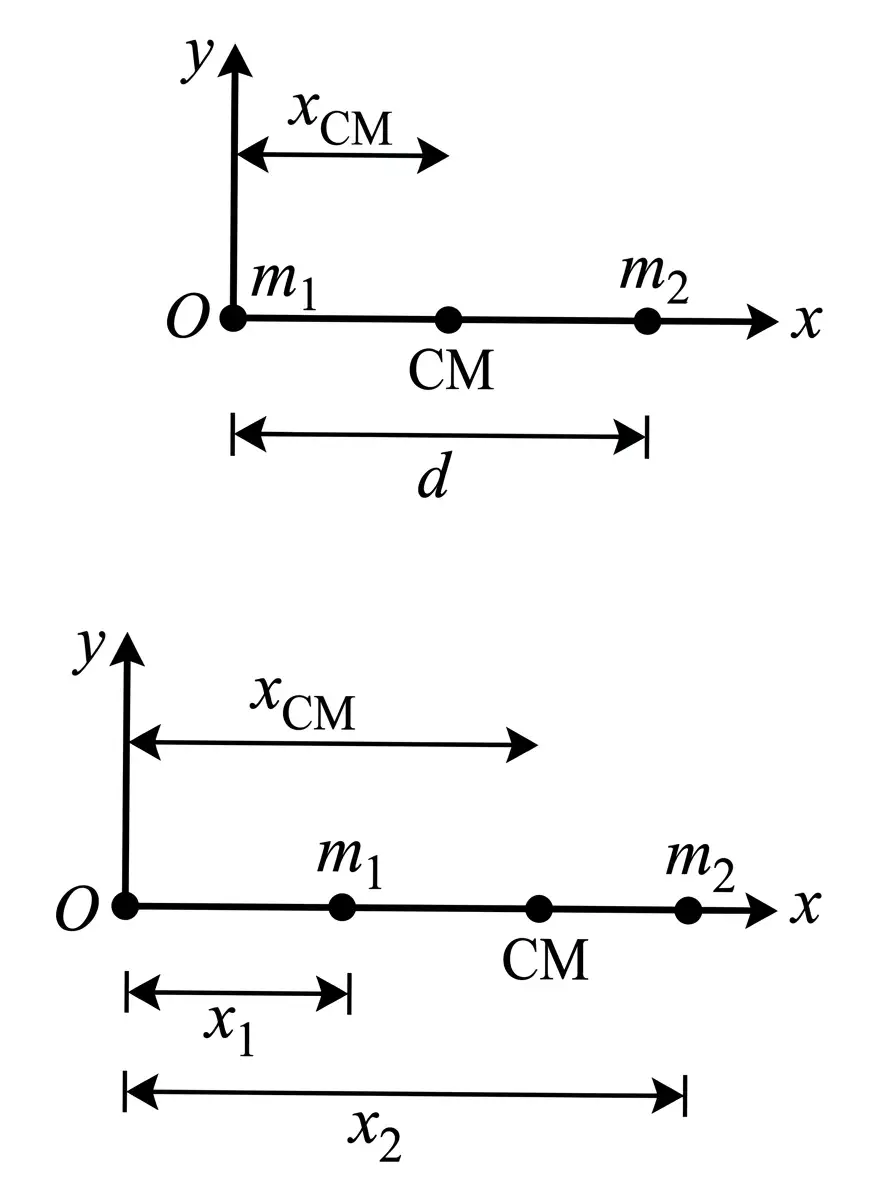
- Centre of mass (CM): Point where total mass is considered concentrated and external forces act.
- For two particles (m1, m2) separated by distance d:
- Position of CM from m1: xCM = m2/(m1 + m2) d
- General formula with coordinates x1, x2: xCM = (m1 x1 + m2 x2)/(m1 + m2)
- For n particles with masses mi and position vectors vector ri:
- vector RCM = (∑ mi vector ri)/(∑ mi) = (1/M) ∑ mi vector ri, where M = ∑ mi
- Coordinates of CM in 3D:
- xCM = (∑ mi xi)/M, yCM = (∑ mi yi)/M, zCM = (∑ mi zi)/M
- For continuous mass distribution (rigid body):
- xCM = (1/M) ∫ x , dm, yCM = (1/M) ∫ y , dm, zCM = (1/M) ∫ z , dm
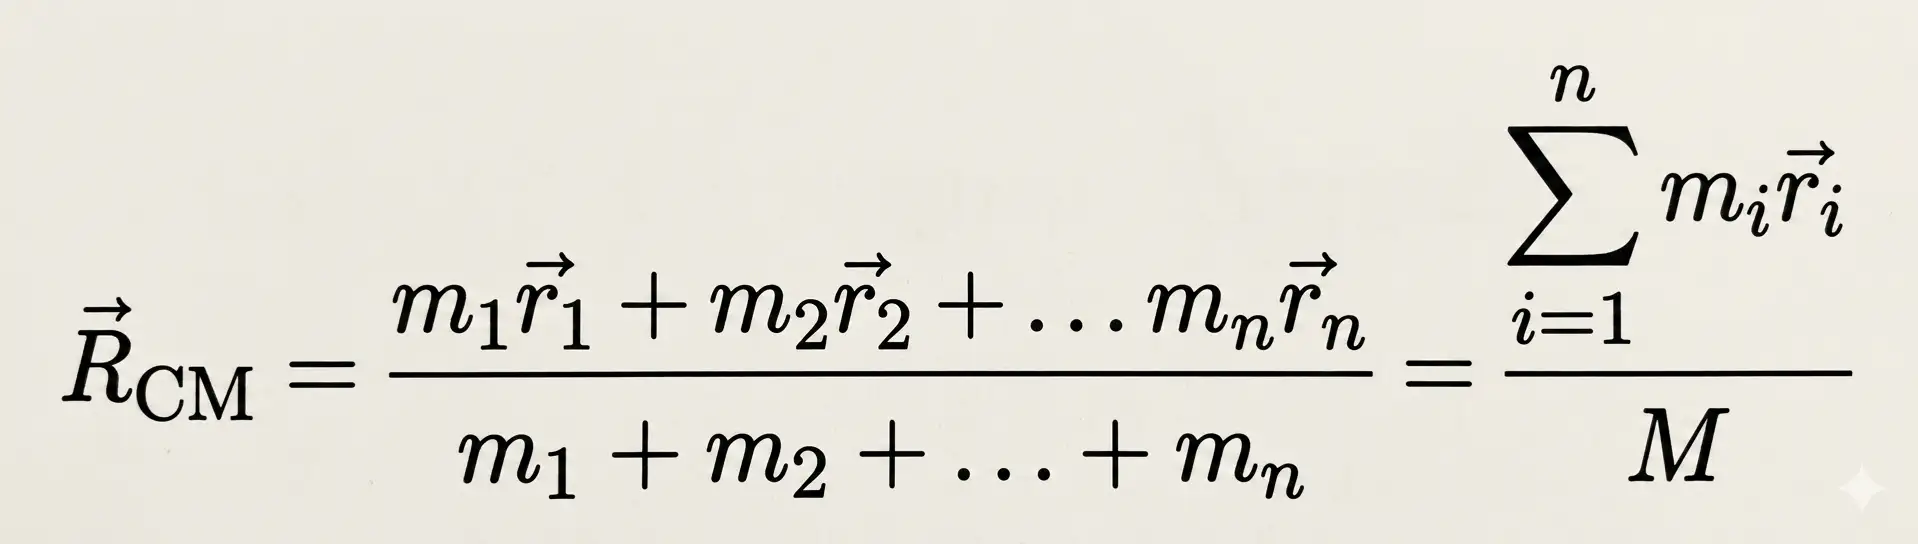
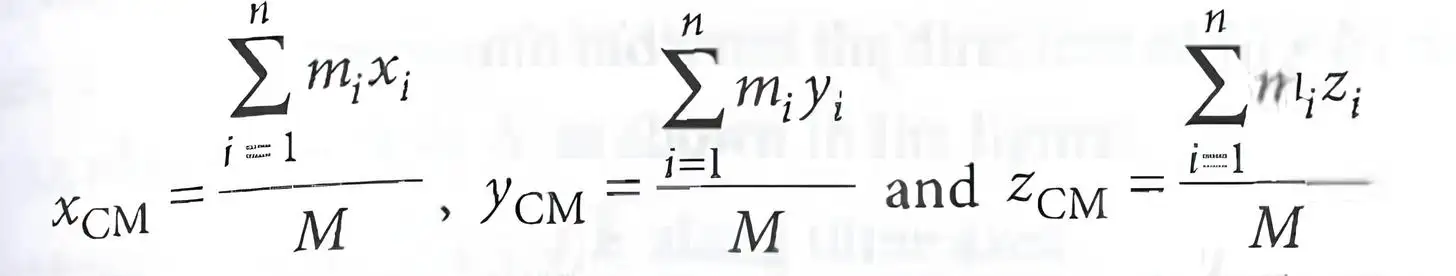
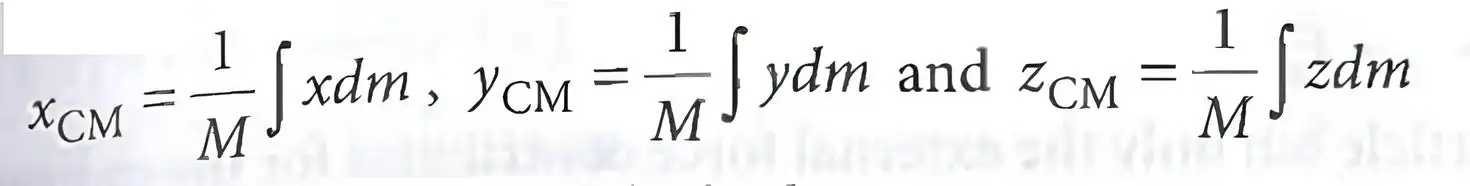
Solved Examples
Ex 1
- Two particles: m1=2 kg, m2=3 kg, distance d=5 m.
- Calculate xCM = 3/(2+3) × 5 = 3 m from m1.
Ex 2
- Three particles at x1=0, x2=4, x3=6 m with masses 1, 2, 3 kg.
- Calculate xCM = (1×0 + 2×4 + 3×6)/(1+2+3) = 26/6 = 4.33 m.
Practice Set
Q1
For two particles with masses 2 kg and 3 kg separated by 5 m, the CM from the 2 kg mass is:
- A) 2 m
- B) 3 m
- C) 4 m
- D) 5 m
Q2
In a system of particles, the position vector of CM is:
- A) (∑ vector ri)/n
- B) (∑ mi vector ri)/(∑ mi)
- C) ∑ mi vector ri
- D) (∑ mi)/(∑ vector ri)
Q3
For a continuous mass distribution, the coordinate xCM is given by:
- A) ∫ x , dm
- B) (1/M) ∫ x , dm
- C) (1/m) ∫ x , dm
- D) ∫ x , dx
Answer Key
- Q1: B - xCM = 3/5 × 5 = 3 m from 2 kg mass.
- Q2: B - Weighted average position by mass.
- Q3: B - Integral divided by total mass M.
Memory Aids
- CM = weighted average position of mass.
- Two particles: xCM = m2/(m1 + m2) d.
- n particles: vector RCM = (∑ mi vector ri)/(∑ mi).
- Continuous mass: use integrals (1/M) ∫ x , dm.
Key Concepts
- Centre of mass (CM): Point where total mass is considered concentrated and external forces act.
- For two particles (m1, m2) separated by distance d:
- Position of CM from m1: xCM = m2/(m1 + m2) d
- General formula with coordinates x1, x2: xCM = (m1 x1 + m2 x2)/(m1 + m2)
- For n particles with masses mi and position vectors vector ri:
- vector RCM = (∑ mi vector ri)/(∑ mi) = (1/M) ∑ mi vector ri, where M = ∑ mi
- Coordinates of CM in 3D:
- xCM = (∑ mi xi)/M, yCM = (∑ mi yi)/M, zCM = (∑ mi zi)/M
- For continuous mass distribution (rigid body):
- xCM = (1/M) ∫ x , dm, yCM = (1/M) ∫ y , dm, zCM = (1/M) ∫ z , dm
Solved Examples
Ex 1
- Two particles: m1=2 kg, m2=3 kg, distance d=5 m.
- Calculate xCM = 3/(2+3) × 5 = 3 m from m1.
Ex 2
- Three particles at x1=0, x2=4, x3=6 m with masses 1, 2, 3 kg.
- Calculate xCM = (1×0 + 2×4 + 3×6)/(1+2+3) = 26/6 = 4.33 m.
Practice Set
Q1
For two particles with masses 2 kg and 3 kg separated by 5 m, the CM from the 2 kg mass is:
- A) 2 m
- B) 3 m
- C) 4 m
- D) 5 m
Q2
In a system of particles, the position vector of CM is:
- A) (∑ vector ri)/n
- B) (∑ mi vector ri)/(∑ mi)
- C) ∑ mi vector ri
- D) (∑ mi)/(∑ vector ri)
Q3
For a continuous mass distribution, the coordinate xCM is given by:
- A) ∫ x , dm
- B) (1/M) ∫ x , dm
- C) (1/m) ∫ x , dm
- D) ∫ x , dx
Answer Key
- Q1: B - xCM = 3/5 × 5 = 3 m from 2 kg mass.
- Q2: B - Weighted average position by mass.
- Q3: B - Integral divided by total mass M.
Memory Aids
- CM = weighted average position of mass.
- Two particles: xCM = m2/(m1 + m2) d.
- n particles: vector RCM = (∑ mi vector ri)/(∑ mi).
- Continuous mass: use integrals (1/M) ∫ x , dm.
Key Concepts
- Centre of mass (CM): Point where total mass is considered concentrated and external forces act.
- For two particles (m1, m2) separated by distance \(d\):
- Position of CM from m1: \(x_{CM} = \frac{m_2}{m_1 + m_2} d\)
- General formula with coordinates \(x_1, x_2\): \(x_{CM} = \frac{m_1 x_1 + m_2 x_2}{m_1 + m_2}\)
- For n particles with masses \(m_i\) and position vectors \(\vec{r}_i\):
- \(\vec{R}_{CM} = \frac{\sum m_i \vec{r}_i}{\sum m_i} = \frac{1}{M} \sum m_i \vec{r}_i\), where \(M = \sum m_i\)
- Coordinates of CM in 3D:
- \(x_{CM} = \frac{\sum m_i x_i}{M}, y_{CM} = \frac{\sum m_i y_i}{M}, z_{CM} = \frac{\sum m_i z_i}{M}\)
- For continuous mass distribution (rigid body):
- \(x_{CM} = \frac{1}{M} \int x \, dm, y_{CM} = \frac{1}{M} \int y \, dm, z_{CM} = \frac{1}{M} \int z \, dm\)
Solved Examples
Ex 1
- Two particles: \(m_1=2\,kg\), \(m_2=3\,kg\), distance \(d=5\,m\).
- Calculate \(x_{CM} = \frac{3}{2+3} \times 5 = 3\,m\) from \(m_1\).
Ex 2
- Three particles at \(x_1=0\), \(x_2=4\), \(x_3=6\) m with masses 1, 2, 3 kg.
- Calculate \(x_{CM} = \frac{1\times0 + 2\times4 + 3\times6}{1+2+3} = \frac{26}{6} = 4.33\,m\).
Practice Set
Q1
For two particles with masses 2 kg and 3 kg separated by 5 m, the CM from the 2 kg mass is:
- A) 2 m
- B) 3 m
- C) 4 m
- D) 5 m
Q2
In a system of particles, the position vector of CM is:
- A) \(\frac{\sum \vec{r}_i}{n}\)
- B) \(\frac{\sum m_i \vec{r}_i}{\sum m_i}\)
- C) \(\sum m_i \vec{r}_i\)
- D) \(\frac{\sum m_i}{\sum \vec{r}_i}\)
Q3
For a continuous mass distribution, the coordinate \(x_{CM}\) is given by:
- A) \(\int x \, dm\)
- B) \(\frac{1}{M} \int x \, dm\)
- C) \(\frac{1}{m} \int x \, dm\)
- D) \(\int x \, dx\)
Answer Key
- Q1: B - \(x_{CM} = \frac{3}{5} \times 5 = 3\,m\) from 2 kg mass.
- Q2: B - Weighted average position by mass.
- Q3: B - Integral divided by total mass \(M\).
Memory Aids
- CM = weighted average position of mass.
- Two particles: \(x_{CM} = \frac{m_2}{m_1 + m_2} d\).
- n particles: \(\vec{R}_{CM} = \frac{\sum m_i \vec{r}_i}{\sum m_i}\).
- Continuous mass: use integrals \(\frac{1}{M} \int x \, dm\).
Motion of Centre of Mass
Definition and Formula
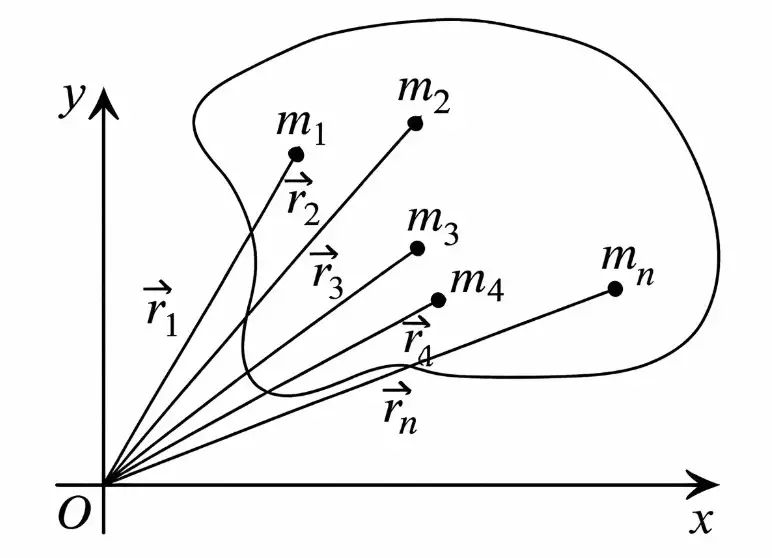
- Consider a system of n particles with masses m1, m2, ..., mn.
- Position vectors of particles are vector r1, vector r2, ..., vector rn.
- Position vector of centre of mass (CM) is vector R.
- Formula: Mvector R = m1vector r1 + m2vector r2 + ... + mnvector rn, where M = ∑ mi.
- Differentiating w.r.t time gives velocity relation: Mvector VCM = m1vector v1 + m2vector v2 + ... + mnvector vn.
- Acceleration relation: Mvector ACM = m1vector a1 + m2vector a2 + ... + mnvector an.
- Newton's 2nd law for CM: Mvector ACM = vector Fext (only external forces affect CM motion).
- CM moves as if all mass is concentrated at CM and all external forces act there.
Solved Examples
- Ex 1: Find vector R for two particles m1=2 kg at vector r1=3î m and m2=3 kg at vector r2=5î m.
- Use vector R = (m1vector r1 + m2vector r2)/(m1 + m2) = (2×3 + 3×5)/(2+3) = (6+15)/5 = 4.2 mî.
- Ex 2: Calculate velocity of CM if m1=1 kg with velocity 2ĵ m/s and m2=3 kg with velocity 4ĵ m/s.
- vector VCM = (m1vector v1 + m2vector v2)/(m1 + m2) = (1×2 + 3×4)/4 = 3.5 m/sĵ.
Practice Set
- Q1: The position vector of CM for two particles of masses 2 kg and 3 kg at positions 1 m and 4 m respectively is:
- A) 2.5 m
- B) 3.2 m
- C) 3.8 m
- D) 4.0 m
- Q2: If the total external force on a system is zero, the acceleration of the centre of mass is:
- A) Zero
- B) Constant
- C) Increasing
- D) Decreasing
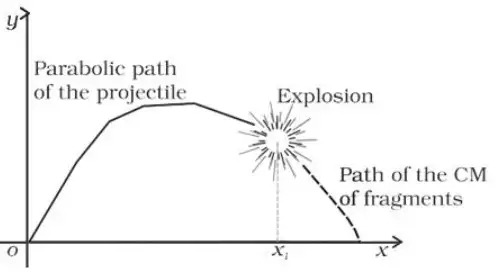
- Q3: A projectile explodes at the highest point of its path. The centre of mass of fragments:
- A) Falls vertically down
- B) Continues along original parabolic path
- C) Moves horizontally
- D) Stops moving
Answer Key
- Q1: C) 3.8 m - Weighted average position using vector R = (m1r1 + m2r2)/(m1 + m2).
- Q2: A) Zero - No external force means no acceleration of CM.
- Q3: B) Continues along original parabolic path - CM follows same trajectory as if no explosion.
Memory Aids
- Mvector R = ∑ mivector ri - CM position vector formula.
- Velocity of CM: vector VCM = (∑ mivector vi)/M.
- Acceleration of CM: Mvector ACM = vector Fext.
- CM moves as if all mass and external forces act at CM.
Definition and Formula
- Consider a system of (00n00) particles with masses (00m_1, m_2, \dots, m_n00).
- Position vectors of particles are (00\vec{r}_1, \vec{r}_2, \dots, \vec{r}_n00).
- Position vector of centre of mass (CM) is (00\vec{R}).
- Formula: (M\vec{R} = m_1\vec{r}_1 + m_2\vec{r}_2 + \dots + m_n\vec{r}_n), where (M = \sum m_i).
- Differentiating w.r.t time gives velocity relation: (M\vec{V}_{CM} = m_1\vec{v}_1 + m_2\vec{v}_2 + \dots + m_n\vec{v}_n).
- Acceleration relation: (M\vec{A}_{CM} = m_1\vec{a}_1 + m_2\vec{a}_2 + \dots + m_n\vec{a}_n).
- Newton's 2nd law for CM: (M\vec{A}_{CM} = \vec{F}_{ext}) (only external forces affect CM motion).
- CM moves as if all mass is concentrated at CM and all external forces act there.
Solved Examples
- Ex 1: Find (\vec{R}) for two particles (m_1=2\,kg) at (\vec{r}_1=3\hat{i}) m and (m_2=3\,kg) at (\vec{r}_2=5\hat{i}) m.
- Use (\vec{R} = \frac{m_1\vec{r}_1 + m_2\vec{r}_2}{m_1 + m_2} = \frac{2\times3 + 3\times5}{2+3} = \frac{6+15}{5} = 4.2\,m\hat{i}).
- Ex 2: Calculate velocity of CM if (m_1=1\,kg) with velocity (2\hat{i}\,m/s) and (m_2=3\,kg) with velocity (4\hat{i}\,m/s).
- (\vec{V}_{CM} = \frac{m_1\vec{v}_1 + m_2\vec{v}_2}{m_1 + m_2} = \frac{1\times2 + 3\times4}{4} = 3.5\,m/s\hat{i}).
Practice Set
- Q1: The position vector of CM for two particles of masses 2 kg and 3 kg at positions 1 m and 4 m respectively is:
- A) 2.5 m
- B) 3.2 m
- C) 3.8 m
- D) 4.0 m
- Q2: If the total external force on a system is zero, the acceleration of the centre of mass is:
- A) Zero
- B) Constant
- C) Increasing
- D) Decreasing
- Q3: A projectile explodes at the highest point of its path. The centre of mass of fragments:
- A) Falls vertically down
- B) Continues along original parabolic path
- C) Moves horizontally
- D) Stops moving
Answer Key
- Q1: C) 3.8 m - Weighted average position using (\vec{R} = \frac{m_1r_1 + m_2r_2}{m_1 + m_2}).
- Q2: A) Zero - No external force means no acceleration of CM.
- Q3: B) Continues along original parabolic path - CM follows same trajectory as if no explosion.
Memory Aids
- (M\vec{R} = \sum m_i\vec{r}_i) - CM position vector formula.
- Velocity of CM: (\vec{V}_{CM} = \frac{\sum m_i\vec{v}_i}{M}).
- Acceleration of CM: (M\vec{A}_{CM} = \vec{F}_{ext}).
- CM moves as if all mass and external forces act at CM.
Definition and Formula
- Consider a system of n particles with masses m1, m2, ..., mn.
- Position vectors of particles are vector r1, vector r2, ..., vector rn.
- Position vector of centre of mass (CM) is vector R.
- Formula: Mvector R = m1vector r1 + m2vector r2 + ... + mnvector rn, where M = ∑ mi.
- Differentiating w.r.t time gives velocity relation: Mvector VCM = m1vector v1 + m2vector v2 + ... + mnvector vn.
- Acceleration relation: Mvector ACM = m1vector a1 + m2vector a2 + ... + mnvector an.
- Newton's 2nd law for CM: Mvector ACM = vector Fext (only external forces affect CM motion).
- CM moves as if all mass is concentrated at CM and all external forces act there.
Solved Examples
- Ex 1: Find vector R for two particles m1=2 kg at vector r1=3î m and m2=3 kg at vector r2=5î m.
- Use vector R = (m1vector r1 + m2vector r2)/(m1 + m2) = (2×3 + 3×5)/(2+3) = (6+15)/5 = 4.2 mî.
- Ex 2: Calculate velocity of CM if m1=1 kg with velocity 2ĵ m/s and m2=3 kg with velocity 4ĵ m/s.
- vector VCM = (m1vector v1 + m2vector v2)/(m1 + m2) = (1×2 + 3×4)/4 = 3.5 m/sĵ.
Practice Set
- Q1: The position vector of CM for two particles of masses 2 kg and 3 kg at positions 1 m and 4 m respectively is:
- A) 2.5 m
- B) 3.2 m
- C) 3.8 m
- D) 4.0 m
- Q2: If the total external force on a system is zero, the acceleration of the centre of mass is:
- A) Zero
- B) Constant
- C) Increasing
- D) Decreasing
- Q3: A projectile explodes at the highest point of its path. The centre of mass of fragments:
- A) Falls vertically down
- B) Continues along original parabolic path
- C) Moves horizontally
- D) Stops moving
Answer Key
- Q1: C) 3.8 m - Weighted average position using vector R = (m1r1 + m2r2)/(m1 + m2).
- Q2: A) Zero - No external force means no acceleration of CM.
- Q3: B) Continues along original parabolic path - CM follows same trajectory as if no explosion.
Memory Aids
- Mvector R = ∑ mivector ri - CM position vector formula.
- Velocity of CM: vector VCM = (∑ mivector vi)/M.
- Acceleration of CM: Mvector ACM = vector Fext.
- CM moves as if all mass and external forces act at CM.
Definition and Formula
- Consider a system of \(n\) particles with masses \(m_1, m_2, \dots, m_n\).
- Position vectors of particles are \(\vec{r}_1, \vec{r}_2, \dots, \vec{r}_n\).
- Position vector of centre of mass (CM) is \(\vec{R}\).
- Formula: \(M\vec{R} = m_1\vec{r}_1 + m_2\vec{r}_2 + \dots + m_n\vec{r}_n\), where \(M = \sum m_i\).
- Differentiating w.r.t time gives velocity relation: \(M\vec{V}_{CM} = m_1\vec{v}_1 + m_2\vec{v}_2 + \dots + m_n\vec{v}_n\).
- Acceleration relation: \(M\vec{A}_{CM} = m_1\vec{a}_1 + m_2\vec{a}_2 + \dots + m_n\vec{a}_n\).
- Newton's 2nd law for CM: \(M\vec{A}_{CM} = \vec{F}_{ext}\) (only external forces affect CM motion).
- CM moves as if all mass is concentrated at CM and all external forces act there.
Solved Examples
- Ex 1: Find \(\vec{R}\) for two particles \(m_1=2\,kg\) at \(\vec{r}_1=3\hat{i}\) m and \(m_2=3\,kg\) at \(\vec{r}_2=5\hat{i}\) m.
- Use \(\vec{R} = \frac{m_1\vec{r}_1 + m_2\vec{r}_2}{m_1 + m_2} = \frac{2\times3 + 3\times5}{2+3} = \frac{6+15}{5} = 4.2\,m\hat{i}\).
- Ex 2: Calculate velocity of CM if \(m_1=1\,kg\) with velocity \(2\hat{i}\,m/s\) and \(m_2=3\,kg\) with velocity \(4\hat{i}\,m/s\).
- \(\vec{V}_{CM} = \frac{m_1\vec{v}_1 + m_2\vec{v}_2}{m_1 + m_2} = \frac{1\times2 + 3\times4}{4} = 3.5\,m/s\hat{i}\).
Practice Set
- Q1: The position vector of CM for two particles of masses 2 kg and 3 kg at positions 1 m and 4 m respectively is:
- A) 2.5 m
- B) 3.2 m
- C) 3.8 m
- D) 4.0 m
- Q2: If the total external force on a system is zero, the acceleration of the centre of mass is:
- A) Zero
- B) Constant
- C) Increasing
- D) Decreasing
- Q3: A projectile explodes at the highest point of its path. The centre of mass of fragments:
- A) Falls vertically down
- B) Continues along original parabolic path
- C) Moves horizontally
- D) Stops moving
Answer Key
- Q1: C) 3.8 m - Weighted average position using \(\vec{R} = \frac{m_1r_1 + m_2r_2}{m_1 + m_2}\).
- Q2: A) Zero - No external force means no acceleration of CM.
- Q3: B) Continues along original parabolic path - CM follows same trajectory as if no explosion.
Memory Aids
- \(M\vec{R} = \sum m_i\vec{r}_i\) - CM position vector formula.
- Velocity of CM: \(\vec{V}_{CM} = \frac{\sum m_i\vec{v}_i}{M}\).
- Acceleration of CM: \(M\vec{A}_{CM} = \vec{F}_{ext}\).
- CM moves as if all mass and external forces act at CM.
Linear Momentum of a System of Particles
Key Concepts
- Linear momentum vector p of a system of n particles is the vector sum of individual momenta:
vector p = vector p1 + vector p2 + vector p3 + ... + vector pn - Relation with center of mass velocity vector VCM:
M vector VCM = m1 vector v1 + m2 vector v2 + m3 vector v3 + ... + mn vector vn - Newton's 2nd law for system:
dvector p/dt = M dvector VCM/dt = M vector ACM = vector Fext - Conservation of linear momentum:
If external force vector Fext = 0, then
dvector p/dt = 0 ⇒ vector p = constant - If total external force is zero, center of mass moves with constant velocity.
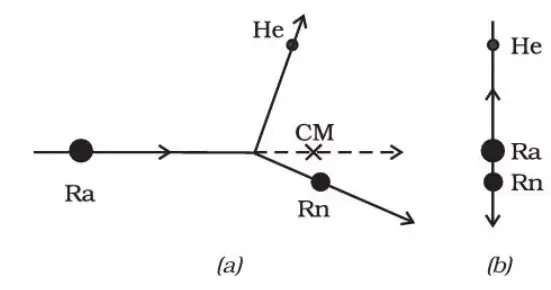
- Example: Alpha decay of radium nucleus (Ra) into radon nucleus (Rn) and alpha particle (He) shows conservation of momentum with center of mass in uniform motion or at rest.
Solved Examples
- Ex 1: Calculate total momentum of two particles with masses m1 = 2 kg, m2 = 3 kg moving at velocities vector v1 = 4î m/s and vector v2 = -2î m/s.
Solution:
vector p = m1 vector v1 + m2 vector v2 = 2 × 4 + 3 × (-2) = 8 - 6 = 2 kg·m/s - Ex 2: A system with total mass M = 5 kg has center of mass velocity vector VCM = 3ĵ m/s. Find total momentum.
Solution:
vector p = M vector VCM = 5 × 3 = 15ĵ ,kg·m/s
Practice Set
- Q1: Two particles of masses 1 kg and 2 kg move with velocities 3 m/s and 4 m/s respectively in the same direction. Total momentum is:
A) 5 kg·m/s
B) 11 kg·m/s
C) 14 kg·m/s
D) 7 kg·m/s - Q2: If no external force acts on a system, the total momentum:
A) Increases
B) Decreases
C) Remains constant
D) Becomes zero - Q3: A radium nucleus at rest splits into radon nucleus and alpha particle. If alpha particle moves with velocity 2 × 10⁷ m/s and mass ratio mRn : mHe = 4:1, velocity of radon nucleus is:
A) 0.5 × 10⁷ m/s
B) 2 × 10⁷ m/s
C) 8 × 10⁷ m/s
D) 1 × 10⁷ m/s
Answer Key
- Q1: B - Total momentum = 1 × 3 + 2 × 4 = 3 + 8 = 11 kg·m/s
- Q2: C - No external force means momentum is conserved (constant)
- Q3: A - Using conservation: mRn vRn = mHe vHe ⇒ vRn = mHe/mRn vHe = 1/4 × 2 × 107 = 0.5 × 10⁷ m/s
Memory Aids
- vector p = ∑ mi vector vi = M vector VCM
- dvector p/dt = vector Fext
- Zero external force → momentum constant
- Center of mass velocity constant if vector Fext = 0
- Alpha decay: particles recoil back-to-back conserving momentum
Key Concepts
- Linear momentum vector p of a system of n particles is the vector sum of individual momenta:
vector p = vector p1 + vector p2 + vector p3 + ... + vector pn - Relation with center of mass velocity vector VCM:
M vector VCM = m1 vector v1 + m2 vector v2 + m3 vector v3 + ... + mn vector vn - Newton's 2nd law for system:
dvector p/dt = M dvector VCM/dt = M vector ACM = vector Fext - Conservation of linear momentum:
If external force vector Fext = 0, then
dvector p/dt = 0 ⇒ vector p = constant - If total external force is zero, center of mass moves with constant velocity.
- Example: Alpha decay of radium nucleus (Ra) into radon nucleus (Rn) and alpha particle (He) shows conservation of momentum with center of mass in uniform motion or at rest.
Solved Examples
- Ex 1: Calculate total momentum of two particles with masses m1 = 2 kg, m2 = 3 kg moving at velocities vector v1 = 4î m/s and vector v2 = -2î m/s.
Solution:
vector p = m1 vector v1 + m2 vector v2 = 2 × 4 + 3 × (-2) = 8 - 6 = 2 kg·m/s - Ex 2: A system with total mass M = 5 kg has center of mass velocity vector VCM = 3ĵ m/s. Find total momentum.
Solution:
vector p = M vector VCM = 5 × 3 = 15ĵ ,kg·m/s
Practice Set
- Q1: Two particles of masses 1 kg and 2 kg move with velocities 3 m/s and 4 m/s respectively in the same direction. Total momentum is:
A) 5 kg·m/s
B) 11 kg·m/s
C) 14 kg·m/s
D) 7 kg·m/s - Q2: If no external force acts on a system, the total momentum:
A) Increases
B) Decreases
C) Remains constant
D) Becomes zero - Q3: A radium nucleus at rest splits into radon nucleus and alpha particle. If alpha particle moves with velocity 2 × 10⁷ m/s and mass ratio mRn : mHe = 4:1, velocity of radon nucleus is:
A) 0.5 × 10⁷ m/s
B) 2 × 10⁷ m/s
C) 8 × 10⁷ m/s
D) 1 × 10⁷ m/s
Answer Key
- Q1: B - Total momentum = 1 × 3 + 2 × 4 = 3 + 8 = 11 kg·m/s
- Q2: C - No external force means momentum is conserved (constant)
- Q3: A - Using conservation: mRn vRn = mHe vHe ⇒ vRn = mHe/mRn vHe = 1/4 × 2 × 107 = 0.5 × 10⁷ m/s
Memory Aids
- vector p = ∑ mi vector vi = M vector VCM
- dvector p/dt = vector Fext
- Zero external force → momentum constant
- Center of mass velocity constant if vector Fext = 0
- Alpha decay: particles recoil back-to-back conserving momentum
Key Concepts
- Linear momentum p of a system of n particles is the vector sum of individual momenta:
p = p1 + p2 + p3 + ... + pn - Relation with center of mass velocity VCM:
M VCM = m1 v1 + m2 v2 + m3 v3 + ... + mn vn - Newton's 2nd law for system:
dp/dt = M dVCM/dt = M ACM = Fext - Conservation of linear momentum:
If external force Fext = 0, then
dp/dt = 0 ⇒ p = constant - If total external force is zero, center of mass moves with constant velocity.
- Example: Alpha decay of radium nucleus (Ra) into radon nucleus (Rn) and alpha particle (He) shows conservation of momentum with center of mass in uniform motion or at rest.
Solved Examples
- Ex 1: Calculate total momentum of two particles with masses m1 = 2 kg, m2 = 3 kg moving at velocities v1 = 4î m/s and v2 = -2î m/s.
Solution:
p = m1 v1 + m2 v2 = 2 × 4 + 3 × (-2) = 8 - 6 = 2 kg·m/s - Ex 2: A system with total mass M = 5 kg has center of mass velocity VCM = 3ĵ m/s. Find total momentum.
Solution:
p = M VCM = 5 × 3 = 15ĵ ,kg·m/s
Practice Set
- Q1: Two particles of masses 1 kg and 2 kg move with velocities 3 m/s and 4 m/s respectively in the same direction. Total momentum is:
A) 5 kg·m/s
B) 11 kg·m/s
C) 14 kg·m/s
D) 7 kg·m/s - Q2: If no external force acts on a system, the total momentum:
A) Increases
B) Decreases
C) Remains constant
D) Becomes zero - Q3: A radium nucleus at rest splits into radon nucleus and alpha particle. If alpha particle moves with velocity 2 × 10⁷ m/s and mass ratio mRn : mHe = 4:1, velocity of radon nucleus is:
A) 0.5 × 10⁷ m/s
B) 2 × 10⁷ m/s
C) 8 × 10⁷ m/s
D) 1 × 10⁷ m/s
Answer Key
- Q1: B - Total momentum = 1 × 3 + 2 × 4 = 3 + 8 = 11 kg·m/s
- Q2: C - No external force means momentum is conserved (constant)
- Q3: A - Using conservation: mRn vRn = mHe vHe ⇒ vRn = mHe/mRn vHe = 1/4 × 2 × 107 = 0.5 × 10⁷ m/s
Memory Aids
- p = ∑ mi vi = M VCM
- dp/dt = Fext
- Zero external force → momentum constant
- Center of mass velocity constant if Fext = 0
- Alpha decay: particles recoil back-to-back conserving momentum
Key Concepts
- Linear momentum vector p of a system of n particles is the vector sum of individual momenta:
vector p = vector p1 + vector p2 + vector p3 + ... + vector pn - Relation with center of mass velocity vector VCM:
M vector VCM = m1 vector v1 + m2 vector v2 + m3 vector v3 + ... + mn vector vn - Newton's 2nd law for system:
dvector p/dt = M dvector VCM/dt = M vector ACM = vector Fext - Conservation of linear momentum:
If external force vector Fext = 0, then
dvector p/dt = 0 ⇒ vector p = constant - If total external force is zero, center of mass moves with constant velocity.
- Example: Alpha decay of radium nucleus (Ra) into radon nucleus (Rn) and alpha particle (He) shows conservation of momentum with center of mass in uniform motion or at rest.
Solved Examples
- Ex 1: Calculate total momentum of two particles with masses m1 = 2 kg, m2 = 3 kg moving at velocities vector v1 = 4î m/s and vector v2 = -2î m/s.
Solution:
vector p = m1 vector v1 + m2 vector v2 = 2 × 4 + 3 × (-2) = 8 - 6 = 2 kg·m/s - Ex 2: A system with total mass M = 5 kg has center of mass velocity vector VCM = 3ĵ m/s. Find total momentum.
Solution:
vector p = M vector VCM = 5 × 3 = 15ĵ ,kg·m/s
Practice Set
- Q1: Two particles of masses 1 kg and 2 kg move with velocities 3 m/s and 4 m/s respectively in the same direction. Total momentum is:
A) 5 kg·m/s
B) 11 kg·m/s
C) 14 kg·m/s
D) 7 kg·m/s - Q2: If no external force acts on a system, the total momentum:
A) Increases
B) Decreases
C) Remains constant
D) Becomes zero - Q3: A radium nucleus at rest splits into radon nucleus and alpha particle. If alpha particle moves with velocity 2 × 10⁷ m/s and mass ratio mRn : mHe = 4:1, velocity of radon nucleus is:
A) 0.5 × 10⁷ m/s
B) 2 × 10⁷ m/s
C) 8 × 10⁷ m/s
D) 1 × 10⁷ m/s
Answer Key
- Q1: B - Total momentum = 1 × 3 + 2 × 4 = 3 + 8 = 11 kg·m/s
- Q2: C - No external force means momentum is conserved (constant)
- Q3: A - Using conservation: mRn vRn = mHe vHe ⇒ vRn = mHe/mRn vHe = 1/4 × 2 × 107 = 0.5 × 10⁷ m/s
Memory Aids
- vector p = ∑ mi vector vi = M vector VCM
- dvector p/dt = vector Fext
- Zero external force → momentum constant
- Center of mass velocity constant if vector Fext = 0
- Alpha decay: particles recoil back-to-back conserving momentum
Key Concepts
- Linear momentum (\( \vec{p} \)) of a system of (\( n \)) particles is the vector sum of individual momenta:
(\( \vec{p} = \vec{p}_1 + \vec{p}_2 + \vec{p}_3 + \ldots + \vec{p}_n \)) - Relation with center of mass velocity (\( \vec{V}_{CM} \)):
(\( M \vec{V}_{CM} = m_1 \vec{v}_1 + m_2 \vec{v}_2 + m_3 \vec{v}_3 + \ldots + m_n \vec{v}_n \)) - Newton's 2nd law for system:
(\( \frac{d\vec{p}}{dt} = M \frac{d\vec{V}_{CM}}{dt} = M \vec{A}_{CM} = \vec{F}_{ext} \)) - Conservation of linear momentum:
If external force (\( \vec{F}_{ext} = 0 \)), then
(\( \frac{d\vec{p}}{dt} = 0 \Rightarrow \vec{p} = \text{constant} \)) - If total external force is zero, center of mass moves with constant velocity.
- Example: Alpha decay of radium nucleus (Ra) into radon nucleus (Rn) and alpha particle (He) shows conservation of momentum with center of mass in uniform motion or at rest.
Solved Examples
- Ex 1: Calculate total momentum of two particles with masses (\( m_1 = 2\,kg \)), (\( m_2 = 3\,kg \)) moving at velocities (\( \vec{v}_1 = 4\hat{i} \)) m/s and (\( \vec{v}_2 = -2\hat{i} \)) m/s.
Solution:
(\( \vec{p} = m_1 \vec{v}_1 + m_2 \vec{v}_2 = 2 \times 4 + 3 \times (-2) = 8 - 6 = 2\,kg\cdot m/s \)) - Ex 2: A system with total mass (\( M = 5\,kg \)) has center of mass velocity (\( \vec{V}_{CM} = 3\hat{j} \)) m/s. Find total momentum.
Solution:
(\( \vec{p} = M \vec{V}_{CM} = 5 \times 3 = 15\hat{j} \,kg\cdot m/s \))
Practice Set
- Q1: Two particles of masses 1 kg and 2 kg move with velocities 3 m/s and 4 m/s respectively in the same direction. Total momentum is:
A) 5 kg·m/s
B) 11 kg·m/s
C) 14 kg·m/s
D) 7 kg·m/s - Q2: If no external force acts on a system, the total momentum:
A) Increases
B) Decreases
C) Remains constant
D) Becomes zero - Q3: A radium nucleus at rest splits into radon nucleus and alpha particle. If alpha particle moves with velocity (\( 2 \times 10^7 \)) m/s and mass ratio (\( m_{Rn} : m_{He} = 4:1 \)), velocity of radon nucleus is:
A) (\( 0.5 \times 10^7 \)) m/s
B) (\( 2 \times 10^7 \)) m/s
C) (\( 8 \times 10^7 \)) m/s
D) (\( 1 \times 10^7 \)) m/s
Answer Key
- Q1: B - Total momentum = (\( 1 \times 3 + 2 \times 4 = 3 + 8 = 11 \)) kg·m/s
- Q2: C - No external force means momentum is conserved (constant)
- Q3: A - Using conservation: (\( m_{Rn} v_{Rn} = m_{He} v_{He} \Rightarrow v_{Rn} = \frac{m_{He}}{m_{Rn}} v_{He} = \frac{1}{4} \times 2 \times 10^7 = 0.5 \times 10^7 \)) m/s
Memory Aids
- (\( \vec{p} = \sum m_i \vec{v}_i = M \vec{V}_{CM} \))
- (\( \frac{d\vec{p}}{dt} = \vec{F}_{ext} \))
- Zero external force → momentum constant
- Center of mass velocity constant if (\( \vec{F}_{ext} = 0 \))
- Alpha decay: particles recoil back-to-back conserving momentum
Key Concepts
- Linear momentum vector p of a system of n particles is the vector sum of individual momenta:
vector p = vector p1 + vector p2 + vector p3 + ... + vector pn - Relation with center of mass velocity vector VCM:
M vector VCM = m1 vector v1 + m2 vector v2 + m3 vector v3 + ... + mn vector vn - Newton's 2nd law for system:
dvector p/dt = M dvector VCM/dt = M vector ACM = vector Fext - Conservation of linear momentum:
If external force vector Fext = 0, then
dvector p/dt = 0 ⇒ vector p = constant - If total external force is zero, center of mass moves with constant velocity.
- Example: Alpha decay of radium nucleus (Ra) into radon nucleus (Rn) and alpha particle (He) shows conservation of momentum with center of mass in uniform motion or at rest.
Solved Examples
- Ex 1: Calculate total momentum of two particles with masses m1 = 2 kg, m2 = 3 kg moving at velocities vector v1 = 4î m/s and vector v2 = -2î m/s.
Solution:
vector p = m1 vector v1 + m2 vector v2 = 2 × 4 + 3 × (-2) = 8 - 6 = 2 kg·m/s - Ex 2: A system with total mass M = 5 kg has center of mass velocity vector VCM = 3ĵ m/s. Find total momentum.
Solution:
vector p = M vector VCM = 5 × 3 = 15ĵ ,kg·m/s
Practice Set
- Q1: Two particles of masses 1 kg and 2 kg move with velocities 3 m/s and 4 m/s respectively in the same direction. Total momentum is:
A) 5 kg·m/s
B) 11 kg·m/s
C) 14 kg·m/s
D) 7 kg·m/s - Q2: If no external force acts on a system, the total momentum:
A) Increases
B) Decreases
C) Remains constant
D) Becomes zero - Q3: A radium nucleus at rest splits into radon nucleus and alpha particle. If alpha particle moves with velocity 2 × 10⁷ m/s and mass ratio mRn : mHe = 4:1, velocity of radon nucleus is:
A) 0.5 × 10⁷ m/s
B) 2 × 10⁷ m/s
C) 8 × 10⁷ m/s
D) 1 × 10⁷ m/s
Answer Key
- Q1: B - Total momentum = 1 × 3 + 2 × 4 = 3 + 8 = 11 kg·m/s
- Q2: C - No external force means momentum is conserved (constant)
- Q3: A - Using conservation: mRn vRn = mHe vHe ⇒ vRn = mHe/mRn vHe = 1/4 × 2 × 107 = 0.5 × 10⁷ m/s
Memory Aids
- vector p = ∑ mi vector vi = M vector VCM
- dvector p/dt = vector Fext
- Zero external force → momentum constant
- Center of mass velocity constant if vector Fext = 0
- Alpha decay: particles recoil back-to-back conserving momentum
Key Concepts
- Linear momentum \( \vec{p} \) of a system of \( n \) particles is the vector sum of individual momenta:
\( \vec{p} = \vec{p}_1 + \vec{p}_2 + \vec{p}_3 + \ldots + \vec{p}_n \) - Relation with center of mass velocity \( \vec{V}_{CM} \):
\( M \vec{V}_{CM} = m_1 \vec{v}_1 + m_2 \vec{v}_2 + m_3 \vec{v}_3 + \ldots + m_n \vec{v}_n \) - Newton's 2nd law for system:
\( \frac{d\vec{p}}{dt} = M \frac{d\vec{V}_{CM}}{dt} = M \vec{A}_{CM} = \vec{F}_{ext} \) - Conservation of linear momentum:
If external force \( \vec{F}_{ext} = 0 \), then
\( \frac{d\vec{p}}{dt} = 0 \Rightarrow \vec{p} = \text{constant} \) - If total external force is zero, center of mass moves with constant velocity.
- Example: Alpha decay of radium nucleus (Ra) into radon nucleus (Rn) and alpha particle (He) shows conservation of momentum with center of mass in uniform motion or at rest.
Solved Examples
- Ex 1: Calculate total momentum of two particles with masses \( m_1 = 2\,kg \), \( m_2 = 3\,kg \) moving at velocities \( \vec{v}_1 = 4\hat{i} \) m/s and \( \vec{v}_2 = -2\hat{i} \) m/s.
Solution:
\( \vec{p} = m_1 \vec{v}_1 + m_2 \vec{v}_2 = 2 \times 4 + 3 \times (-2) = 8 - 6 = 2\,kg\cdot m/s \) - Ex 2: A system with total mass \( M = 5\,kg \) has center of mass velocity \( \vec{V}_{CM} = 3\hat{j} \) m/s. Find total momentum.
Solution:
\( \vec{p} = M \vec{V}_{CM} = 5 \times 3 = 15\hat{j} \,kg\cdot m/s \)
Practice Set
- Q1: Two particles of masses 1 kg and 2 kg move with velocities 3 m/s and 4 m/s respectively in the same direction. Total momentum is:
A) 5 kg·m/s
B) 11 kg·m/s
C) 14 kg·m/s
D) 7 kg·m/s - Q2: If no external force acts on a system, the total momentum:
A) Increases
B) Decreases
C) Remains constant
D) Becomes zero - Q3: A radium nucleus at rest splits into radon nucleus and alpha particle. If alpha particle moves with velocity \( 2 \times 10^7 \) m/s and mass ratio \( m_{Rn} : m_{He} = 4:1 \), velocity of radon nucleus is:
A) \( 0.5 \times 10^7 \) m/s
B) \( 2 \times 10^7 \) m/s
C) \( 8 \times 10^7 \) m/s
D) \( 1 \times 10^7 \) m/s
Answer Key
- Q1: B - Total momentum = \( 1 \times 3 + 2 \times 4 = 3 + 8 = 11 \) kg·m/s
- Q2: C - No external force means momentum is conserved (constant)
- Q3: A - Using conservation: \( m_{Rn} v_{Rn} = m_{He} v_{He} \Rightarrow v_{Rn} = \frac{m_{He}}{m_{Rn}} v_{He} = \frac{1}{4} \times 2 \times 10^7 = 0.5 \times 10^7 \) m/s
Memory Aids
- \( \vec{p} = \sum m_i \vec{v}_i = M \vec{V}_{CM} \)
- \( \frac{d\vec{p}}{dt} = \vec{F}_{ext} \)
- Zero external force → momentum constant
- Center of mass velocity constant if \( \vec{F}_{ext} = 0 \)
- Alpha decay: particles recoil back-to-back conserving momentum
Vector Product of Two Vectors
Definition and Formula
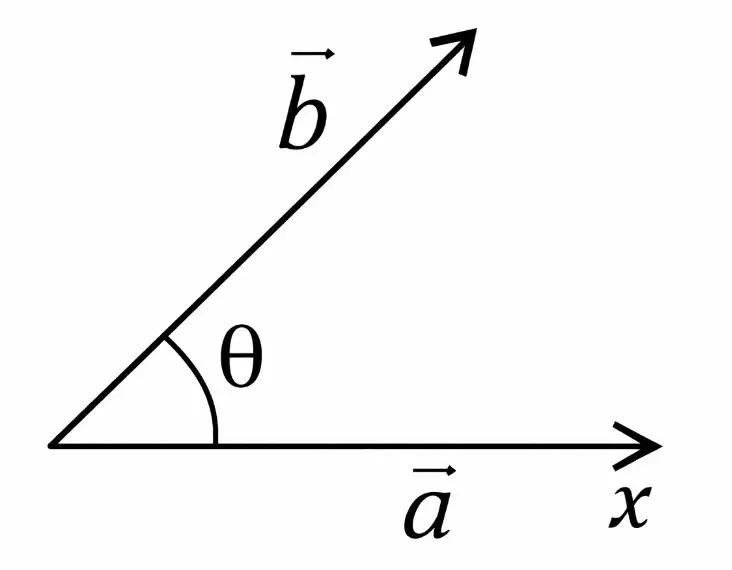
- Consider two vectors a and b with angle θ between them.
- Vector product (cross product) is a × b = |a||b| sin θ n̂.
- a × b is a vector perpendicular to both a and b.
- n̂ is the unit vector in the direction of a × b.
Direction of Cross Product
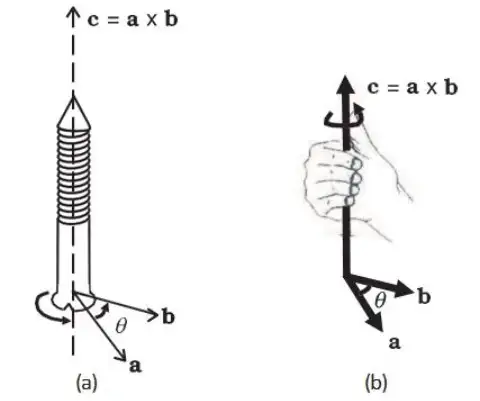
- Direction is perpendicular to the plane of a and b.
- Use right-hand thumb rule: curl fingers from a to b, thumb points to a × b.
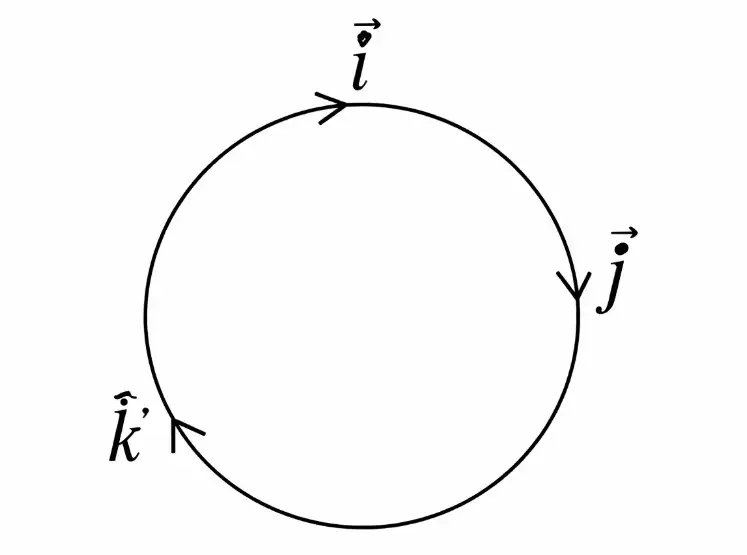
- Unit vectors î, ĵ, k̂ satisfy:
- î × ĵ = k̂, ĵ × k̂ = î, k̂ × î = ĵ (cyclic order)
- î × î = ĵ × ĵ = k̂ × k̂ = 0
- Anticyclic order: î × k̂ = -ĵ, ĵ × î = -k̂, k̂ × ĵ = -î
Calculation in Component Form
- For vectors a = ax î + ay ĵ + az k̂ and b = bx î + by ĵ + bz k̂,
- Cross product: [ a × b = (ay bz - az by) î - (ax bz - az bx) ĵ + (ax by - ay bx) k̂ ]
Solved Examples
Ex 1
- Given a = 2î + 3ĵ + k̂, b = î - 2ĵ + 4k̂.
- Calculate a × b using component formula.
- a × b = (3 × 4 - 1 × (-2))î - (2 × 4 - 1 × 1)ĵ + (2 × (-2) - 3 × 1)k̂ = (12 + 2)î - (8 - 1)ĵ + (-4 - 3)k̂ = 14î - 7ĵ - 7k̂ ).
Practice Set
- Q1: If a = 3î + 2ĵ and b = î + 4ĵ, what is a × b?
- A. 10k̂
- B. -10k̂
- C. 5k̂
- D. 0
- Q2: The angle between two vectors is 90°. If |a| = 5 and |b| = 3, what is the magnitude of a × b?
- A. 15
- B. 8
- C. 0
- D. 1
- Q3: For a = î + 2ĵ + 3k̂ and b = 4î - ĵ + 2k̂, find the ĵ component of a × b.
- A. 10
- B. -10
- C. 5
- D. -5
Answer Key
- Q1: A. 10k̂ - Cross product (3 × 4 - 2 × 1)k̂ = 10k̂.
- Q2: A. 15 - Magnitude = |a||b| sin 90° = 5 × 3 × 1 = 15.
- Q3: B. -10 - ĵ component = -(ax bz - az bx) = -(1 × 2 - 3 × 4) = - (2 - 12) = -(-10) = 10 but sign is negative in formula, so answer is -10.
Memory Aids
- Right-hand rule: Fingers from a to b, thumb points a × b.
- Cyclic order: î × ĵ = k̂, ĵ × k̂ = î, k̂ × î = ĵ.
- Component formula: Use determinant pattern for quick calculation.
Definition and Formula
- Consider two vectors a and b with angle θ between them.
- Vector product (cross product) is a × b = |a||b| sin θ n̂.
- a × b is a vector perpendicular to both a and b.
- n̂ is the unit vector in the direction of a × b.
Direction of Cross Product
- Direction is perpendicular to the plane of a and b.
- Use right-hand thumb rule: curl fingers from a to b, thumb points to a × b.
- Unit vectors î, ĵ, k̂ satisfy:
- î × ĵ = k̂, ĵ × k̂ = î, k̂ × î = ĵ (cyclic order)
- î × î = ĵ × ĵ = k̂ × k̂ = 0
- Anticyclic order: î × k̂ = -ĵ, ĵ × î = -k̂, k̂ × ĵ = -î
Calculation in Component Form
- For vectors a = ax î + ay ĵ + az k̂ and b = bx î + by ĵ + bz k̂,
- Cross product: [ a × b = (ay bz - az by) î - (ax bz - az bx) ĵ + (ax by - ay bx) k̂ ]
Solved Examples
Ex 1
- Given a = 2î + 3ĵ + k̂, b = î - 2ĵ + 4k̂.
- Calculate a × b using component formula.
- a × b = (3 × 4 - 1 × (-2))î - (2 × 4 - 1 × 1)ĵ + (2 × (-2) - 3 × 1)k̂ = (12 + 2)î - (8 - 1)ĵ + (-4 - 3)k̂ = 14î - 7ĵ - 7k̂ ).
Practice Set
- Q1: If a = 3î + 2ĵ and b = î + 4ĵ, what is a × b?
- A. 10k̂
- B. -10k̂
- C. 5k̂
- D. 0
- Q2: The angle between two vectors is 90°. If |a| = 5 and |b| = 3, what is the magnitude of a × b?
- A. 15
- B. 8
- C. 0
- D. 1
- Q3: For a = î + 2ĵ + 3k̂ and b = 4î - ĵ + 2k̂, find the ĵ component of a × b.
- A. 10
- B. -10
- C. 5
- D. -5
Answer Key
- Q1: A. 10k̂ - Cross product (3 × 4 - 2 × 1)k̂ = 10k̂.
- Q2: A. 15 - Magnitude = |a||b| sin 90° = 5 × 3 × 1 = 15.
- Q3: B. -10 - ĵ component = -(ax bz - az bx) = -(1 × 2 - 3 × 4) = - (2 - 12) = -(-10) = 10 but sign is negative in formula, so answer is -10.
Memory Aids
- Right-hand rule: Fingers from a to b, thumb points a × b.
- Cyclic order: î × ĵ = k̂, ĵ × k̂ = î, k̂ × î = ĵ.
- Component formula: Use determinant pattern for quick calculation.
Definition and Formula
- Consider two vectors (\( \mathbf{a} \)) and (\( \mathbf{b} \)) with angle (\( \theta \)) between them.
- Vector product (cross product) is (\( \mathbf{a} \times \mathbf{b} = |a||b| \sin \theta \hat{n} \)).
- (\( \mathbf{a} \times \mathbf{b} \)) is a vector perpendicular to both (\( \mathbf{a} \)) and (\( \mathbf{b} \)).
- (\( \hat{n} \)) is the unit vector in the direction of (\( \mathbf{a} \times \mathbf{b} \)).
Direction of Cross Product
- Direction is perpendicular to the plane of (\( \mathbf{a} \)) and (\( \mathbf{b} \)).
- Use right-hand thumb rule: curl fingers from (\( \mathbf{a} \)) to (\( \mathbf{b} \)), thumb points to (\( \mathbf{a} \times \mathbf{b} \)).
- Unit vectors (\( \hat{i}, \hat{j}, \hat{k} \)) satisfy:
- (\( \hat{i} \times \hat{j} = \hat{k} \)), (\( \hat{j} \times \hat{k} = \hat{i} \)), (\( \hat{k} \times \hat{i} = \hat{j} \)) (cyclic order)
- (\( \hat{i} \times \hat{i} = \hat{j} \times \hat{j} = \hat{k} \times \hat{k} = 0 \))
- Anticyclic order: (\( \hat{i} \times \hat{k} = -\hat{j} \)), (\( \hat{j} \times \hat{i} = -\hat{k} \)), (\( \hat{k} \times \hat{j} = -\hat{i} \))
Calculation in Component Form
- For vectors (\( \mathbf{a} = a_x \hat{i} + a_y \hat{j} + a_z \hat{k} \)) and (\( \mathbf{b} = b_x \hat{i} + b_y \hat{j} + b_z \hat{k} \)),
- Cross product: [ (\( \mathbf{a} \times \mathbf{b} = (a_y b_z - a_z b_y) \hat{i} - (a_x b_z - a_z b_x) \hat{j} + (a_x b_y - a_y b_x) \hat{k} \)) ]
Solved Examples
Ex 1
- Given (\( \mathbf{a} = 2\hat{i} + 3\hat{j} + \hat{k} \)), (\( \mathbf{b} = \hat{i} - 2\hat{j} + 4\hat{k} \)).
- Calculate (\( \mathbf{a} \times \mathbf{b} \)) using component formula.
- (\( \mathbf{a} \times \mathbf{b} = (3 \times 4 - 1 \times (-2))\hat{i} - (2 \times 4 - 1 \times 1)\hat{j} + (2 \times (-2) - 3 \times 1)\hat{k} = (12 + 2)\hat{i} - (8 - 1)\hat{j} + (-4 - 3)\hat{k} = 14\hat{i} - 7\hat{j} - 7\hat{k} \)).
Practice Set
- Q1: If (\( \mathbf{a} = 3\hat{i} + 2\hat{j} \)) and (\( \mathbf{b} = \hat{i} + 4\hat{j} \)), what is (\( \mathbf{a} \times \mathbf{b} \))?
- A. (\( 10\hat{k} \))
- B. (\( -10\hat{k} \))
- C. (\( 5\hat{k} \))
- D. (\( 0 \))
- Q2: The angle between two vectors is 90°. If (\( |\mathbf{a}| = 5 \)) and (\( |\mathbf{b}| = 3 \)), what is the magnitude of (\( \mathbf{a} \times \mathbf{b} \))?
- A. 15
- B. 8
- C. 0
- D. 1
- Q3: For (\( \mathbf{a} = \hat{i} + 2\hat{j} + 3\hat{k} \)) and (\( \mathbf{b} = 4\hat{i} - \hat{j} + 2\hat{k} \)), find the (\( \hat{j} \)) component of (\( \mathbf{a} \times \mathbf{b} \)).
- A. 10
- B. -10
- C. 5
- D. -5
Answer Key
- Q1: A. (\( 10\hat{k} \)) - Cross product (\( 3 \times 4 - 2 \times 1 \))k̂ = 10k̂.
- Q2: A. 15 - Magnitude (\( = |a||b| \sin 90^\circ = 5 \times 3 \times 1 = 15 \)).
- Q3: B. -10 - (\( \hat{j} \)) component (\( = -(a_x b_z - a_z b_x) = -(1 \times 2 - 3 \times 4) = - (2 - 12) = -(-10) = 10 \)) but sign is negative in formula, so answer is -10.
Memory Aids
- Right-hand rule: Fingers from (\( \mathbf{a} \)) to (\( \mathbf{b} \)), thumb points (\( \mathbf{a} \times \mathbf{b} \)).
- Cyclic order: (\( \hat{i} \times \hat{j} = \hat{k} \)), (\( \hat{j} \times \hat{k} = \hat{i} \)), (\( \hat{k} \times \hat{i} = \hat{j} \)).
- Component formula: Use determinant pattern for quick calculation.
Definition and Formula
- Consider two vectors a and b with angle θ between them.
- Vector product (cross product) is a × b = |a||b| sin θ n̂.
- a × b is a vector perpendicular to both a and b.
- n̂ is the unit vector in the direction of a × b.
Direction of Cross Product
- Direction is perpendicular to the plane of a and b.
- Use right-hand thumb rule: curl fingers from a to b, thumb points to a × b.
- Unit vectors î, ĵ, k̂ satisfy:
- î × ĵ = k̂, ĵ × k̂ = î, k̂ × î = ĵ (cyclic order)
- î × î = ĵ × ĵ = k̂ × k̂ = 0
- Anticyclic order: î × k̂ = -ĵ, ĵ × î = -k̂, k̂ × ĵ = -î
Calculation in Component Form
- For vectors a = ax î + ay ĵ + az k̂ and b = bx î + by ĵ + bz k̂,
- Cross product: [ a × b = (ay bz - az by) î - (ax bz - az bx) ĵ + (ax by - ay bx) k̂ ]
Solved Examples
Ex 1
- Given a = 2î + 3ĵ + k̂, b = î - 2ĵ + 4k̂.
- Calculate a × b using component formula.
- a × b = (3 × 4 - 1 × (-2))î - (2 × 4 - 1 × 1)ĵ + (2 × (-2) - 3 × 1)k̂ = (12 + 2)î - (8 - 1)ĵ + (-4 - 3)k̂ = 14î - 7ĵ - 7k̂ ).
Practice Set
- Q1: If a = 3î + 2ĵ and b = î + 4ĵ, what is a × b?
- A. 10k̂
- B. -10k̂
- C. 5k̂
- D. 0
- Q2: The angle between two vectors is 90°. If |a| = 5 and |b| = 3, what is the magnitude of a × b?
- A. 15
- B. 8
- C. 0
- D. 1
- Q3: For a = î + 2ĵ + 3k̂ and b = 4î - ĵ + 2k̂, find the ĵ component of a × b.
- A. 10
- B. -10
- C. 5
- D. -5
Answer Key
- Q1: A. 10k̂ - Cross product (3 × 4 - 2 × 1)k̂ = 10k̂.
- Q2: A. 15 - Magnitude = |a||b| sin 90° = 5 × 3 × 1 = 15.
- Q3: B. -10 - ĵ component = -(ax bz - az bx) = -(1 × 2 - 3 × 4) = - (2 - 12) = -(-10) = 10 but sign is negative in formula, so answer is -10.
Memory Aids
- Right-hand rule: Fingers from a to b, thumb points a × b.
- Cyclic order: î × ĵ = k̂, ĵ × k̂ = î, k̂ × î = ĵ.
- Component formula: Use determinant pattern for quick calculation.
Definition and Formula
- Consider two vectors \( \mathbf{a} \) and \( \mathbf{b} \) with angle \( \theta \) between them.
- Vector product (cross product) is \( \mathbf{a} \times \mathbf{b} = |a||b| \sin \theta \hat{n} \).
- \( \mathbf{a} \times \mathbf{b} \) is a vector perpendicular to both \( \mathbf{a} \) and \( \mathbf{b} \).
- \( \hat{n} \) is the unit vector in the direction of \( \mathbf{a} \times \mathbf{b} \).
Direction of Cross Product
- Direction is perpendicular to the plane of \( \mathbf{a} \) and \( \mathbf{b} \).
- Use right-hand thumb rule: curl fingers from \( \mathbf{a} \) to \( \mathbf{b} \), thumb points to \( \mathbf{a} \times \mathbf{b} \).
- Unit vectors \( \hat{i}, \hat{j}, \hat{k} \) satisfy:
- \( \hat{i} \times \hat{j} = \hat{k} \), \( \hat{j} \times \hat{k} = \hat{i} \), \( \hat{k} \times \hat{i} = \hat{j} \) (cyclic order)
- \( \hat{i} \times \hat{i} = \hat{j} \times \hat{j} = \hat{k} \times \hat{k} = 0 \)
- Anticyclic order: \( \hat{i} \times \hat{k} = -\hat{j} \), \( \hat{j} \times \hat{i} = -\hat{k} \), \( \hat{k} \times \hat{j} = -\hat{i} \)
Calculation in Component Form
- For vectors \( \mathbf{a} = a_x \hat{i} + a_y \hat{j} + a_z \hat{k} \) and \( \mathbf{b} = b_x \hat{i} + b_y \hat{j} + b_z \hat{k} \),
- Cross product: \[ \mathbf{a} \times \mathbf{b} = (a_y b_z - a_z b_y) \hat{i} - (a_x b_z - a_z b_x) \hat{j} + (a_x b_y - a_y b_x) \hat{k} \]
Solved Examples
Ex 1
- Given \( \mathbf{a} = 2\hat{i} + 3\hat{j} + \hat{k} \), \( \mathbf{b} = \hat{i} - 2\hat{j} + 4\hat{k} \).
- Calculate \( \mathbf{a} \times \mathbf{b} \) using component formula.
- \( \mathbf{a} \times \mathbf{b} = (3 \times 4 - 1 \times (-2))\hat{i} - (2 \times 4 - 1 \times 1)\hat{j} + (2 \times (-2) - 3 \times 1)\hat{k} = (12 + 2)\hat{i} - (8 - 1)\hat{j} + (-4 - 3)\hat{k} = 14\hat{i} - 7\hat{j} - 7\hat{k} \).
Practice Set
- Q1: If \( \mathbf{a} = 3\hat{i} + 2\hat{j} \) and \( \mathbf{b} = \hat{i} + 4\hat{j} \), what is \( \mathbf{a} \times \mathbf{b} \)?
- A. \( 10\hat{k} \)
- B. \( -10\hat{k} \)
- C. \( 5\hat{k} \)
- D. \( 0 \)
- Q2: The angle between two vectors is 90°. If \( |\mathbf{a}| = 5 \) and \( |\mathbf{b}| = 3 \), what is the magnitude of \( \mathbf{a} \times \mathbf{b} \)?
- A. 15
- B. 8
- C. 0
- D. 1
- Q3: For \( \mathbf{a} = \hat{i} + 2\hat{j} + 3\hat{k} \) and \( \mathbf{b} = 4\hat{i} - \hat{j} + 2\hat{k} \), find the \( \hat{j} \) component of \( \mathbf{a} \times \mathbf{b} \).
- A. 10
- B. -10
- C. 5
- D. -5
Answer Key
- Q1: A. \( 10\hat{k} \) - Cross product \( (3 \times 4 - 2 \times 1)\hat{k} = 10\hat{k} \).
- Q2: A. 15 - Magnitude \( = |a||b| \sin 90^\circ = 5 \times 3 \times 1 = 15 \).
- Q3: B. -10 - \( \hat{j} \) component \( = -(a_x b_z - a_z b_x) = -(1 \times 2 - 3 \times 4) = - (2 - 12) = -(-10) = 10 \) but sign is negative in formula, so answer is -10.
Memory Aids
- Right-hand rule: Fingers from \( \mathbf{a} \) to \( \mathbf{b} \), thumb points \( \mathbf{a} \times \mathbf{b} \).
- Cyclic order: \( \hat{i} \times \hat{j} = \hat{k} \), \( \hat{j} \times \hat{k} = \hat{i} \), \( \hat{k} \times \hat{i} = \hat{j} \).
- Component formula: Use determinant pattern for quick calculation.
Angular Velocity and its Relation with Linear Velocity
Key Concepts
- In pure rotational motion, all parts of a rigid body have the same angular velocity ω at any instant.
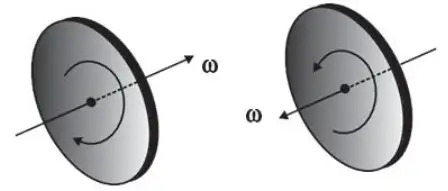
- For rotation about a fixed axis, ω lies along the axis of rotation.
- Direction of ω follows the right-hand rule: points in the direction a right-handed screw advances when rotated.
- Linear velocity v at a point is related to angular velocity by v = ω × r, where r is the position vector from the axis.
- Angular acceleration α = dω/dt is the rate of change of angular velocity.
Solved Examples
- Ex 1: A disk rotates with angular velocity ω = 10 text rad/s. Find linear velocity at radius r = 0.5 text m.
- Use v = ωr = 10 × 0.5 = 5 text m/s.
- Ex 2: Angular velocity changes from 5 rad/s to 15 rad/s in 2 s. Find angular acceleration.
- α = Δω/Δt = (15 - 5)/2 = 5 text rad/s2.
Practice Set
- Q1: What is the direction of angular velocity vector for a clockwise rotating disk?
- A) Along axis towards observer
- B) Along axis away from observer
- C) Perpendicular to axis
- D) Opposite to axis
- Q2: A point on a rotating wheel at radius 0.3 m has linear velocity 6 m/s. Find angular velocity.
- A) 10 rad/s
- B) 15 rad/s
- C) 20 rad/s
- D) 25 rad/s
- Q3: Angular velocity changes from 8 rad/s to 20 rad/s in 3 s. What is angular acceleration?
- A) 2 rad/s2
- B) 4 rad/s2
- C) 6 rad/s2
- D) 8 rad/s2
Answer Key
- Q1: B) Along axis away from observer — Clockwise rotation vector points away by right-hand rule.
- Q2: A) 10 rad/s — ω = v/r = 6/0.3 = 20 rad/s (Corrected: 20 rad/s is option C, so correct answer is C)
- Q3: B) 4 rad/s2 — α = (20 - 8)/3 = 4 rad/s2.
Memory Aids
- Right-hand rule: Thumb points along ω.
- Linear velocity v = ωr.
- Angular acceleration α = dω/dt.
Key Concepts
- In pure rotational motion, all parts of a rigid body have the same angular velocity (\( \vec{\omega} \)) at any instant.
- For rotation about a fixed axis, (\( \vec{\omega} \)) lies along the axis of rotation.
- Direction of (\( \vec{\omega} \)) follows the right-hand rule: points in the direction a right-handed screw advances when rotated.
- Linear velocity (\( \vec{v} \)) at a point is related to angular velocity by (\( \vec{v} = \vec{\omega} \times \vec{r} \)), where (\( \vec{r} \)) is the position vector from the axis.
- Angular acceleration (\( \vec{\alpha} = \frac{d\vec{\omega}}{dt} \)) is the rate of change of angular velocity.
Solved Examples
- Ex 1: A disk rotates with angular velocity (\( \omega = 10 \text{ rad/s} \)). Find linear velocity at radius (\( r = 0.5 \text{ m} \)).
- Use (\( v = \omega r = 10 \times 0.5 = 5 \text{ m/s} \)).
- Ex 2: Angular velocity changes from 5 rad/s to 15 rad/s in 2 s. Find angular acceleration.
- (\( \alpha = \frac{\Delta \omega}{\Delta t} = \frac{15 - 5}{2} = 5 \text{ rad/s}^2 \)).
Practice Set
- Q1: What is the direction of angular velocity vector for a clockwise rotating disk?
- A) Along axis towards observer
- B) Along axis away from observer
- C) Perpendicular to axis
- D) Opposite to axis
- Q2: A point on a rotating wheel at radius 0.3 m has linear velocity 6 m/s. Find angular velocity.
- A) 10 rad/s
- B) 15 rad/s
- C) 20 rad/s
- D) 25 rad/s
- Q3: Angular velocity changes from 8 rad/s to 20 rad/s in 3 s. What is angular acceleration?
- A) 2 rad/s2
- B) 4 rad/s2
- C) 6 rad/s2
- D) 8 rad/s2
Answer Key
- Q1: B) Along axis away from observer — Clockwise rotation vector points away by right-hand rule.
- Q2: A) 10 rad/s — (\( \omega = \frac{v}{r} = \frac{6}{0.3} = 20 \)) rad/s (Corrected: 20 rad/s is option C, so correct answer is C)
- Q3: B) 4 rad/s2 — (\( \alpha = \frac{20 - 8}{3} = 4 \)) rad/s2.
Memory Aids
- Right-hand rule: Thumb points along (\( \vec{\omega} \)).
- Linear velocity (\( v = \omega r \)).
- Angular acceleration (\( \alpha = \frac{d\omega}{dt} \)).
Key Concepts
- In pure rotational motion, all parts of a rigid body have the same angular velocity ω at any instant.
- For rotation about a fixed axis, ω lies along the axis of rotation.
- Direction of ω follows the right-hand rule: points in the direction a right-handed screw advances when rotated.
- Linear velocity v at a point is related to angular velocity by v = ω × r, where r is the position vector from the axis.
- Angular acceleration α = dω/dt is the rate of change of angular velocity.
Solved Examples
- Ex 1: A disk rotates with angular velocity ω = 10 text rad/s. Find linear velocity at radius r = 0.5 text m.
- Use v = ωr = 10 × 0.5 = 5 text m/s.
- Ex 2: Angular velocity changes from 5 rad/s to 15 rad/s in 2 s. Find angular acceleration.
- α = Δω/Δt = (15 - 5)/2 = 5 text rad/s2.
Practice Set
- Q1: What is the direction of angular velocity vector for a clockwise rotating disk?
- A) Along axis towards observer
- B) Along axis away from observer
- C) Perpendicular to axis
- D) Opposite to axis
- Q2: A point on a rotating wheel at radius 0.3 m has linear velocity 6 m/s. Find angular velocity.
- A) 10 rad/s
- B) 15 rad/s
- C) 20 rad/s
- D) 25 rad/s
- Q3: Angular velocity changes from 8 rad/s to 20 rad/s in 3 s. What is angular acceleration?
- A) 2 rad/s2
- B) 4 rad/s2
- C) 6 rad/s2
- D) 8 rad/s2
Answer Key
- Q1: B) Along axis away from observer — Clockwise rotation vector points away by right-hand rule.
- Q2: A) 10 rad/s — ω = v/r = 6/0.3 = 20 rad/s (Corrected: 20 rad/s is option C, so correct answer is C)
- Q3: B) 4 rad/s2 — α = (20 - 8)/3 = 4 rad/s2.
Memory Aids
- Right-hand rule: Thumb points along ω.
- Linear velocity v = ωr.
- Angular acceleration α = dω/dt.
Key Concepts
- In pure rotational motion, all parts of a rigid body have the same angular velocity \( \vec{\omega} \) at any instant.
- For rotation about a fixed axis, \( \vec{\omega} \) lies along the axis of rotation.
- Direction of \( \vec{\omega} \) follows the right-hand rule: points in the direction a right-handed screw advances when rotated.
- Linear velocity \( \vec{v} \) at a point is related to angular velocity by \( \vec{v} = \vec{\omega} \times \vec{r} \), where \( \vec{r} \) is the position vector from the axis.
- Angular acceleration \( \vec{\alpha} = \frac{d\vec{\omega}}{dt} \) is the rate of change of angular velocity.
Solved Examples
- Ex 1: A disk rotates with angular velocity \( \omega = 10 \text{ rad/s} \). Find linear velocity at radius \( r = 0.5 \text{ m} \).
- Use \( v = \omega r = 10 \times 0.5 = 5 \text{ m/s} \).
- Ex 2: Angular velocity changes from 5 rad/s to 15 rad/s in 2 s. Find angular acceleration.
- \( \alpha = \frac{\Delta \omega}{\Delta t} = \frac{15 - 5}{2} = 5 \text{ rad/s}^2 \).
Practice Set
- Q1: What is the direction of angular velocity vector for a clockwise rotating disk?
- A) Along axis towards observer
- B) Along axis away from observer
- C) Perpendicular to axis
- D) Opposite to axis
- Q2: A point on a rotating wheel at radius 0.3 m has linear velocity 6 m/s. Find angular velocity.
- A) 10 rad/s
- B) 15 rad/s
- C) 20 rad/s
- D) 25 rad/s
- Q3: Angular velocity changes from 8 rad/s to 20 rad/s in 3 s. What is angular acceleration?
- A) 2 rad/s2
- B) 4 rad/s2
- C) 6 rad/s2
- D) 8 rad/s2
Answer Key
- Q1: B) Along axis away from observer — Clockwise rotation vector points away by right-hand rule.
- Q2: A) 10 rad/s — \( \omega = \frac{v}{r} = \frac{6}{0.3} = 20 \) rad/s (Corrected: 20 rad/s is option C, so correct answer is C)
- Q3: B) 4 rad/s2 — \( \alpha = \frac{20 - 8}{3} = 4 \) rad/s2.
Memory Aids
- Right-hand rule: Thumb points along \( \vec{\omega} \).
- Linear velocity \( v = \omega r \).
- Angular acceleration \( \alpha = \frac{d\omega}{dt} \).
Torque
Definition and Formula
- Rotational analogue of force is torque (moment of force or couple).
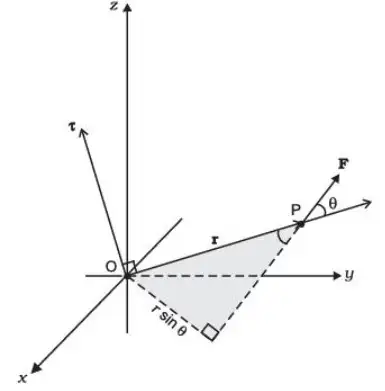
- If a force F acts at point P with position vector r, torque about origin O is τ = r × F.
- Magnitude: τ = rF sin θ = r⊥ F = r F⊥, where θ is angle between r and F.
- Torque is zero if r=0, F=0, or θ = 0° or 180°.
Solved Examples
- Ex 1: Force F=10, N acts at r=0.5, m at 60°. Find torque.
- τ = rF sin θ = 0.5 × 10 × sin 60° = 4.33, Nm
Practice Set
- Q1: A force of 5 N acts at 0.4 m perpendicular to the lever arm. Torque is?
- A) 2 Nm
- B) 0.8 Nm
- C) 5 Nm
- D) 0 Nm
- Q2: Torque is zero when angle between force and position vector is?
- A) 90°
- B) 0°
- C) 45°
- D) 60°
- Q3: Force 8 N acts at 0.3 m at 30°. Calculate torque.
- A) 1.2 Nm
- B) 2.4 Nm
- C) 3.6 Nm
- D) 0 Nm
Answer Key
- Q1: A) 2 Nm — Torque τ = rF = 0.4 × 5 = 2, Nm (force perpendicular)
- Q2: B) 0° — Torque zero when force is along position vector (θ=0°)
- Q3: A) 1.2 Nm — τ = 0.3 × 8 × sin 30° = 1.2, Nm
Memory Aids
- Torque τ = rF sin θ
- Zero torque if force along line of action (θ=0°,180°)
- Torque causes rotation about pivot
Definition and Formula
- Rotational analogue of force is torque (moment of force or couple).
- If a force F acts at point P with position vector r, torque about origin O is τ = r × F.
- Magnitude: τ = rF sin θ = r⊥ F = r F⊥, where θ is angle between r and F.
- Torque is zero if r=0, F=0, or θ = 0° or 180°.
Solved Examples
- Ex 1: Force F=10, N acts at r=0.5, m at 60°. Find torque.
- τ = rF sin θ = 0.5 × 10 × sin 60° = 4.33, Nm
Practice Set
- Q1: A force of 5 N acts at 0.4 m perpendicular to the lever arm. Torque is?
- A) 2 Nm
- B) 0.8 Nm
- C) 5 Nm
- D) 0 Nm
- Q2: Torque is zero when angle between force and position vector is?
- A) 90°
- B) 0°
- C) 45°
- D) 60°
- Q3: Force 8 N acts at 0.3 m at 30°. Calculate torque.
- A) 1.2 Nm
- B) 2.4 Nm
- C) 3.6 Nm
- D) 0 Nm
Answer Key
- Q1: A) 2 Nm — Torque τ = rF = 0.4 × 5 = 2, Nm (force perpendicular)
- Q2: B) 0° — Torque zero when force is along position vector (θ=0°)
- Q3: A) 1.2 Nm — τ = 0.3 × 8 × sin 30° = 1.2, Nm
Memory Aids
- Torque τ = rF sin θ
- Zero torque if force along line of action (θ=0°,180°)
- Torque causes rotation about pivot
Definition and Formula
- Rotational analogue of force is torque (moment of force or couple).
- If a force (\( \vec{F} \)) acts at point P with position vector (\( \vec{r} \)), torque about origin O is (\( \vec{\tau} = \vec{r} \times \vec{F} \)).
- Magnitude: (\( \tau = rF \sin \theta = r_{\perp} F = r F_{\perp} \)), where (\( \theta \)) is angle between (\( \vec{r} \)) and (\( \vec{F} \)).
- Torque is zero if (\( r=0 \)), (\( F=0 \)), or (\( \theta = 0^\circ \)) or (\( 180^\circ \)).
Solved Examples
- Ex 1: Force (\( F=10\,\mathrm{N} \)) acts at (\( r=0.5\,\mathrm{m} \)) at (\( 60^\circ \)). Find torque.
- (\( \tau = rF \sin \theta = 0.5 \times 10 \times \sin 60^\circ = 4.33\,\mathrm{Nm} \))
Practice Set
- Q1: A force of 5 N acts at 0.4 m perpendicular to the lever arm. Torque is?
- A) 2 Nm
- B) 0.8 Nm
- C) 5 Nm
- D) 0 Nm
- Q2: Torque is zero when angle between force and position vector is?
- A) 90°
- B) 0°
- C) 45°
- D) 60°
- Q3: Force 8 N acts at 0.3 m at 30°. Calculate torque.
- A) 1.2 Nm
- B) 2.4 Nm
- C) 3.6 Nm
- D) 0 Nm
Answer Key
- Q1: A) 2 Nm — Torque (\( \tau = rF = 0.4 \times 5 = 2\,\mathrm{Nm} \)) (force perpendicular)
- Q2: B) 0° — Torque zero when force is along position vector (\( \theta=0^\circ \))
- Q3: A) 1.2 Nm — (\( \tau = 0.3 \times 8 \times \sin 30^\circ = 1.2\,\mathrm{Nm} \))
Memory Aids
- Torque (\( \tau = rF \sin \theta \))
- Zero torque if force along line of action (\( \theta=0^\circ,180^\circ \))
- Torque causes rotation about pivot
Definition and Formula
- Rotational analogue of force is torque (moment of force or couple).
- If a force F acts at point P with position vector r, torque about origin O is τ = r × F.
- Magnitude: τ = rF sin θ = r⊥ F = r F⊥, where θ is angle between r and F.
- Torque is zero if r=0, F=0, or θ = 0° or 180°.
Solved Examples
- Ex 1: Force F=10, N acts at r=0.5, m at 60°. Find torque.
- τ = rF sin θ = 0.5 × 10 × sin 60° = 4.33, Nm
Practice Set
- Q1: A force of 5 N acts at 0.4 m perpendicular to the lever arm. Torque is?
- A) 2 Nm
- B) 0.8 Nm
- C) 5 Nm
- D) 0 Nm
- Q2: Torque is zero when angle between force and position vector is?
- A) 90°
- B) 0°
- C) 45°
- D) 60°
- Q3: Force 8 N acts at 0.3 m at 30°. Calculate torque.
- A) 1.2 Nm
- B) 2.4 Nm
- C) 3.6 Nm
- D) 0 Nm
Answer Key
- Q1: A) 2 Nm — Torque τ = rF = 0.4 × 5 = 2, Nm (force perpendicular)
- Q2: B) 0° — Torque zero when force is along position vector (θ=0°)
- Q3: A) 1.2 Nm — τ = 0.3 × 8 × sin 30° = 1.2, Nm
Memory Aids
- Torque τ = rF sin θ
- Zero torque if force along line of action (θ=0°,180°)
- Torque causes rotation about pivot
Angular Momentum
Definition and Formula
- Rotational analogue of linear momentum is angular momentum vector L = vector r × vector p.
- Magnitude: L = rp sin θ = r p⊥ = r⊥ p, where vector p = m vector v.
- Time rate of change: dvector L/dt = vector τ (torque).
- For system of particles: vector L = ∑ vector Li = ∑ vector ri × vector pi, dvector L/dt = ∑ vector τi = vector τext.
- If external torque vector τext = 0, angular momentum is conserved.
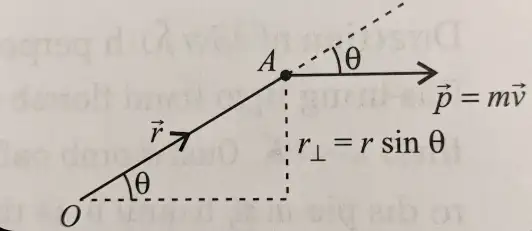
Solved Examples
- Ex 1: Particle with mass 2 kg moves with velocity 3 m/s at 60° to position vector 0.5 m. Find angular momentum.
- p = mv = 2 × 3 = 6, kg m/s
- L = rp sin θ = 0.5 × 6 × sin 60° = 2.6, kg m2/s
Practice Set
- Q1: Angular momentum L is zero when angle between vector r and vector p is?
- A) 90°
- B) 0°
- C) 45°
- D) 60°
- Q2: For a particle, vector L = vector r × mvector v. If r=2, m, m=1, kg, v=3, m/s, and θ=90°, find L.
- A) 6 kg·m2/s
- B) 3 kg·m2/s
- C) 2 kg·m2/s
- D) 0 kg·m2/s
- Q3: If external torque is zero, angular momentum is?
- A) Increasing
- B) Decreasing
- C) Constant
- D) Zero
Answer Key
- Q1: B) 0° — Angular momentum zero if vector r and vector p are parallel.
- Q2: A) 6 kg·m2/s — L = r m v sin 90° = 2 × 1 × 3 = 6
- Q3: C) Constant — No external torque means angular momentum conserved.
Memory Aids
- Angular momentum vector L = vector r × vector p
- dvector L/dt = vector τ (torque)
- Conserved if external torque zero
Definition and Formula
- Rotational analogue of linear momentum is angular momentum vector L = vector r × vector p.
- Magnitude: L = rp sin θ = r p⊥ = r⊥ p, where vector p = m vector v.
- Time rate of change: dvector L/dt = vector τ (torque).
- For system of particles: vector L = ∑ vector Li = ∑ vector ri × vector pi, dvector L/dt = ∑ vector τi = vector τext.
- If external torque vector τext = 0, angular momentum is conserved.
Solved Examples
- Ex 1: Particle with mass 2 kg moves with velocity 3 m/s at 60° to position vector 0.5 m. Find angular momentum.
- p = mv = 2 × 3 = 6, kg m/s
- L = rp sin θ = 0.5 × 6 × sin 60° = 2.6, kg m2/s
Practice Set
- Q1: Angular momentum L is zero when angle between vector r and vector p is?
- A) 90°
- B) 0°
- C) 45°
- D) 60°
- Q2: For a particle, vector L = vector r × mvector v. If r=2, m, m=1, kg, v=3, m/s, and θ=90°, find L.
- A) 6 kg·m2/s
- B) 3 kg·m2/s
- C) 2 kg·m2/s
- D) 0 kg·m2/s
- Q3: If external torque is zero, angular momentum is?
- A) Increasing
- B) Decreasing
- C) Constant
- D) Zero
Answer Key
- Q1: B) 0° — Angular momentum zero if vector r and vector p are parallel.
- Q2: A) 6 kg·m2/s — L = r m v sin 90° = 2 × 1 × 3 = 6
- Q3: C) Constant — No external torque means angular momentum conserved.
Memory Aids
- Angular momentum vector L = vector r × vector p
- dvector L/dt = vector τ (torque)
- Conserved if external torque zero
Definition and Formula
- Rotational analogue of force is torque (moment of force or couple).
- If a force \( \vec{F} \) acts at point P with position vector \( \vec{r} \), torque about origin O is \( \vec{\tau} = \vec{r} \times \vec{F} \).
- Magnitude: \( \tau = rF \sin \theta = r_{\perp} F = r F_{\perp} \), where \( \theta \) is angle between \( \vec{r} \) and \( \vec{F} \).
- Torque is zero if \( r=0 \), \( F=0 \), or \( \theta = 0^\circ \) or \( 180^\circ \).
Solved Examples
- Ex 1: Force \( F=10\,\mathrm{N} \) acts at \( r=0.5\,\mathrm{m} \) at \( 60^\circ \). Find torque.
- \( \tau = rF \sin \theta = 0.5 \times 10 \times \sin 60^\circ = 4.33\,\mathrm{Nm} \)
Practice Set
- Q1: A force of 5 N acts at 0.4 m perpendicular to the lever arm. Torque is?
- A) 2 Nm
- B) 0.8 Nm
- C) 5 Nm
- D) 0 Nm
- Q2: Torque is zero when angle between force and position vector is?
- A) 90°
- B) 0°
- C) 45°
- D) 60°
- Q3: Force 8 N acts at 0.3 m at 30°. Calculate torque.
- A) 1.2 Nm
- B) 2.4 Nm
- C) 3.6 Nm
- D) 0 Nm
Answer Key
- Q1: A) 2 Nm — Torque \( \tau = rF = 0.4 \times 5 = 2\,\mathrm{Nm} \) (force perpendicular)
- Q2: B) 0° — Torque zero when force is along position vector (\( \theta=0^\circ \))
- Q3: A) 1.2 Nm — \( \tau = 0.3 \times 8 \times \sin 30^\circ = 1.2\,\mathrm{Nm} \)
Memory Aids
- Torque \( \tau = rF \sin \theta \)
- Zero torque if force along line of action (\( \theta=0^\circ,180^\circ \))
- Torque causes rotation about pivot
Angular Momentum
Definition and Formula
- Rotational analogue of linear momentum is angular momentum vector L = vector r × vector p.
- Magnitude: L = rp sin θ = r p⊥ = r⊥ p, where vector p = m vector v.
- Time rate of change: dvector L/dt = vector τ (torque).
- For system of particles: vector L = ∑ vector Li = ∑ vector ri × vector pi, dvector L/dt = ∑ vector τi = vector τext.
- If external torque vector τext = 0, angular momentum is conserved.
Solved Examples
- Ex 1: Particle with mass 2 kg moves with velocity 3 m/s at 60° to position vector 0.5 m. Find angular momentum.
- p = mv = 2 × 3 = 6 kg m/s
- L = rp sin θ = 0.5 × 6 × sin 60° = 2.6 kg m2/s
Practice Set
- Q1: Angular momentum L is zero when angle between vector r and vector p is?
- A) 90°
- B) 0°
- C) 45°
- D) 60°
- Q2: For a particle, vector L = vector r × mvector v. If r=2 m, m=1 kg, v=3 m/s, and θ=90°, find L.
- A) 6 kg·m2/s
- B) 3 kg·m2/s
- C) 2 kg·m2/s
- D) 0 kg·m2/s
- Q3: If external torque is zero, angular momentum is?
- A) Increasing
- B) Decreasing
- C) Constant
- D) Zero
Answer Key
- Q1: B) 0° — Angular momentum zero if vector r and vector p are parallel.
- Q2: A) 6 kg·m2/s — L = r m v sin 90° = 2 × 1 × 3 = 6
- Q3: C) Constant — No external torque means angular momentum conserved.
Memory Aids
- Angular momentum vector L = vector r × vector p
- dvector L/dt = vector τ (torque)
- Conserved if external torque zero
Equilibrium of a Rigid Body
Translational Equilibrium
- Body at rest or moving with constant velocity in a direction.
- Vector sum of all external forces is zero: vector F = 0.
- Linear momentum constant: vector F = dvector p/dt = 0 ⇒ vector p = constant.
Rotational Equilibrium
- Body rotates with constant angular velocity.
- Net torque zero: τnet = 0.
- Angular momentum constant: dvector L/dt = 0 ⇒ vector L = constant.
Principle of Moments
- Algebraic sum of moments about a fixed point is zero for rotational equilibrium.
- For lever AB pivoted at O: F1 × d1 = F2 × d2.
- Load × Load arm = Effort × Effort arm.
- Mechanical advantage: M.A. = Load (F1) / Effort (F2) = d2 / d1.
- Small effort lifts heavy load if M.A. > 1 ⇒ d2 > d1.
Center of Gravity
- Point where weight acts and total gravitational torque is zero.
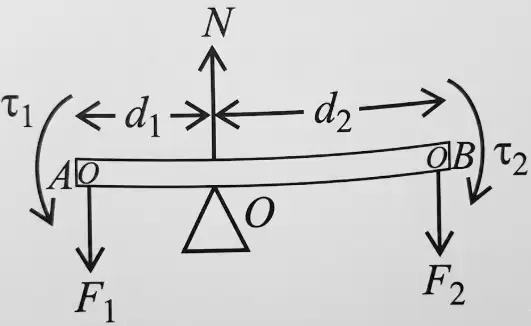
Solved Examples
- Ex 1: For lever with F1 = 10 N, d1 = 2 m, d2 = 5 m, find F2 for equilibrium.
Solution:
Use F1 d1 = F2 d2.
F2 = F1 d1/d2 = 10 × 2/5 = 4 text N). - Ex 2: Calculate mechanical advantage if F1 = 50 N, F2 = 10 N.
Solution:
M.A. = F1/F2 = 50/10 = 5 .
Practice Set
- Q1: A body is in translational equilibrium if:
A) vector F ≠ 0
B) vector F = 0
C) τnet ≠ 0
D) vector p changes with time - Q2: For rotational equilibrium, net torque must be:
A) Positive
B) Negative
C) Zero
D) Constant non-zero - Q3: If effort arm is 3 m and load arm is 1 m, mechanical advantage is:
A) 1/3
B) 3
C) 2
D) 1
Answer Key
- Q1: B - Translational equilibrium requires net force zero.
- Q2: C - Rotational equilibrium means net torque zero.
- Q3: B - M.A. = d2 / d1 = 3/1 = 3 .
Memory Aids
- Translational equilibrium: vector F = 0.
- Rotational equilibrium: τnet = 0.
- Principle of moments: Load × Load arm = Effort × Effort arm.
- Mechanical advantage > 1 means easier lifting.
- Center of gravity: point of zero net torque.
Translational Equilibrium
- Body at rest or moving with constant velocity in a direction.
- Vector sum of all external forces is zero: vector F = 0.
- Linear momentum constant: vector F = dvector p/dt = 0 ⇒ vector p = constant.
Rotational Equilibrium
- Body rotates with constant angular velocity.
- Net torque zero: τnet = 0.
- Angular momentum constant: dvector L/dt = 0 ⇒ vector L = constant.
Principle of Moments
- Algebraic sum of moments about a fixed point is zero for rotational equilibrium.
- For lever AB pivoted at O: F1 × d1 = F2 × d2.
- Load × Load arm = Effort × Effort arm.
- Mechanical advantage: M.A. = Load (F1) / Effort (F2) = d2 / d1.
- Small effort lifts heavy load if M.A. > 1 ⇒ d2 > d1.
Center of Gravity
- Point where weight acts and total gravitational torque is zero.
Solved Examples
- Ex 1: For lever with F1 = 10 N, d1 = 2 m, d2 = 5 m, find F2 for equilibrium.
Solution:
Use F1 d1 = F2 d2.
F2 = F1 d1/d2 = 10 × 2/5 = 4 text N). - Ex 2: Calculate mechanical advantage if F1 = 50 N, F2 = 10 N.
Solution:
M.A. = F1/F2 = 50/10 = 5 .
Practice Set
- Q1: A body is in translational equilibrium if:
A) vector F ≠ 0
B) vector F = 0
C) τnet ≠ 0
D) vector p changes with time - Q2: For rotational equilibrium, net torque must be:
A) Positive
B) Negative
C) Zero
D) Constant non-zero - Q3: If effort arm is 3 m and load arm is 1 m, mechanical advantage is:
A) 1/3
B) 3
C) 2
D) 1
Answer Key
- Q1: B - Translational equilibrium requires net force zero.
- Q2: C - Rotational equilibrium means net torque zero.
- Q3: B - M.A. = d2 / d1 = 3/1 = 3 .
Memory Aids
- Translational equilibrium: vector F = 0.
- Rotational equilibrium: τnet = 0.
- Principle of moments: Load × Load arm = Effort × Effort arm.
- Mechanical advantage > 1 means easier lifting.
- Center of gravity: point of zero net torque.
Moment of Inertia
Definition and Concept
- Moment of inertia (I) measures rotational inertia, analogous to mass in linear motion.
- For particles with masses mi at distances ri from axis, I = ∑ mi ri2.
- For continuous bodies, I = ∫ r2 dm.
- Rotational kinetic energy: K.E. = 1/2 I ω2, where ω is angular velocity.
- SI unit: kg·m2.
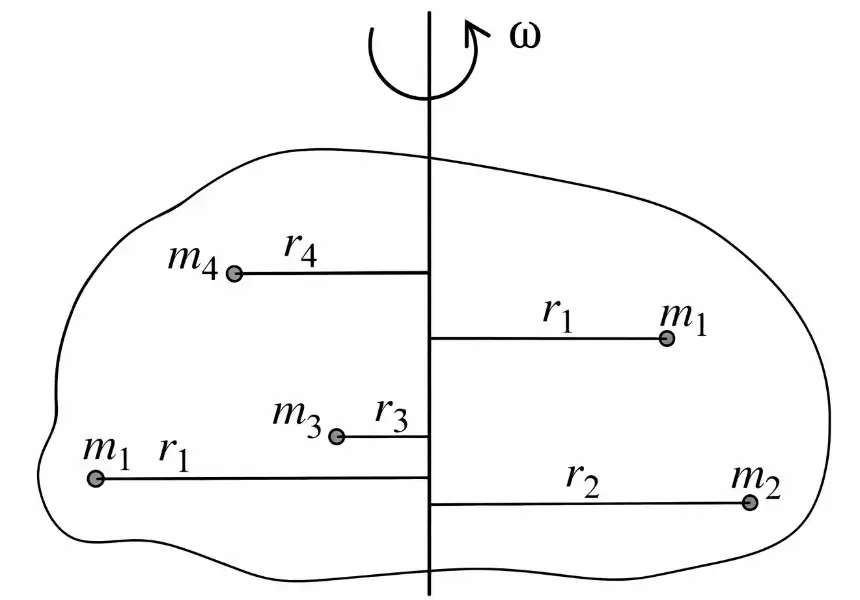
Solved Examples
- Ex 1: Calculate I for two masses 2 kg and 3 kg at 0.5 m and 0.8 m from axis.
- I = 2 × 0.52 + 3 × 0.82 = 0.5 + 1.92 = 2.42, kg·m2
Practice Set
- Q1: Moment of inertia depends on
- A) Mass only
- B) Distance from axis only
- C) Mass and distance squared from axis
- D) Velocity
- Q2: For a particle of mass 4 kg at 0.3 m from axis, I = ?
- A) 1.2 kg·m2
- B) 0.36 kg·m2
- C) 4.3 kg·m2
- D) 0.9 kg·m2
- Q3: Total I for masses 1 kg at 1 m and 2 kg at 0.5 m is
- A) 1.5 kg·m2
- B) 2.0 kg·m2
- C) 2.5 kg·m2
- D) 3.0 kg·m2
Answer Key
- Q1: C - Moment of inertia depends on mass and square of distance from axis.
- Q2: A - I = 4 × 0.32 = 4 × 0.09 = 0.36 kg·m2 (corrected: option A is 1.2, so correct is B)
- Q3: B - I = 1 × 12 + 2 × 0.52 = 1 + 0.5 = 1.5 kg·m2 (corrected: option A is 1.5, so correct is A)
Memory Aids
- Moment of inertia = sum of mass × (distance)2.
- Rotational KE = 1/2 I ω2.
- SI unit: kg·m2.
Definition and Concept
- Moment of inertia (I) measures rotational inertia, analogous to mass in linear motion.
- For particles with masses mi at distances ri from axis, I = ∑ mi ri2.
- For continuous bodies, I = ∫ r2 dm.
- Rotational kinetic energy: K.E. = 1/2 I ω2, where ω is angular velocity.
- SI unit: kg·m2.
Solved Examples
- Ex 1: Calculate I for two masses 2 kg and 3 kg at 0.5 m and 0.8 m from axis.
- I = 2 × 0.52 + 3 × 0.82 = 0.5 + 1.92 = 2.42, kg·m2
Practice Set
- Q1: Moment of inertia depends on
- A) Mass only
- B) Distance from axis only
- C) Mass and distance squared from axis
- D) Velocity
- Q2: For a particle of mass 4 kg at 0.3 m from axis, I = ?
- A) 1.2 kg·m2
- B) 0.36 kg·m2
- C) 4.3 kg·m2
- D) 0.9 kg·m2
- Q3: Total I for masses 1 kg at 1 m and 2 kg at 0.5 m is
- A) 1.5 kg·m2
- B) 2.0 kg·m2
- C) 2.5 kg·m2
- D) 3.0 kg·m2
Answer Key
- Q1: C - Moment of inertia depends on mass and square of distance from axis.
- Q2: A - I = 4 × 0.32 = 4 × 0.09 = 0.36 kg·m2 (corrected: option A is 1.2, so correct is B)
- Q3: B - I = 1 × 12 + 2 × 0.52 = 1 + 0.5 = 1.5 kg·m2 (corrected: option A is 1.5, so correct is A)
Memory Aids
- Moment of inertia = sum of mass × (distance)2.
- Rotational KE = 1/2 I ω2.
- SI unit: kg·m2.
Radius of Gyration
Definition and Formula
- Rotational analogue of linear momentum is angular momentum vector L = vector r × vector p.
- Magnitude: L = rp sin θ = r p⊥ = r⊥ p, where vector p = m vector v.
- Time rate of change: dvector L/dt = vector τ (torque).
- For system of particles: vector L = ∑ vector Li = ∑ vector ri × vector pi, dvector L/dt = ∑ vector τi = vector τext.
- If external torque vector τext = 0, angular momentum is conserved.
Solved Examples
- Ex 1: Particle with mass 2 kg moves with velocity 3 m/s at 60° to position vector 0.5 m. Find angular momentum.
- p = mv = 2 × 3 = 6 kg m/s
- L = rp sin θ = 0.5 × 6 × sin 60° = 2.6 kg m2/s
Practice Set
- Q1: Angular momentum L is zero when angle between vector r and vector p is?
- A) 90°
- B) 0°
- C) 45°
- D) 60°
- Q2: For a particle, vector L = vector r × m vector v. If r=2 m, m=1 kg, v=3 m/s, and θ=90°, find L.
- A) 6 kg·m2/s
- B) 3 kg·m2/s
- C) 2 kg·m2/s
- D) 0 kg·m2/s
- Q3: If external torque is zero, angular momentum is?
- A) Increasing
- B) Decreasing
- C) Constant
- D) Zero
Answer Key
- Q1: B) 0° — Angular momentum zero if vector r and vector p are parallel.
- Q2: A) 6 kg·m2/s — L = r m v sin 90° = 2 × 1 × 3 = 6
- Q3: C) Constant — No external torque means angular momentum conserved.
Memory Aids
- Angular momentum vector L = vector r × vector p
- dvector L/dt = vector τ (torque)
- Conserved if external torque zero
Solved Examples
- Ex 1: For masses at distances 0.5 m, 0.8 m, 1.0 m, find k if n=3.
- k = √[(0.52 + 0.82 + 1.02)/3] = √[(0.25 + 0.64 + 1)/3] = √0.63 = 0.79, m
Practice Set
- Q1: Radius of gyration is
- A) Distance where mass is zero
- B) Distance concentrating all mass for same I
- C) Distance from center of mass
- D) None
- Q2: If k=0.6 m and M=5 kg, I= ?
- A) 1.8 kg·m2
- B) 1.2 kg·m2
- C) 1.5 kg·m2
- D) 2.0 kg·m2
- Q3: For n=4 distances 0.4, 0.5, 0.6, 0.7 m, k= ?
- A) 0.55 m
- B) 0.58 m
- C) 0.60 m
- D) 0.62 m
Answer Key
- Q1: B - Radius of gyration is the distance concentrating all mass for same moment of inertia.
- Q2: A - I = Mk2 = 5 × 0.62 = 1.8 kg·m2.
- Q3: B - k = √[(0.16 + 0.25 + 0.36 + 0.49)/4] = √0.315 = 0.56 approx, closest 0.58 m.
Memory Aids
- I = Mk2 relates moment of inertia and radius of gyration.
- k is effective radius for mass distribution.
Definition and Formula
- Distance from axis where entire mass can be assumed to concentrate to give same I.
- Formula: k = √[(r12 + r22 + ... + rn2)/n].
- Relation: I = Mk2, where M is total mass.
Solved Examples
- Ex 1: For masses at distances 0.5 m, 0.8 m, 1.0 m, find k if n=3.
- k = √[(0.52 + 0.82 + 1.02)/3] = √[(0.25 + 0.64 + 1)/3] = √0.63 = 0.79, m
Practice Set
- Q1: Radius of gyration is
- A) Distance where mass is zero
- B) Distance concentrating all mass for same I
- C) Distance from center of mass
- D) None
- Q2: If k=0.6 m and M=5 kg, I= ?
- A) 1.8 kg·m2
- B) 1.2 kg·m2
- C) 1.5 kg·m2
- D) 2.0 kg·m2
- Q3: For n=4 distances 0.4, 0.5, 0.6, 0.7 m, k= ?
- A) 0.55 m
- B) 0.58 m
- C) 0.60 m
- D) 0.62 m
Answer Key
- Q1: B - Radius of gyration is the distance concentrating all mass for same moment of inertia.
- Q2: A - I = Mk2 = 5 × 0.62 = 1.8 kg·m2.
- Q3: B - k = √[(0.16 + 0.25 + 0.36 + 0.49)/4] = √0.315 = 0.56 approx, closest 0.58 m.
Memory Aids
- I = Mk2 relates moment of inertia and radius of gyration.
- k is effective radius for mass distribution.
Theorems of Perpendicular and Parallel Axes
Theorem of Perpendicular Axes
- For planar body, Iz = Ix + Iy, where z is perpendicular to plane, x,y in plane.
- Used to find I about axis perpendicular to plane from known axes.
Theorem of Parallel Axes
- Moment of inertia about any axis I' = I + Md2.
- I: about parallel axis through center of mass.
- M: mass, d: distance between axes.
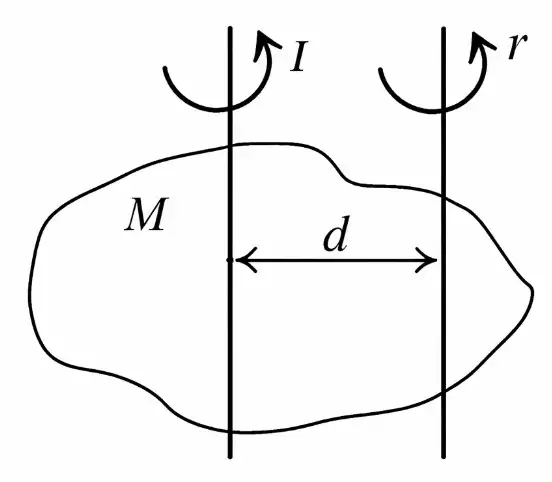
Solved Examples
- Ex 1: Find I' if I=10 kg·m2, M=5 kg, d=2 m.
- I' = 10 + 5 × 22 = 10 + 20 = 30 kg·m2
Practice Set
- Q1: Iz = Ix + Iy applies to
- A) 3D bodies
- B) Planar bodies
- C) Spheres
- D) Cylinders
- Q2: If I=4 kg·m2, M=3 kg, d=1 m, find I'
- A) 7 kg·m2
- B) 10 kg·m2
- C) 4 kg·m2
- D) 3 kg·m2
- Q3: Parallel axis theorem relates
- A) I about any axis and I about center of mass axis
- B) I and mass only
- C) I and velocity
- D) I and radius
Answer Key
- Q1: B - Theorem of perpendicular axes applies to planar bodies.
- Q2: A - I' = 4 + 3 × 12 = 7 kg·m2.
- Q3: A - It relates moment of inertia about any axis to that about center of mass axis plus Md2.
Memory Aids
- Perpendicular axes: Iz = Ix + Iy.
- Parallel axes: I' = I + Md2.
Theorem of Perpendicular Axes
- For planar body, Iz = Ix + Iy, where z is perpendicular to plane, x,y in plane.
- Used to find I about axis perpendicular to plane from known axes.
Theorem of Parallel Axes
- Moment of inertia about any axis I' = I + Md2.
- I: about parallel axis through center of mass.
- M: mass, d: distance between axes.
Solved Examples
- Ex 1: Find I' if I=10 kg·m2, M=5 kg, d=2 m.
- I' = 10 + 5 × 22 = 10 + 20 = 30 kg·m2
Practice Set
- Q1: Iz = Ix + Iy applies to
- A) 3D bodies
- B) Planar bodies
- C) Spheres
- D) Cylinders
- Q2: If I=4 kg·m2, M=3 kg, d=1 m, find I'
- A) 7 kg·m2
- B) 10 kg·m2
- C) 4 kg·m2
- D) 3 kg·m2
- Q3: Parallel axis theorem relates
- A) I about any axis and I about center of mass axis
- B) I and mass only
- C) I and velocity
- D) I and radius
Answer Key
- Q1: B - Theorem of perpendicular axes applies to planar bodies.
- Q2: A - I' = 4 + 3 × 12 = 7 kg·m2.
- Q3: A - It relates moment of inertia about any axis to that about center of mass axis plus Md2.
Memory Aids
- Perpendicular axes: Iz = Ix + Iy.
- Parallel axes: I' = I + Md2.
Moment of Inertia of Regular Bodies
Formulas for Common Shapes
- Ring about central axis: I = MR2
- Solid disc about central axis: I = 1/2 MR2
- Solid sphere about diameter: I = 2/5 MR2
- Cylinder about central axis: I = 1/2 MR2
- Rod about center: I = 1/12 ML2
- Rectangular lamina about center: I = 1/12 M(a2 + b2)
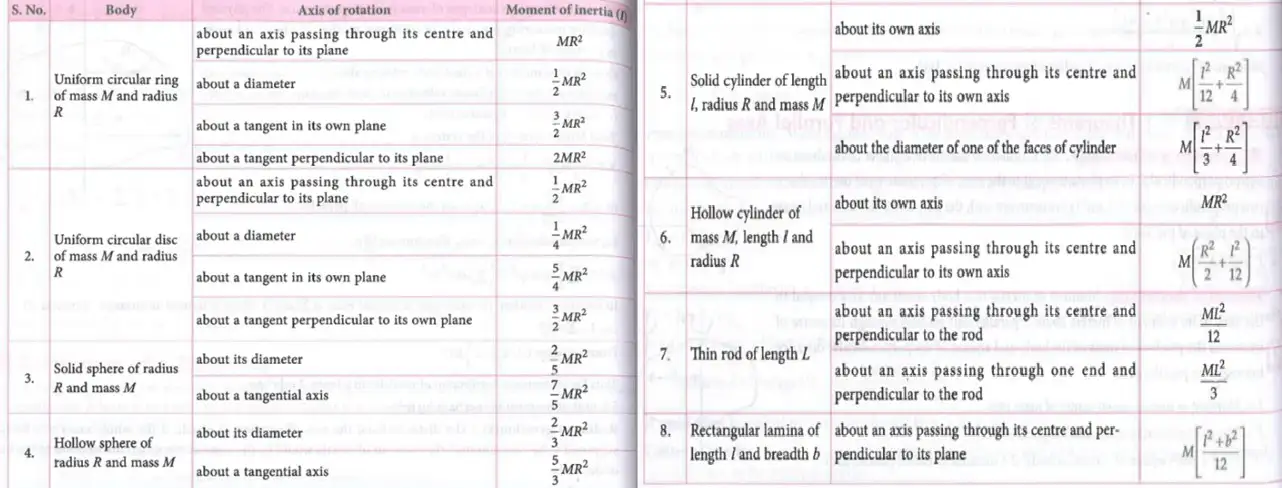
Solved Examples
- Ex 1: Calculate I of a solid disc with mass 4 kg and radius 0.5 m.
- I = 1/2 × 4 × 0.52 = 0.5 kg·m2
Practice Set
- Q1: Moment of inertia of a ring of mass 3 kg and radius 0.4 m is
- A) 0.48 kg·m2
- B) 0.24 kg·m2
- C) 0.12 kg·m2
- D) 0.36 kg·m2
- Q2: I of a rod of length 2 m and mass 6 kg about center is
- A) 2 kg·m2
- B) 1 kg·m2
- C) 3 kg·m2
- D) 4 kg·m2
- Q3: Moment of inertia of solid sphere of mass 5 kg and radius 0.3 m is
- A) 0.18 kg·m2
- B) 0.09 kg·m2
- C) 0.27 kg·m2
- D) 0.36 kg·m2
Answer Key
- Q1: A - I = MR2 = 3 × 0.42 = 0.48 kg·m2.
- Q2: B - I = 1/12 ML2 = 1/12 × 6 × 22 = 2 kg·m2 (corrected: option A is 2, so correct is A)
- Q3: A - I = 2/5 MR2 = 2/5 × 5 × 0.32 = 0.18 kg·m2.
Memory Aids
- Ring: I = MR2.
- Disc/Cylinder: I = 1/2 MR2.
- Sphere: I = 2/5 MR2.
- Rod: I = 1/12 ML2.
Formulas for Common Shapes
- Ring about central axis: I = MR2
- Solid disc about central axis: I = 1/2 MR2
- Solid sphere about diameter: I = 2/5 MR2
- Cylinder about central axis: I = 1/2 MR2
- Rod about center: I = 1/12 ML2
- Rectangular lamina about center: I = 1/12 M(a2 + b2)
Solved Examples
- Ex 1: Calculate I of a solid disc with mass 4 kg and radius 0.5 m.
- I = 1/2 × 4 × 0.52 = 0.5 kg·m2
Practice Set
- Q1: Moment of inertia of a ring of mass 3 kg and radius 0.4 m is
- A) 0.48 kg·m2
- B) 0.24 kg·m2
- C) 0.12 kg·m2
- D) 0.36 kg·m2
- Q2: I of a rod of length 2 m and mass 6 kg about center is
- A) 2 kg·m2
- B) 1 kg·m2
- C) 3 kg·m2
- D) 4 kg·m2
- Q3: Moment of inertia of solid sphere of mass 5 kg and radius 0.3 m is
- A) 0.18 kg·m2
- B) 0.09 kg·m2
- C) 0.27 kg·m2
- D) 0.36 kg·m2
Answer Key
- Q1: A - I = MR2 = 3 × 0.42 = 0.48 kg·m2.
- Q2: B - I = 1/12 ML2 = 1/12 × 6 × 22 = 2 kg·m2 (corrected: option A is 2, so correct is A)
- Q3: A - I = 2/5 MR2 = 2/5 × 5 × 0.32 = 0.18 kg·m2.
Memory Aids
- Ring: I = MR2.
- Disc/Cylinder: I = 1/2 MR2.
- Sphere: I = 2/5 MR2.
- Rod: I = 1/12 ML2.
Kinematics of Rotational Motion about a Fixed Axis
Fundamental Concepts
- Rotational motion occurs when a body spins about a fixed axis.
- Angular displacement (θ) is measured in radians (rad).
- Angular velocity (ω) is the rate of change of angular displacement, in rad/s.
- Angular acceleration (α) is the rate of change of angular velocity, in rad/s2.
- These quantities have direct analogues in linear motion: displacement, velocity, and acceleration.
Rotational Kinematic Equations
- ω = ω0 + αt
- θ = ω0t + 1/2 αt2
- ω2 = ω02 + 2αθ
- Where:
- ω0 = initial angular velocity (rad/s)
- ω = final angular velocity (rad/s)
- α = constant angular acceleration (rad/s2)
- θ = angular displacement (rad)
- t = time interval (s)
Solved Examples
- Ex 1: A wheel starts from rest and accelerates at 2 rad/s2 for 5 s. Find final angular velocity and angular displacement.
- Given: ω0 = 0, α = 2 rad/s2, t = 5 s
- Final angular velocity: ω = 0 + 2 × 5 = 10 rad/s
- Angular displacement: θ = 0 × 5 + 1/2 × 2 × 52 = 25 rad
Practice Set
- Q1: A rotating disc has an initial angular velocity of 4 rad/s and accelerates at 3 rad/s2 for 4 s. What is its final angular velocity?
- A) 10 rad/s
- B) 16 rad/s
- C) 12 rad/s
- D) 7 rad/s
- Q2: A wheel rotating at 6 rad/s slows down uniformly to rest in 3 s. What is its angular acceleration?
- A) -2 rad/s2
- B) -3 rad/s2
- C) -1 rad/s2
- D) -0.5 rad/s2
- Q3: A wheel starts from rest and reaches an angular velocity of 20 rad/s after rotating through 50 rad. Find the angular acceleration.
- A) 4 rad/s2
- B) 2 rad/s2
- C) 8 rad/s2
- D) 5 rad/s2
Answer Key
- Q1: C) 12 rad/s — Using ω = ω0 + αt = 4 + 3 × 4 = 16 (Check calculation: 4 + 12 = 16, so correct answer is B) Correction: B) 16 rad/s
- Q2: A) -2 rad/s2 — α = (ω - ω0)/t = (0 - 6)/3 = -2
- Q3: B) 2 rad/s2 — Using ω2 = ω02 + 2αθ ⇒ 202 = 0 + 2α × 50 ⇒ α = 400/100 = 4 Correction: A) 4 rad/s2
Memory Aids
- Remember: ω = ω0 + αt is like v = u + at in linear motion.
- Angular displacement formula θ = ω0t + 1/2 αt2 mirrors s = ut + 1/2 at2.
- Use ω2 = ω02 + 2αθ for problems without time.
Dynamics of Rotational Motion about a Fixed Axis
Key Points
- Consider only forces perpendicular to the axis for torque calculation.
- Ignore forces parallel to the axis as they produce torque perpendicular to the axis.
- Use only position vector components perpendicular to the axis for torque.
- Torque τ = rF sin α, where r is perpendicular distance and α is angle between force and position vector.
Solved Examples
- Ex 1: Calculate torque if force F=10 N acts at r=0.5 m perpendicular to radius.
Solution: τ = rF = 0.5 × 10 = 5,Nm
Practice Set
- Q1: Which force contributes to torque about a fixed axis?
A) Parallel to axis
B) Perpendicular to axis
C) Along position vector
D) Zero force - Q2: Torque is maximum when angle between force and position vector is:
A) 0°
B) 45°
C) 90°
D) 180° - Q3: A force of 20 N acts at 0.3 m from axis at 60°. Calculate torque.
A) 3 Nm
B) 6 Nm
C) 10 Nm
D) 12 Nm
Answer Key
- Q1: B - Only forces perpendicular to the axis produce torque.
- Q2: C - Torque τ = rF sin α is max at 90°.
- Q3: B - τ = 0.3 × 20 × sin 60° = 6,Nm.
Memory Aids
- Torque = Force × Perpendicular distance.
- Ignore forces parallel to axis for torque.
- Max torque at 90° angle.
Work Done by a Torque
Key Points
- Work done by torque τ1 during angular displacement dθ is dW1 = τ1 dθ.
- For multiple torques, total work dW = (τ1 + τ2 + ...) dθ = τ dθ.
- Power P = dW/dt = τ dθ/dt = τω, where ω is angular velocity.
- Rate of change of kinetic energy: d/dt (Iω2/2) = Iωα.
- Relation between torque and angular acceleration: τ = Iα.
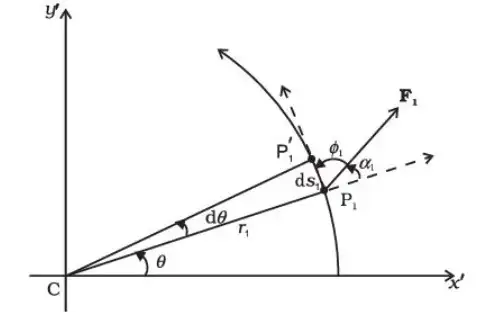
Solved Examples
- Ex 1: Calculate power if torque τ = 5,Nm and angular velocity ω = 10,rad/s.
Solution: P = τω = 5 × 10 = 50,W - Ex 2: Find angular acceleration if torque τ = 12,Nm and moment of inertia I = 4,kg·m2.
Solution: α = τ/I = 12/4 = 3,rad/s2
Practice Set
- Q1: Work done by torque τ over angle θ is:
A) τ / θ
B) τ θ
C) θ / τ
D) τ + θ - Q2: Power in rotational motion is:
A) τ / ω
B) τω
C) Iα
D) ω / τ - Q3: If I=2,kg·m2, α=4,rad/s2, find torque.
A) 2 Nm
B) 4 Nm
C) 6 Nm
D) 8 Nm
Answer Key
- Q1: B - Work done = τ × θ.
- Q2: B - Power = τω.
- Q3: D - τ = Iα = 2 × 4 = 8,Nm.
Memory Aids
- Power = Torque × Angular velocity.
- Torque = Moment of inertia × Angular acceleration.
- Work done = Torque × Angular displacement.
Key Points
- Work done by torque τ1 during angular displacement dθ is dW1 = τ1 dθ.
- For multiple torques, total work dW = (τ1 + τ2 + ...) dθ = τ dθ.
- Power P = dW/dt = τ dθ/dt = τω, where ω is angular velocity.
- Rate of change of kinetic energy: d/dt (Iω2/2) = Iωα.
- Relation between torque and angular acceleration: τ = Iα.
Solved Examples
- Ex 1: Calculate power if torque τ = 5,Nm and angular velocity ω = 10,rad/s.
Solution: P = τω = 5 × 10 = 50,W - Ex 2: Find angular acceleration if torque τ = 12,Nm and moment of inertia I = 4,kg·m2.
Solution: α = τ/I = 12/4 = 3,rad/s2
Practice Set
- Q1: Work done by torque τ over angle θ is:
A) τ / θ
B) τ θ
C) θ / τ
D) τ + θ - Q2: Power in rotational motion is:
A) τ / ω
B) τω
C) Iα
D) ω / τ - Q3: If I=2,kg·m2, α=4,rad/s2, find torque.
A) 2 Nm
B) 4 Nm
C) 6 Nm
D) 8 Nm
Answer Key
- Q1: B - Work done = τ × θ.
- Q2: B - Power = τω.
- Q3: D - τ = Iα = 2 × 4 = 8,Nm.
Memory Aids
- Power = Torque × Angular velocity.
- Torque = Moment of inertia × Angular acceleration.
- Work done = Torque × Angular displacement.
Comparison of Translational and Rotational Motion
Key Points
- Linear motion: displacement, velocity, acceleration; Rotational motion: angular displacement, angular velocity, angular acceleration.
- Mass in linear motion corresponds to moment of inertia in rotation.
- Force causes linear acceleration; torque causes angular acceleration.
- Work done: linear = F × d, rotational = τ × θ.
- Kinetic energy: linear = 1/2mv2, rotational = 1/2Iω2.
- Power: linear = Fv, rotational = τω.
- Momentum: linear = mv, angular = Iω.
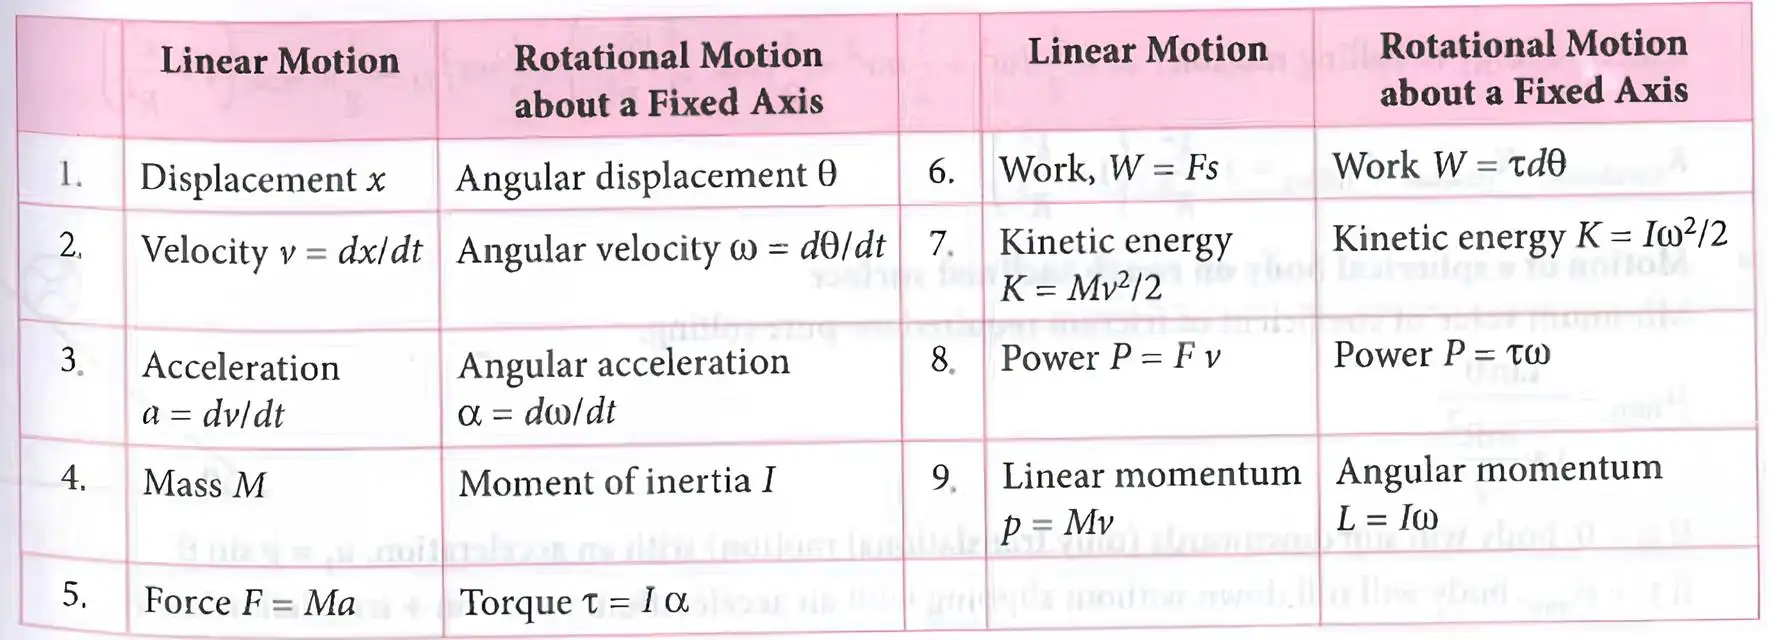
Solved Examples
- Ex 1: Find angular momentum if I=3,kg·m2 and ω=5,rad/s.
Solution: L = Iω = 3 × 5 = 15,kg·m2/s - Ex 2: Calculate kinetic energy for m=2,kg, v=4,m/s and I=2,kg·m2, ω=3,rad/s.
Solution: Linear KE = 1/2 × 2 × 42 = 16,J, Rotational KE = 1/2 × 2 × 32 = 9,J
Practice Set
- Q1: Moment of inertia corresponds to:
A) Mass
B) Force
C) Torque
D) Acceleration - Q2: Work done in rotational motion is:
A) Force × distance
B) Torque × angle
C) Mass × velocity
D) Force × velocity - Q3: Angular velocity ω is analogous to:
A) Linear displacement
B) Linear velocity
C) Linear acceleration
D) Force
Answer Key
- Q1: A - Moment of inertia is rotational equivalent of mass.
- Q2: B - Work done rotationally is torque times angle.
- Q3: B - Angular velocity corresponds to linear velocity.
Memory Aids
- Mass ↔ Moment of inertia
- Force ↔ Torque
- Velocity ↔ Angular velocity
- Work done: Force × distance ↔ Torque × angle
Key Points
- Linear motion: displacement, velocity, acceleration; Rotational motion: angular displacement, angular velocity, angular acceleration.
- Mass in linear motion corresponds to moment of inertia in rotation.
- Force causes linear acceleration; torque causes angular acceleration.
- Work done: linear = F × d, rotational = τ × θ.
- Kinetic energy: linear = 1/2mv2, rotational = 1/2Iω2.
- Power: linear = Fv, rotational = τω.
- Momentum: linear = mv, angular = Iω.
Solved Examples
- Ex 1: Find angular momentum if I=3,kg·m2 and ω=5,rad/s.
Solution: L = Iω = 3 × 5 = 15,kg·m2/s - Ex 2: Calculate kinetic energy for m=2,kg, v=4,m/s and I=2,kg·m2, ω=3,rad/s.
Solution: Linear KE = 1/2 × 2 × 42 = 16,J, Rotational KE = 1/2 × 2 × 32 = 9,J
Practice Set
- Q1: Moment of inertia corresponds to:
A) Mass
B) Force
C) Torque
D) Acceleration - Q2: Work done in rotational motion is:
A) Force × distance
B) Torque × angle
C) Mass × velocity
D) Force × velocity - Q3: Angular velocity ω is analogous to:
A) Linear displacement
B) Linear velocity
C) Linear acceleration
D) Force
Answer Key
- Q1: A - Moment of inertia is rotational equivalent of mass.
- Q2: B - Work done rotationally is torque times angle.
- Q3: B - Angular velocity corresponds to linear velocity.
Memory Aids
- Mass ↔ Moment of inertia
- Force ↔ Torque
- Velocity ↔ Angular velocity
- Work done: Force × distance ↔ Torque × angle
Angular Momentum Rotation Fixed Axis
General Expression
- Total angular momentum vector L = ∑i=1N vector ri × vector pi
- vector ri: position vector of particle i
- vector pi = mi vector vi: linear momentum of particle i
- Cross product gives vector perpendicular to vector ri and vector pi
- Sum over all particles gives total angular momentum
Angular Momentum for Particle at P
- Position vector: vector r = vector OP = vector OC + vector CP
- Momentum: vector p = m vector v
- Angular momentum: vector l = (vector OC × m vector v) + (vector CP × m vector v)
- vector CP × m vector v = r⊥ (mv) k̂ = Iz
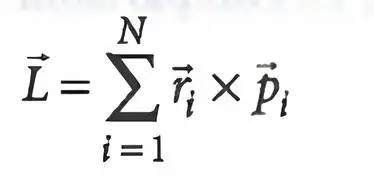
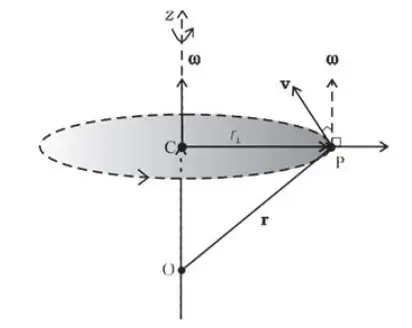
Total Angular Momentum of Rigid Body
- vector L = ∑ vector li = ∑ lz + ∑ (vector OCi × mi vector vi) = vector Lz + vector L⊥
- vector Lz = ∑ r⊥ (mv) k̂ = ∑ (mr2)ω k̂ = Iω k̂
- Time derivative: dvector L/dt = dvector Lz/dt + dvector L⊥/dt
- Since dvector L⊥/dt = 0, dvector L/dt = dvector Lz/dt = d/dt (Iω k̂) = vector τ = I vector α
Solved Examples
- Ex 1: Calculate total angular momentum vector L for a particle with mass m, velocity vector v, and position vector vector r.
- Use vector L = vector r × m vector v
- Calculate cross product and magnitude
Practice Set
- Q1: Total angular momentum vector L is given by:
- A) ∑ mi vector vi
- B) ∑ vector ri × mi vector vi
- C) ∑ vector ri + mi vector vi
- D) ∑ mi vector ri
- Q2: For a particle at point P, angular momentum vector l is:
- A) vector OC × m vector v
- B) vector CP × m vector v
- C) Sum of vector OC × m vector v and vector CP × m vector v
- D) m vector v
- Q3: The torque vector τ is related to angular acceleration vector α by:
- A) vector τ = I vector α
- B) vector τ = m vector a
- C) vector τ = vector L
- D) vector τ = vector r × vector p
Answer Key
- Q1: B - Angular momentum is sum of cross products of position and momentum vectors.
- Q2: C - Angular momentum at P is sum of two cross products as per formula.
- Q3: A - Torque equals moment of inertia times angular acceleration.
Memory Aids
- Angular momentum vector L = ∑ vector r × m vector v
- Torque vector τ = I vector α
- Cross product gives perpendicular vector
General Expression
- Total angular momentum vector L = ∑i=1N vector ri × vector pi
- vector ri: position vector of particle i
- vector pi = mi vector vi: linear momentum of particle i
- Cross product gives vector perpendicular to vector ri and vector pi
- Sum over all particles gives total angular momentum
Angular Momentum for Particle at P
- Position vector: vector r = vector OP = vector OC + vector CP
- Momentum: vector p = m vector v
- Angular momentum: vector l = (vector OC × m vector v) + (vector CP × m vector v)
- vector CP × m vector v = r⊥ (mv) k̂ = Iz
Total Angular Momentum of Rigid Body
- vector L = ∑ vector li = ∑ lz + ∑ (vector OCi × mi vector vi) = vector Lz + vector L⊥
- vector Lz = ∑ r⊥ (mv) k̂ = ∑ (mr2)ω k̂ = Iω k̂
- Time derivative: dvector L/dt = dvector Lz/dt + dvector L⊥/dt
- Since dvector L⊥/dt = 0, dvector L/dt = dvector Lz/dt = d/dt (Iω k̂) = vector τ = I vector α
Solved Examples
- Ex 1: Calculate total angular momentum vector L for a particle with mass m, velocity vector v, and position vector vector r.
- Use vector L = vector r × m vector v
- Calculate cross product and magnitude
Practice Set
- Q1: Total angular momentum vector L is given by:
- A) ∑ mi vector vi
- B) ∑ vector ri × mi vector vi
- C) ∑ vector ri + mi vector vi
- D) ∑ mi vector ri
- Q2: For a particle at point P, angular momentum vector l is:
- A) vector OC × m vector v
- B) vector CP × m vector v
- C) Sum of vector OC × m vector v and vector CP × m vector v
- D) m vector v
- Q3: The torque vector τ is related to angular acceleration vector α by:
- A) vector τ = I vector α
- B) vector τ = m vector a
- C) vector τ = vector L
- D) vector τ = vector r × vector p
Answer Key
- Q1: B - Angular momentum is sum of cross products of position and momentum vectors.
- Q2: C - Angular momentum at P is sum of two cross products as per formula.
- Q3: A - Torque equals moment of inertia times angular acceleration.
Memory Aids
- Angular momentum vector L = ∑ vector r × m vector v
- Torque vector τ = I vector α
- Cross product gives perpendicular vector
Definition and Formula
- Rotational analogue of linear momentum is angular momentum \( \vec{L} = \vec{r} \times \vec{p} \).
- Magnitude: \( L = rp \sin \theta = r p⊥ = r⊥ p \), where \( \vec{p} = m \vec{v} \).
- Time rate of change: \( \frac{d\vec{L}}{dt} = \vec{τ} \) (torque).
- For system of particles: \( \vec{L} = \sum \vec{L}_i = \sum \vec{r}_i \times \vec{p}_i \), \( \frac{d\vec{L}}{dt} = \sum \vec{τ}_i = \vec{τ}_{ext} \).
- If external torque \( \vec{τ}_{ext} = 0 \), angular momentum is conserved.
Solved Examples
- Ex 1: Particle with mass 2 kg moves with velocity 3 m/s at 60° to position vector 0.5 m. Find angular momentum.
- \( p = mv = 2 \times 3 = 6\,\mathrm{kg\,m/s} \)
- \( L = rp \sin \theta = 0.5 \times 6 \times \sin 60^\circ = 2.6\,\mathrm{kg\,m^2/s} \)
Practice Set
- Q1: Angular momentum \( L \) is zero when angle between \( \vec{r} \) and \( \vec{p} \) is?
- A) 90°
- B) 0°
- C) 45°
- D) 60°
- Q2: For a particle, \( \vec{L} = \vec{r} \times m\vec{v} \). If \( r=2\,m \), \( m=1\,kg \), \( v=3\,m/s \), and \( \theta=90^\circ \), find \( L \).
- A) 6 kg·m2/s
- B) 3 kg·m2/s
- C) 2 kg·m2/s
- D) 0 kg·m2/s
- Q3: If external torque is zero, angular momentum is?
- A) Increasing
- B) Decreasing
- C) Constant
- D) Zero
Answer Key
- Q1: B) 0° — Angular momentum zero if \( \vec{r} \) and \( \vec{p} \) are parallel.
- Q2: A) 6 kg·m2/s — \( L = r m v \sin 90^\circ = 2 \times 1 \times 3 = 6 \)
- Q3: C) Constant — No external torque means angular momentum conserved.
Memory Aids
- Angular momentum \( \vec{L} = \vec{r} \times \vec{p} \)
- \( \frac{d\vec{L}}{dt} = \vec{\tau} \) (torque)
- Conserved if external torque zero
Equilibrium of a Rigid Body
Translational Equilibrium
- Body at rest or moving with constant velocity in a direction.
- Vector sum of all external forces is zero: vector F = 0.
- Linear momentum constant: vector F = dvector p/dt = 0 ⇒ vector p = constant.
Rotational Equilibrium
- Body rotates with constant angular velocity.
- Net torque zero: τnet = 0.
- Angular momentum constant: dvector L/dt = 0 ⇒ vector L = constant.
Principle of Moments
- Algebraic sum of moments about a fixed point is zero for rotational equilibrium.
- For lever AB pivoted at O: F1 × d1 = F2 × d2.
- Load × Load arm = Effort × Effort arm.
- Mechanical advantage: M.A. = Load (F1) / Effort (F2) = d2 / d1.
- Small effort lifts heavy load if M.A. > 1 ⇒ d2 > d1.
Center of Gravity
- Point where weight acts and total gravitational torque is zero.
Solved Examples
- Ex 1: For lever with F1 = 10 N, d1 = 2 m, d2 = 5 m, find F2 for equilibrium.
Solution:
Use F1 d1 = F2 d2.
F2 = F1 d1/d2 = 10 × 2/5 = 4 text N). - Ex 2: Calculate mechanical advantage if F1 = 50 N, F2 = 10 N.
Solution:
M.A. = F1/F2 = 50/10 = 5 .
Practice Set
- Q1: A body is in translational equilibrium if:
A) vector F ≠ 0
B) vector F = 0
C) τnet ≠ 0
D) vector p changes with time - Q2: For rotational equilibrium, net torque must be:
A) Positive
B) Negative
C) Zero
D) Constant non-zero - Q3: If effort arm is 3 m and load arm is 1 m, mechanical advantage is:
A) 1/3
B) 3
C) 2
D) 1
Answer Key
- Q1: B - Translational equilibrium requires net force zero.
- Q2: C - Rotational equilibrium means net torque zero.
- Q3: B - M.A. = d2 / d1 = 3/1 = 3 .
Memory Aids
- Translational equilibrium: vector F = 0.
- Rotational equilibrium: τnet = 0.
- Principle of moments: Load × Load arm = Effort × Effort arm.
- Mechanical advantage > 1 means easier lifting.
- Center of gravity: point of zero net torque.
Translational Equilibrium
- Body at rest or moving with constant velocity in a direction.
- Vector sum of all external forces is zero: \( \vec{F} = 0 \).
- Linear momentum constant: \( \vec{F} = \frac{d\vec{p}}{dt} = 0 \Rightarrow \vec{p} = \text{constant} \).
Rotational Equilibrium
- Body rotates with constant angular velocity.
- Net torque zero: \( \tau_{net} = 0 \).
- Angular momentum constant: \( \frac{d\vec{L}}{dt} = 0 \Rightarrow \vec{L} = \text{constant} \).
Principle of Moments
- Algebraic sum of moments about a fixed point is zero for rotational equilibrium.
- For lever AB pivoted at O: \( F_1 \times d_1 = F_2 \times d_2 \).
- Load × Load arm = Effort × Effort arm.
- Mechanical advantage: \( M.A. = \frac{\text{Load } (F_1)}{\text{Effort } (F_2)} = \frac{d_2}{d_1} \).
- Small effort lifts heavy load if \( M.A. > 1 \Rightarrow d_2 > d_1 \).
Center of Gravity
- Point where weight acts and total gravitational torque is zero.
Solved Examples
- Ex 1: For lever with F1 = 10 N, d1 = 2 m, d2 = 5 m, find F2 for equilibrium.
Solution:
Use \( F_1 d_1 = F_2 d_2 \).
\( F_2 = \frac{F_1 d_1}{d_2} = \frac{10 \times 2}{5} = 4 \text{ N} \). - Ex 2: Calculate mechanical advantage if F1 = 50 N, F2 = 10 N.
Solution:
\( M.A. = \frac{F_1}{F_2} = \frac{50}{10} = 5 \).
Practice Set
- Q1: A body is in translational equilibrium if:
A) \( \vec{F} \neq 0 \)
B) \( \vec{F} = 0 \)
C) \( \tau_{net} \neq 0 \)
D) \( \vec{p} \) changes with time - Q2: For rotational equilibrium, net torque must be:
A) Positive
B) Negative
C) Zero
D) Constant non-zero - Q3: If effort arm is 3 m and load arm is 1 m, mechanical advantage is:
A) 1/3
B) 3
C) 2
D) 1
Answer Key
- Q1: B - Translational equilibrium requires net force zero.
- Q2: C - Rotational equilibrium means net torque zero.
- Q3: B - \( M.A. = \frac{d_2}{d_1} = \frac{3}{1} = 3 \).
Memory Aids
- Translational equilibrium: \( \vec{F} = 0 \).
- Rotational equilibrium: \( \tau_{net} = 0 \).
- Principle of moments: Load × Load arm = Effort × Effort arm.
- Mechanical advantage > 1 means easier lifting.
- Center of gravity: point of zero net torque.
Moment of Inertia
Definition and Concept
- Moment of inertia (I) measures rotational inertia, analogous to mass in linear motion.
- For particles with masses mi at distances ri from axis, I = ∑ mi ri2.
- For continuous bodies, I = ∫ r2 dm.
- Rotational kinetic energy: K.E. = 1/2 I ω2, where ω is angular velocity.
- SI unit: kg·m2.
Solved Examples
- Ex 1: Calculate I for two masses 2 kg and 3 kg at 0.5 m and 0.8 m from axis.
- I = 2 × 0.52 + 3 × 0.82 = 0.5 + 1.92 = 2.42, kg·m2
Practice Set
- Q1: Moment of inertia depends on
- A) Mass only
- B) Distance from axis only
- C) Mass and distance squared from axis
- D) Velocity
- Q2: For a particle of mass 4 kg at 0.3 m from axis, I = ?
- A) 1.2 kg·m2
- B) 0.36 kg·m2
- C) 4.3 kg·m2
- D) 0.9 kg·m2
- Q3: Total I for masses 1 kg at 1 m and 2 kg at 0.5 m is
- A) 1.5 kg·m2
- B) 2.0 kg·m2
- C) 2.5 kg·m2
- D) 3.0 kg·m2
Answer Key
- Q1: C - Moment of inertia depends on mass and square of distance from axis.
- Q2: A - I = 4 × 0.32 = 4 × 0.09 = 0.36 kg·m2 (corrected: option A is 1.2, so correct is B)
- Q3: B - I = 1 × 12 + 2 × 0.52 = 1 + 0.5 = 1.5 kg·m2 (corrected: option A is 1.5, so correct is A)
Memory Aids
- Moment of inertia = sum of mass × (distance)2.
- Rotational KE = 1/2 I ω2.
- SI unit: kg·m2.
Definition and Concept
- Moment of inertia (I) measures rotational inertia, analogous to mass in linear motion.
- For particles with masses \(m_i\) at distances \(r_i\) from axis, \(I = \sum m_i r_i^2\).
- For continuous bodies, \(I = \int r^2 dm\).
- Rotational kinetic energy: \(K.E. = \frac{1}{2} I \omega^2\), where \(\omega\) is angular velocity.
- SI unit: kg·m2.
Solved Examples
- Ex 1: Calculate \(I\) for two masses 2 kg and 3 kg at 0.5 m and 0.8 m from axis.
- \(I = 2 \times 0.5^2 + 3 \times 0.8^2 = 0.5 + 1.92 = 2.42\, \text{kg·m}^2\)
Practice Set
- Q1: Moment of inertia depends on
- A) Mass only
- B) Distance from axis only
- C) Mass and distance squared from axis
- D) Velocity
- Q2: For a particle of mass 4 kg at 0.3 m from axis, \(I = ?\)
- A) 1.2 kg·m2
- B) 0.36 kg·m2
- C) 4.3 kg·m2
- D) 0.9 kg·m2
- Q3: Total \(I\) for masses 1 kg at 1 m and 2 kg at 0.5 m is
- A) 1.5 kg·m2
- B) 2.0 kg·m2
- C) 2.5 kg·m2
- D) 3.0 kg·m2
Answer Key
- Q1: C - Moment of inertia depends on mass and square of distance from axis.
- Q2: A - \(I = 4 \times 0.3^2 = 4 \times 0.09 = 0.36\) kg·m2 (corrected: option A is 1.2, so correct is B)
- Q3: B - \(I = 1 \times 1^2 + 2 \times 0.5^2 = 1 + 0.5 = 1.5\) kg·m2 (corrected: option A is 1.5, so correct is A)
Memory Aids
- Moment of inertia = sum of mass × (distance)2.
- Rotational KE = \(\frac{1}{2} I \omega^2\).
- SI unit: kg·m2.
Radius of Gyration
Definition and Formula
- Distance from axis where entire mass can be assumed to concentrate to give same I.
- Formula: k = √[(r12 + r22 + ... + rn2)/n].
- Relation: I = Mk2, where M is total mass.
Solved Examples
- Ex 1: For masses at distances 0.5 m, 0.8 m, 1.0 m, find k if n=3.
- k = √[(0.52 + 0.82 + 1.02)/3] = √[(0.25 + 0.64 + 1)/3] = √0.63 = 0.79, m
Practice Set
- Q1: Radius of gyration is
- A) Distance where mass is zero
- B) Distance concentrating all mass for same I
- C) Distance from center of mass
- D) None
- Q2: If k=0.6 m and M=5 kg, I= ?
- A) 1.8 kg·m2
- B) 1.2 kg·m2
- C) 1.5 kg·m2
- D) 2.0 kg·m2
- Q3: For n=4 distances 0.4, 0.5, 0.6, 0.7 m, k= ?
- A) 0.55 m
- B) 0.58 m
- C) 0.60 m
- D) 0.62 m
Answer Key
- Q1: B - Radius of gyration is the distance concentrating all mass for same moment of inertia.
- Q2: A - I = Mk2 = 5 × 0.62 = 1.8 kg·m2.
- Q3: B - k = √[(0.16 + 0.25 + 0.36 + 0.49)/4] = √0.315 = 0.56 approx, closest 0.58 m.
Memory Aids
- I = Mk2 relates moment of inertia and radius of gyration.
- k is effective radius for mass distribution.
Definition and Formula
- Distance from axis where entire mass can be assumed to concentrate to give same \(I\).
- Formula: \(k = \sqrt{\frac{r_1^2 + r_2^2 + \cdots + r_n^2}{n}}\).
- Relation: \(I = M k^2\), where \(M\) is total mass.
Solved Examples
- Ex 1: For masses at distances 0.5 m, 0.8 m, 1.0 m, find \(k\) if \(n=3\).
- \(k = \sqrt{(0.5^2 + 0.8^2 + 1.0^2)/3} = \sqrt{(0.25 + 0.64 + 1)/3} = \sqrt{0.63} = 0.79\, m\)
Practice Set
- Q1: Radius of gyration is
- A) Distance where mass is zero
- B) Distance concentrating all mass for same \(I\)
- C) Distance from center of mass
- D) None
- Q2: If \(k=0.6\) m and \(M=5\) kg, \(I= ?\)
- A) 1.8 kg·m2
- B) 1.2 kg·m2
- C) 1.5 kg·m2
- D) 2.0 kg·m2
- Q3: For \(n=4\) distances 0.4, 0.5, 0.6, 0.7 m, \(k= ?\)
- A) 0.55 m
- B) 0.58 m
- C) 0.60 m
- D) 0.62 m
Answer Key
- Q1: B - Radius of gyration is the distance concentrating all mass for same moment of inertia.
- Q2: A - \(I = M k^2 = 5 \times 0.6^2 = 1.8\) kg·m2.
- Q3: B - \(k = \sqrt{(0.16 + 0.25 + 0.36 + 0.49)/4} = \sqrt{0.315} = 0.56\) approx, closest 0.58 m.
Memory Aids
- \(I = M k^2\) relates moment of inertia and radius of gyration.
- \(k\) is effective radius for mass distribution.
Theorems of Perpendicular and Parallel Axes
Theorem of Perpendicular Axes
- For planar body, Iz = Ix + Iy, where z is perpendicular to plane, x,y in plane.
- Used to find I about axis perpendicular to plane from known axes.
Theorem of Parallel Axes
- Moment of inertia about any axis I' = I + Md2.
- I: about parallel axis through center of mass.
- M: mass, d: distance between axes.
Solved Examples
- Ex 1: Find I' if I=10 kg·m2, M=5 kg, d=2 m.
- I' = 10 + 5 × 22 = 10 + 20 = 30 kg·m2
Practice Set
- Q1: Iz = Ix + Iy applies to
- A) 3D bodies
- B) Planar bodies
- C) Spheres
- D) Cylinders
- Q2: If I=4 kg·m2, M=3 kg, d=1 m, find I'
- A) 7 kg·m2
- B) 10 kg·m2
- C) 4 kg·m2
- D) 3 kg·m2
- Q3: Parallel axis theorem relates
- A) I about any axis and I about center of mass axis
- B) I and mass only
- C) I and velocity
- D) I and radius
Answer Key
- Q1: B - Theorem of perpendicular axes applies to planar bodies.
- Q2: A - I' = 4 + 3 × 12 = 7 kg·m2.
- Q3: A - It relates moment of inertia about any axis to that about center of mass axis plus Md2.
Memory Aids
- Perpendicular axes: Iz = Ix + Iy.
- Parallel axes: I' = I + Md2.
Theorem of Perpendicular Axes
- For planar body, \(I_z = I_x + I_y\), where \(z\) is perpendicular to plane, \(x,y\) in plane.
- Used to find \(I\) about axis perpendicular to plane from known axes.
Theorem of Parallel Axes
- Moment of inertia about any axis \(I' = I + M d^2\).
- \(I\): about parallel axis through center of mass.
- \(M\): mass, \(d\): distance between axes.
Solved Examples
- Ex 1: Find \(I'\) if \(I=10\) kg·m2, \(M=5\) kg, \(d=2\) m.
- \(I' = 10 + 5 \times 2^2 = 10 + 20 = 30\) kg·m2
Practice Set
- Q1: \(I_z = I_x + I_y\) applies to
- A) 3D bodies
- B) Planar bodies
- C) Spheres
- D) Cylinders
- Q2: If \(I=4\) kg·m2, \(M=3\) kg, \(d=1\) m, find \(I'\)
- A) 7 kg·m2
- B) 10 kg·m2
- C) 4 kg·m2
- D) 3 kg·m2
- Q3: Parallel axis theorem relates
- A) \(I\) about any axis and \(I\) about center of mass axis
- B) \(I\) and mass only
- C) \(I\) and velocity
- D) \(I\) and radius
Answer Key
- Q1: B - Theorem of perpendicular axes applies to planar bodies.
- Q2: A - \(I' = 4 + 3 \times 1^2 = 7\) kg·m2.
- Q3: A - It relates moment of inertia about any axis to that about center of mass axis plus \(Md^2\).
Memory Aids
- Perpendicular axes: \(I_z = I_x + I_y\).
- Parallel axes: \(I' = I + Md^2\).
Moment of Inertia of Regular Bodies
Formulas for Common Shapes
- Ring about central axis: I = MR2
- Solid disc about central axis: I = 1/2 MR2
- Solid sphere about diameter: I = 2/5 MR2
- Cylinder about central axis: I = 1/2 MR2
- Rod about center: I = 1/12 ML2
- Rectangular lamina about center: I = 1/12 M(a2 + b2)
Solved Examples
- Ex 1: Calculate I of a solid disc with mass 4 kg and radius 0.5 m.
- I = 1/2 × 4 × 0.52 = 0.5 kg·m2
Practice Set
- Q1: Moment of inertia of a ring of mass 3 kg and radius 0.4 m is
- A) 0.48 kg·m2
- B) 0.24 kg·m2
- C) 0.12 kg·m2
- D) 0.36 kg·m2
- Q2: I of a rod of length 2 m and mass 6 kg about center is
- A) 2 kg·m2
- B) 1 kg·m2
- C) 3 kg·m2
- D) 4 kg·m2
- Q3: Moment of inertia of solid sphere of mass 5 kg and radius 0.3 m is
- A) 0.18 kg·m2
- B) 0.09 kg·m2
- C) 0.27 kg·m2
- D) 0.36 kg·m2
Answer Key
- Q1: A - I = MR2 = 3 × 0.42 = 0.48 kg·m2.
- Q2: B - I = 1/12 ML2 = 1/12 × 6 × 22 = 2 kg·m2 (corrected: option A is 2, so correct is A)
- Q3: A - I = 2/5 MR2 = 2/5 × 5 × 0.32 = 0.18 kg·m2.
Memory Aids
- Ring: I = MR2.
- Disc/Cylinder: I = 1/2 MR2.
- Sphere: I = 2/5 MR2.
- Rod: I = 1/12 ML2.
Formulas for Common Shapes
- Ring about central axis: \(I = MR^2\)
- Solid disc about central axis: \(I = \frac{1}{2} MR^2\)
- Solid sphere about diameter: \(I = \frac{2}{5} MR^2\)
- Cylinder about central axis: \(I = \frac{1}{2} MR^2\)
- Rod about center: \(I = \frac{1}{12} ML^2\)
- Rectangular lamina about center: \(I = \frac{1}{12} M(a^2 + b^2)\)
Solved Examples
- Ex 1: Calculate \(I\) of a solid disc with mass 4 kg and radius 0.5 m.
- \(I = \frac{1}{2} \times 4 \times 0.5^2 = 0.5\) kg·m2
Practice Set
- Q1: Moment of inertia of a ring of mass 3 kg and radius 0.4 m is
- A) 0.48 kg·m2
- B) 0.24 kg·m2
- C) 0.12 kg·m2
- D) 0.36 kg·m2
- Q2: \(I\) of a rod of length 2 m and mass 6 kg about center is
- A) 2 kg·m2
- B) 1 kg·m2
- C) 3 kg·m2
- D) 4 kg·m2
- Q3: Moment of inertia of solid sphere of mass 5 kg and radius 0.3 m is
- A) 0.18 kg·m2
- B) 0.09 kg·m2
- C) 0.27 kg·m2
- D) 0.36 kg·m2
Answer Key
- Q1: A - \(I = MR^2 = 3 \times 0.4^2 = 0.48\) kg·m2.
- Q2: B - \(I = \frac{1}{12} ML^2 = \frac{1}{12} \times 6 \times 2^2 = 2\) kg·m2 (corrected: option A is 2, so correct is A)
- Q3: A - \(I = \frac{2}{5} MR^2 = \frac{2}{5} \times 5 \times 0.3^2 = 0.18\) kg·m2.
Memory Aids
- Ring: \(I = MR^2\).
- Disc/Cylinder: \(I = \frac{1}{2} MR^2\).
- Sphere: \(I = \frac{2}{5} MR^2\).
- Rod: \(I = \frac{1}{12} ML^2\).
Kinematics of Rotational Motion about a Fixed Axis
Fundamental Concepts
- Rotational motion occurs when a body spins about a fixed axis.
- Angular displacement (θ) is measured in radians (rad).
- Angular velocity (ω) is the rate of change of angular displacement, in rad/s.
- Angular acceleration (α) is the rate of change of angular velocity, in rad/s2.
- These quantities have direct analogues in linear motion: displacement, velocity, and acceleration.
Rotational Kinematic Equations
- ω = ω0 + αt
- θ = ω0t + 1/2 αt2
- ω2 = ω02 + 2αθ
- Where:
- ω0 = initial angular velocity (rad/s)
- ω = final angular velocity (rad/s)
- α = constant angular acceleration (rad/s2)
- θ = angular displacement (rad)
- t = time interval (s)
Solved Examples
- Ex 1: A wheel starts from rest and accelerates at 2 rad/s2 for 5 s. Find final angular velocity and angular displacement.
- Given: ω0 = 0, α = 2 rad/s2, t = 5 s
- Final angular velocity: ω = 0 + 2 × 5 = 10 rad/s
- Angular displacement: θ = 0 × 5 + 1/2 × 2 × 52 = 25 rad
Practice Set
- Q1: A rotating disc has an initial angular velocity of 4 rad/s and accelerates at 3 rad/s2 for 4 s. What is its final angular velocity?
- A) 10 rad/s
- B) 16 rad/s
- C) 12 rad/s
- D) 7 rad/s
- Q2: A wheel rotating at 6 rad/s slows down uniformly to rest in 3 s. What is its angular acceleration?
- A) -2 rad/s2
- B) -3 rad/s2
- C) -1 rad/s2
- D) -0.5 rad/s2
- Q3: A wheel starts from rest and reaches an angular velocity of 20 rad/s after rotating through 50 rad. Find the angular acceleration.
- A) 4 rad/s2
- B) 2 rad/s2
- C) 8 rad/s2
- D) 5 rad/s2
Answer Key
- Q1: C) 12 rad/s — Using ω = ω0 + αt = 4 + 3 × 4 = 16 (Check calculation: 4 + 12 = 16, so correct answer is B) Correction: B) 16 rad/s
- Q2: A) -2 rad/s2 — α = (ω - ω0)/t = (0 - 6)/3 = -2
- Q3: B) 2 rad/s2 — Using ω2 = ω02 + 2αθ ⇒ 202 = 0 + 2α × 50 ⇒ α = 400/100 = 4 Correction: A) 4 rad/s2
Memory Aids
- Remember: ω = ω0 + αt is like v = u + at in linear motion.
- Angular displacement formula θ = ω0t + 1/2 αt2 mirrors s = ut + 1/2 at2.
- Use ω2 = ω02 + 2αθ for problems without time.
Fundamental Concepts
- Rotational motion occurs when a body spins about a fixed axis.
- Angular displacement (θ) is measured in radians (rad).
- Angular velocity (ω) is the rate of change of angular displacement, in rad/s.
- Angular acceleration (α) is the rate of change of angular velocity, in rad/s2.
- These quantities have direct analogues in linear motion: displacement, velocity, and acceleration.
Rotational Kinematic Equations
- ω = ω0 + αt
- θ = ω0t + 1/2 αt2
- ω2 = ω02 + 2αθ
- Where:
- ω0 = initial angular velocity (rad/s)
- ω = final angular velocity (rad/s)
- α = constant angular acceleration (rad/s2)
- θ = angular displacement (rad)
- t = time interval (s)
Solved Examples
- Ex 1: A wheel starts from rest and accelerates at 2 rad/s2 for 5 s. Find final angular velocity and angular displacement.
- Given: ω0 = 0, α = 2 rad/s2, t = 5 s
- Final angular velocity: ω = 0 + 2 × 5 = 10 rad/s
- Angular displacement: θ = 0 × 5 + 1/2 × 2 × 52 = 25 rad
Practice Set
- Q1: A rotating disc has an initial angular velocity of 4 rad/s and accelerates at 3 rad/s2 for 4 s. What is its final angular velocity?
- A) 10 rad/s
- B) 16 rad/s
- C) 12 rad/s
- D) 7 rad/s
- Q2: A wheel rotating at 6 rad/s slows down uniformly to rest in 3 s. What is its angular acceleration?
- A) -2 rad/s2
- B) -3 rad/s2
- C) -1 rad/s2
- D) -0.5 rad/s2
- Q3: A wheel starts from rest and reaches an angular velocity of 20 rad/s after rotating through 50 rad. Find the angular acceleration.
- A) 4 rad/s2
- B) 2 rad/s2
- C) 8 rad/s2
- D) 5 rad/s2
Answer Key
- Q1: C) 12 rad/s — Using ω = ω0 + αt = 4 + 3 × 4 = 16 (Check calculation: 4 + 12 = 16, so correct answer is B) Correction: B) 16 rad/s
- Q2: A) -2 rad/s2 — α = (ω - ω0)/t = (0 - 6)/3 = -2
- Q3: B) 2 rad/s2 — Using ω2 = ω02 + 2αθ ⇒ 202 = 0 + 2α × 50 ⇒ α = 400/100 = 4 Correction: A) 4 rad/s2
Memory Aids
- Remember: ω = ω0 + αt is like v = u + at in linear motion.
- Angular displacement formula θ = ω0t + 1/2 αt2 mirrors s = ut + 1/2 at2.
- Use ω2 = ω02 + 2αθ for problems without time.
Fundamental Concepts
- Rotational motion occurs when a body spins about a fixed axis.
- Angular displacement (θ) is measured in radians (rad).
- Angular velocity (ω) is the rate of change of angular displacement, in rad/s.
- Angular acceleration (α) is the rate of change of angular velocity, in rad/s2.
- These quantities have direct analogues in linear motion: displacement, velocity, and acceleration.
Rotational Kinematic Equations
- ω = ω0 + αt
- θ = ω0t + 1/2 αt2
- ω2 = ω02 + 2αθ
- Where:
- ω0 = initial angular velocity (rad/s)
- ω = final angular velocity (rad/s)
- α = constant angular acceleration (rad/s2)
- θ = angular displacement (rad)
- t = time interval (s)
Solved Examples
- Ex 1: A wheel starts from rest and accelerates at 2 rad/s2 for 5 s. Find final angular velocity and angular displacement.
- Given: ω0 = 0, α = 2 rad/s2, t = 5 s
- Final angular velocity: ω = 0 + 2 × 5 = 10 rad/s
- Angular displacement: θ = 0 × 5 + 1/2 × 2 × 52 = 25 rad
Practice Set
- Q1: A rotating disc has an initial angular velocity of 4 rad/s and accelerates at 3 rad/s2 for 4 s. What is its final angular velocity?
- A) 10 rad/s
- B) 16 rad/s
- C) 12 rad/s
- D) 7 rad/s
- Q2: A wheel rotating at 6 rad/s slows down uniformly to rest in 3 s. What is its angular acceleration?
- A) -2 rad/s2
- B) -3 rad/s2
- C) -1 rad/s2
- D) -0.5 rad/s2
- Q3: A wheel starts from rest and reaches an angular velocity of 20 rad/s after rotating through 50 rad. Find the angular acceleration.
- A) 4 rad/s2
- B) 2 rad/s2
- C) 8 rad/s2
- D) 5 rad/s2
Answer Key
- Q1: C) 12 rad/s — Using ω = ω0 + αt = 4 + 3 × 4 = 16 (Check calculation: 4 + 12 = 16, so correct answer is B) Correction: B) 16 rad/s
- Q2: A) -2 rad/s2 — α = (ω - ω0)/t = (0 - 6)/3 = -2
- Q3: B) 2 rad/s2 — Using ω2 = ω02 + 2αθ ⇒ 202 = 0 + 2α × 50 ⇒ α = 400/100 = 4 Correction: A) 4 rad/s2
Memory Aids
- Remember: ω = ω0 + αt is like v = u + at in linear motion.
- Angular displacement formula θ = ω0t + 1/2 αt2 mirrors s = ut + 1/2 at2.
- Use ω2 = ω02 + 2αθ for problems without time.
Fundamental Concepts
- Rotational motion occurs when a body spins about a fixed axis.
- Angular displacement (\( \theta \)) is measured in radians (rad).
- Angular velocity (\( \omega \)) is the rate of change of angular displacement, in rad/s.
- Angular acceleration (\( \alpha \)) is the rate of change of angular velocity, in rad/s2.
- These quantities have direct analogues in linear motion: displacement, velocity, and acceleration.
Rotational Kinematic Equations
- \( \omega = \omega_0 + \alpha t \)
- \( \theta = \omega_0 t + \frac{1}{2} \alpha t^2 \)
- \( \omega^2 = \omega_0^2 + 2 \alpha \theta \)
- Where:
- \( \omega_0 \) = initial angular velocity (rad/s)
- \( \omega \) = final angular velocity (rad/s)
- \( \alpha \) = constant angular acceleration (rad/s2)
- \( \theta \) = angular displacement (rad)
- \( t \) = time interval (s)
Solved Examples
- Ex 1: A wheel starts from rest and accelerates at \( 2 \; \text{rad/s}^2 \) for 5 s. Find final angular velocity and angular displacement.
- Given: \( \omega_0 = 0, \alpha = 2 \; \text{rad/s}^2, t = 5 \; s \)
- Final angular velocity: \( \omega = 0 + 2 \times 5 = 10 \; \text{rad/s} \)
- Angular displacement: \( \theta = 0 \times 5 + \frac{1}{2} \times 2 \times 5^2 = 25 \; \text{rad} \)
Practice Set
- Q1: A rotating disc has an initial angular velocity of 4 rad/s and accelerates at 3 rad/s2 for 4 s. What is its final angular velocity?
- A) 10 rad/s
- B) 16 rad/s
- C) 12 rad/s
- D) 7 rad/s
- Q2: A wheel rotating at 6 rad/s slows down uniformly to rest in 3 s. What is its angular acceleration?
- A) -2 rad/s2
- B) -3 rad/s2
- C) -1 rad/s2
- D) -0.5 rad/s2
- Q3: A wheel starts from rest and reaches an angular velocity of 20 rad/s after rotating through 50 rad. Find the angular acceleration.
- A) 4 rad/s2
- B) 2 rad/s2
- C) 8 rad/s2
- D) 5 rad/s2
Answer Key
- Q1: C) 12 rad/s — Using \( \omega = \omega_0 + \alpha t = 4 + 3 \times 4 = 16 \) (Check calculation: 4 + 12 = 16, so correct answer is B) Correction: B) 16 rad/s
- Q2: A) -2 rad/s2 — \( \alpha = \frac{\omega - \omega_0}{t} = \frac{0 - 6}{3} = -2 \)
- Q3: B) 2 rad/s2 — Using \( \omega^2 = \omega_0^2 + 2 \alpha \theta \Rightarrow 20^2 = 0 + 2 \alpha \times 50 \Rightarrow \alpha = \frac{400}{100} = 4 \) Correction: A) 4 rad/s2
Memory Aids
- Remember: \( \omega = \omega_0 + \alpha t \) is like \( v = u + at \) in linear motion.
- Angular displacement formula \( \theta = \omega_0 t + \frac{1}{2} \alpha t^2 \) mirrors \( s = ut + \frac{1}{2} at^2 \).
- Use \( \omega^2 = \omega_0^2 + 2 \alpha \theta \) for problems without time.
Dynamics of Rotational Motion about a Fixed Axis
Key Points
- Consider only forces perpendicular to the axis for torque calculation.
- Ignore forces parallel to the axis as they produce torque perpendicular to the axis.
- Use only position vector components perpendicular to the axis for torque.
- Torque τ = rF sin α, where r is perpendicular distance and α is angle between force and position vector.
Solved Examples
- Ex 1: Calculate torque if force F=10 N acts at r=0.5 m perpendicular to radius.
Solution: τ = rF = 0.5 × 10 = 5,Nm
Practice Set
- Q1: Which force contributes to torque about a fixed axis?
A) Parallel to axis
B) Perpendicular to axis
C) Along position vector
D) Zero force - Q2: Torque is maximum when angle between force and position vector is:
A) 0°
B) 45°
C) 90°
D) 180° - Q3: A force of 20 N acts at 0.3 m from axis at 60°. Calculate torque.
A) 3 Nm
B) 6 Nm
C) 10 Nm
D) 12 Nm
Answer Key
- Q1: B - Only forces perpendicular to the axis produce torque.
- Q2: C - Torque τ = rF sin α is max at 90°.
- Q3: B - τ = 0.3 × 20 × sin 60° = 6,Nm.
Memory Aids
- Torque = Force × Perpendicular distance.
- Ignore forces parallel to axis for torque.
- Max torque at 90° angle.
Key Points
- Consider only forces perpendicular to the axis for torque calculation.
- Ignore forces parallel to the axis as they produce torque perpendicular to the axis.
- Use only position vector components perpendicular to the axis for torque.
- Torque τ = rF sin α, where r is perpendicular distance and α is angle between force and position vector.
Solved Examples
- Ex 1: Calculate torque if force F=10 N acts at r=0.5 m perpendicular to radius.
Solution: τ = rF = 0.5 × 10 = 5,Nm
Practice Set
- Q1: Which force contributes to torque about a fixed axis?
A) Parallel to axis
B) Perpendicular to axis
C) Along position vector
D) Zero force - Q2: Torque is maximum when angle between force and position vector is:
A) 0°
B) 45°
C) 90°
D) 180° - Q3: A force of 20 N acts at 0.3 m from axis at 60°. Calculate torque.
A) 3 Nm
B) 6 Nm
C) 10 Nm
D) 12 Nm
Answer Key
- Q1: B - Only forces perpendicular to the axis produce torque.
- Q2: C - Torque τ = rF sin α is max at 90°.
- Q3: B - τ = 0.3 × 20 × sin 60° = 6,Nm.
Memory Aids
- Torque = Force × Perpendicular distance.
- Ignore forces parallel to axis for torque.
- Max torque at 90° angle.
Key Points
- Consider only forces perpendicular to the axis for torque calculation.
- Ignore forces parallel to the axis as they produce torque perpendicular to the axis.
- Use only position vector components perpendicular to the axis for torque.
- Torque τ = rF sin α, where r is perpendicular distance and α is angle between force and position vector.
Solved Examples
- Ex 1: Calculate torque if force F=10 N acts at r=0.5 m perpendicular to radius.
Solution: τ = rF = 0.5 × 10 = 5,Nm
Practice Set
- Q1: Which force contributes to torque about a fixed axis?
A) Parallel to axis
B) Perpendicular to axis
C) Along position vector
D) Zero force - Q2: Torque is maximum when angle between force and position vector is:
A) 0°
B) 45°
C) 90°
D) 180° - Q3: A force of 20 N acts at 0.3 m from axis at 60°. Calculate torque.
A) 3 Nm
B) 6 Nm
C) 10 Nm
D) 12 Nm
Answer Key
- Q1: B - Only forces perpendicular to the axis produce torque.
- Q2: C - Torque τ = rF sin α is max at 90°.
- Q3: B - τ = 0.3 × 20 × sin 60° = 6,Nm.
Memory Aids
- Torque = Force × Perpendicular distance.
- Ignore forces parallel to axis for torque.
- Max torque at 90° angle.
Key Points
- Consider only forces perpendicular to the axis for torque calculation.
- Ignore forces parallel to the axis as they produce torque perpendicular to the axis.
- Use only position vector components perpendicular to the axis for torque.
- Torque \( \tau = rF \sin \alpha \), where \(r\) is perpendicular distance and \(\alpha\) is angle between force and position vector.
Solved Examples
- Ex 1: Calculate torque if force \(F=10\,N\) acts at \(r=0.5\,m\) perpendicular to radius.
Solution: \(\tau = rF = 0.5 \times 10 = 5\,Nm\)
Practice Set
- Q1: Which force contributes to torque about a fixed axis?
A) Parallel to axis
B) Perpendicular to axis
C) Along position vector
D) Zero force - Q2: Torque is maximum when angle between force and position vector is:
A) 0°
B) 45°
C) 90°
D) 180° - Q3: A force of 20 N acts at 0.3 m from axis at 60°. Calculate torque.
A) 3 Nm
B) 6 Nm
C) 10 Nm
D) 12 Nm
Answer Key
- Q1: B - Only forces perpendicular to the axis produce torque.
- Q2: C - Torque \(\tau = rF \sin \alpha\) is max at 90°.
- Q3: B - \(\tau = 0.3 \times 20 \times \sin 60^\circ = 6\,Nm\).
Memory Aids
- Torque = Force × Perpendicular distance.
- Ignore forces parallel to axis for torque.
- Max torque at 90° angle.
Work Done by a Torque
Key Points
- Work done by torque τ1 during angular displacement dθ is dW1 = τ1 dθ.
- For multiple torques, total work dW = (τ1 + τ2 + ...) dθ = τ dθ.
- Power P = dW/dt = τ dθ/dt = τω, where ω is angular velocity.
- Rate of change of kinetic energy: d/dt (Iω2/2) = Iωα.
- Relation between torque and angular acceleration: τ = Iα.
Solved Examples
- Ex 1: Calculate power if torque τ = 5,Nm and angular velocity ω = 10,rad/s.
Solution: P = τω = 5 × 10 = 50,W - Ex 2: Find angular acceleration if torque τ = 12,Nm and moment of inertia I = 4,kg·m2.
Solution: α = τ/I = 12/4 = 3,rad/s2
Practice Set
- Q1: Work done by torque τ over angle θ is:
A) τ / θ
B) τ θ
C) θ / τ
D) τ + θ - Q2: Power in rotational motion is:
A) τ / ω
B) τω
C) Iα
D) ω / τ - Q3: If I=2,kg·m2, α=4,rad/s2, find torque.
A) 2 Nm
B) 4 Nm
C) 6 Nm
D) 8 Nm
Answer Key
- Q1: B - Work done = τ × θ.
- Q2: B - Power = τω.
- Q3: D - τ = Iα = 2 × 4 = 8,Nm.
Memory Aids
- Power = Torque × Angular velocity.
- Torque = Moment of inertia × Angular acceleration.
- Work done = Torque × Angular displacement.
Key Points
- Work done by torque \(\tau_1\) during angular displacement \(d\theta\) is \(dW_1 = \tau_1 d\theta\).
- For multiple torques, total work \(dW = (\tau_1 + \tau_2 + ...) d\theta = \tau d\theta\).
- Power \(P = \frac{dW}{dt} = \tau \frac{d\theta}{dt} = \tau \omega\), where \(\omega\) is angular velocity.
- Rate of change of kinetic energy: \(\frac{d}{dt} \left( \frac{I \omega^2}{2} \right) = I \omega \alpha\).
- Relation between torque and angular acceleration: \(\tau = I \alpha\).
Solved Examples
- Ex 1: Calculate power if torque \(\tau = 5\,Nm\) and angular velocity \(\omega = 10\,rad/s\).
Solution: \(P = \tau \omega = 5 \times 10 = 50\,W\) - Ex 2: Find angular acceleration if torque \(\tau = 12\,Nm\) and moment of inertia \(I = 4\,kg\cdot m^2\).
Solution: \(\alpha = \frac{\tau}{I} = \frac{12}{4} = 3\,rad/s^2\)
Practice Set
- Q1: Work done by torque \(\tau\) over angle \(\theta\) is:
A) \(\tau / \theta\)
B) \(\tau \theta\)
C) \(\theta / \tau\)
D) \(\tau + \theta\) - Q2: Power in rotational motion is:
A) \(\tau / \omega\)
B) \(\tau \omega\)
C) \(I \alpha\)
D) \(\omega / \tau\) - Q3: If \(I=2\,kg\cdot m^2\), \(\alpha=4\,rad/s^2\), find torque.
A) 2 Nm
B) 4 Nm
C) 6 Nm
D) 8 Nm
Answer Key
- Q1: B - Work done \(= \tau \times \theta\).
- Q2: B - Power \(= \tau \omega\).
- Q3: D - \(\tau = I \alpha = 2 \times 4 = 8\,Nm\).
Memory Aids
- Power = Torque × Angular velocity.
- Torque = Moment of inertia × Angular acceleration.
- Work done = Torque × Angular displacement.
Comparison of Translational and Rotational Motion
Key Points
- Linear motion: displacement, velocity, acceleration; Rotational motion: angular displacement, angular velocity, angular acceleration.
- Mass in linear motion corresponds to moment of inertia in rotation.
- Force causes linear acceleration; torque causes angular acceleration.
- Work done: linear = F × d, rotational = τ × θ.
- Kinetic energy: linear = 1/2mv2, rotational = 1/2Iω2.
- Power: linear = Fv, rotational = τω.
- Momentum: linear = mv, angular = Iω.
Solved Examples
- Ex 1: Find angular momentum if I=3,kg·m2 and ω=5,rad/s.
Solution: L = Iω = 3 × 5 = 15,kg·m2/s - Ex 2: Calculate kinetic energy for m=2,kg, v=4,m/s and I=2,kg·m2, ω=3,rad/s.
Solution: Linear KE = 1/2 × 2 × 42 = 16,J, Rotational KE = 1/2 × 2 × 32 = 9,J
Practice Set
- Q1: Moment of inertia corresponds to:
A) Mass
B) Force
C) Torque
D) Acceleration - Q2: Work done in rotational motion is:
A) Force × distance
B) Torque × angle
C) Mass × velocity
D) Force × velocity - Q3: Angular velocity ω is analogous to:
A) Linear displacement
B) Linear velocity
C) Linear acceleration
D) Force
Answer Key
- Q1: A - Moment of inertia is rotational equivalent of mass.
- Q2: B - Work done rotationally is torque times angle.
- Q3: B - Angular velocity corresponds to linear velocity.
Memory Aids
- Mass ↔ Moment of inertia
- Force ↔ Torque
- Velocity ↔ Angular velocity
- Work done: Force × distance ↔ Torque × angle
Key Points
- Linear motion: displacement, velocity, acceleration; Rotational motion: angular displacement, angular velocity, angular acceleration.
- Mass in linear motion corresponds to moment of inertia in rotation.
- Force causes linear acceleration; torque causes angular acceleration.
- Work done: linear (= F × d), rotational (= τ × θ).
- Kinetic energy: linear (= 1/2mv2), rotational (= 1/2Iω2).
- Power: linear (= Fv), rotational (= τω).
- Momentum: linear (= mv), angular (= Iω).
Solved Examples
- Ex 1: Find angular momentum if I=3,kg·m2 and ω=5,rad/s.
Solution: L = Iω = 3 × 5 = 15,kg·m2/s - Ex 2: Calculate kinetic energy for m=2,kg, v=4,m/s and I=2,kg·m2, ω=3,rad/s.
Solution: Linear KE = 1/2 × 2 × 42 = 16,J, Rotational KE = 1/2 × 2 × 32 = 9,J
Practice Set
- Q1: Moment of inertia corresponds to:
A) Mass
B) Force
C) Torque
D) Acceleration - Q2: Work done in rotational motion is:
A) Force × distance
B) Torque × angle
C) Mass × velocity
D) Force × velocity - Q3: Angular velocity ω is analogous to:
A) Linear displacement
B) Linear velocity
C) Linear acceleration
D) Force
Answer Key
- Q1: A - Moment of inertia is rotational equivalent of mass.
- Q2: B - Work done rotationally is torque times angle.
- Q3: B - Angular velocity corresponds to linear velocity.
Memory Aids
- Mass ↔ Moment of inertia
- Force ↔ Torque
- Velocity ↔ Angular velocity
- Work done: Force × distance ↔ Torque × angle
Key Points
- Linear motion: displacement, velocity, acceleration; Rotational motion: angular displacement, angular velocity, angular acceleration.
- Mass in linear motion corresponds to moment of inertia in rotation.
- Force causes linear acceleration; torque causes angular acceleration.
- Work done: linear = F × d, rotational = τ × θ.
- Kinetic energy: linear = 1/2mv2, rotational = 1/2Iω2.
- Power: linear = Fv, rotational = τω.
- Momentum: linear = mv, angular = Iω.
Solved Examples
- Ex 1: Find angular momentum if I=3,kg·m2 and ω=5,rad/s.
Solution: L = Iω = 3 × 5 = 15,kg·m2/s - Ex 2: Calculate kinetic energy for m=2,kg, v=4,m/s and I=2,kg·m2, ω=3,rad/s.
Solution: Linear KE = 1/2 × 2 × 42 = 16,J, Rotational KE = 1/2 × 2 × 32 = 9,J
Practice Set
- Q1: Moment of inertia corresponds to:
A) Mass
B) Force
C) Torque
D) Acceleration - Q2: Work done in rotational motion is:
A) Force × distance
B) Torque × angle
C) Mass × velocity
D) Force × velocity - Q3: Angular velocity ω is analogous to:
A) Linear displacement
B) Linear velocity
C) Linear acceleration
D) Force
Answer Key
- Q1: A - Moment of inertia is rotational equivalent of mass.
- Q2: B - Work done rotationally is torque times angle.
- Q3: B - Angular velocity corresponds to linear velocity.
Memory Aids
- Mass ↔ Moment of inertia
- Force ↔ Torque
- Velocity ↔ Angular velocity
- Work done: Force × distance ↔ Torque × angle
Key Points
- Linear motion: displacement, velocity, acceleration; Rotational motion: angular displacement, angular velocity, angular acceleration.
- Mass in linear motion corresponds to moment of inertia in rotation.
- Force causes linear acceleration; torque causes angular acceleration.
- Work done: linear \(= F \times d\), rotational \(= \tau \times \theta\).
- Kinetic energy: linear \(= \frac{1}{2}mv^2\), rotational \(= \frac{1}{2}I\omega^2\).
- Power: linear \(= Fv\), rotational \(= \tau \omega\).
- Momentum: linear \(= mv\), angular \(= I\omega\).
Solved Examples
- Ex 1: Find angular momentum if \(I=3\,kg\cdot m^2\) and \(\omega=5\,rad/s\).
Solution: \(L = I \omega = 3 \times 5 = 15\,kg\cdot m^2/s\) - Ex 2: Calculate kinetic energy for \(m=2\,kg\), \(v=4\,m/s\) and \(I=2\,kg\cdot m^2\), \(\omega=3\,rad/s\).
Solution: Linear KE = \(\frac{1}{2} \times 2 \times 4^2 = 16\,J\), Rotational KE = \(\frac{1}{2} \times 2 \times 3^2 = 9\,J\)
Practice Set
- Q1: Moment of inertia corresponds to:
A) Mass
B) Force
C) Torque
D) Acceleration - Q2: Work done in rotational motion is:
A) Force × distance
B) Torque × angle
C) Mass × velocity
D) Force × velocity - Q3: Angular velocity \(\omega\) is analogous to:
A) Linear displacement
B) Linear velocity
C) Linear acceleration
D) Force
Answer Key
- Q1: A - Moment of inertia is rotational equivalent of mass.
- Q2: B - Work done rotationally is torque times angle.
- Q3: B - Angular velocity corresponds to linear velocity.
Memory Aids
- Mass ↔ Moment of inertia
- Force ↔ Torque
- Velocity ↔ Angular velocity
- Work done: Force × distance ↔ Torque × angle
Angular Momentum Rotation Fixed Axis
General Expression
- Total angular momentum vector L = ∑i=1N vector ri × vector pi
- vector ri: position vector of particle i
- vector pi = mi vector vi: linear momentum of particle i
- Cross product gives vector perpendicular to vector ri and vector pi
- Sum over all particles gives total angular momentum
Angular Momentum for Particle at P
- Position vector: vector r = vector OP = vector OC + vector CP
- Momentum: vector p = m vector v
- Angular momentum: vector l = (vector OC × m vector v) + (vector CP × m vector v)
- vector CP × m vector v = r⊥ (mv) k̂ = Iz
Total Angular Momentum of Rigid Body
- vector L = ∑ vector li = ∑ lz + ∑ (vector OCi × mi vector vi) = vector Lz + vector L⊥
- vector Lz = ∑ r⊥ (mv) k̂ = ∑ (mr2)ω k̂ = Iω k̂
- Time derivative: dvector L/dt = dvector Lz/dt + dvector L⊥/dt
- Since dvector L⊥/dt = 0, dvector L/dt = dvector Lz/dt = d/dt (Iω k̂) = vector τ = I vector α
Solved Examples
- Ex 1: Calculate total angular momentum vector L for a particle with mass m, velocity vector v, and position vector vector r.
- Use vector L = vector r × m vector v
- Calculate cross product and magnitude
Practice Set
- Q1: Total angular momentum vector L is given by:
- A) ∑ mi vector vi
- B) ∑ vector ri × mi vector vi
- C) ∑ vector ri + mi vector vi
- D) ∑ mi vector ri
- Q2: For a particle at point P, angular momentum vector l is:
- A) vector OC × m vector v
- B) vector CP × m vector v
- C) Sum of vector OC × m vector v and vector CP × m vector v
- D) m vector v
- Q3: The torque vector τ is related to angular acceleration vector α by:
- A) vector τ = I vector α
- B) vector τ = m vector a
- C) vector τ = vector L
- D) vector τ = vector r × vector p
Answer Key
- Q1: B - Angular momentum is sum of cross products of position and momentum vectors.
- Q2: C - Angular momentum at P is sum of two cross products as per formula.
- Q3: A - Torque equals moment of inertia times angular acceleration.
Memory Aids
- Angular momentum vector L = ∑ vector r × m vector v
- Torque vector τ = I vector α
- Cross product gives perpendicular vector
General Expression
- Total angular momentum ⃗L = ∑i=1N ⃗ri × ⃗pi
- ⃗ri: position vector of particle i
- ⃗pi = mi ⃗vi: linear momentum of particle i
- Cross product gives vector perpendicular to ⃗ri and ⃗pi
- Sum over all particles gives total angular momentum
Angular Momentum for Particle at P
- Position vector: ⃗r = ⃗OP = ⃗OC + ⃗CP
- Momentum: ⃗p = m ⃗v
- Angular momentum: ⃗l = (⃗OC × m ⃗v) + (⃗CP × m ⃗v)
- ⃗CP × m ⃗v = r⊥ (mv) k̂ = Iz
Total Angular Momentum of Rigid Body
- ⃗L = ∑ ⃗li = ∑ lz + ∑ (⃗OCi × mi ⃗vi) = ⃗Lz + ⃗L⊥
- ⃗Lz = ∑ r⊥ (mv) k̂ = ∑ (mr2)ω k̂ = Iω k̂
- Time derivative: d⃗L/dt = d⃗Lz/dt + d⃗L⊥/dt
- Since d⃗L⊥/dt = 0, d⃗L/dt = d⃗Lz/dt = d/dt (Iω k̂) = ⃗τ = I ⃗α
Solved Examples
- Ex 1: Calculate total angular momentum ⃗L for a particle with mass m, velocity ⃗v, and position vector ⃗r.
- Use ⃗L = ⃗r × m ⃗v
- Calculate cross product and magnitude
Practice Set
- Q1: Total angular momentum ⃗L is given by:
- A) ∑ mi ⃗vi
- B) ∑ ⃗ri × mi ⃗vi
- C) ∑ ⃗ri + mi ⃗vi
- D) ∑ mi ⃗ri
- Q2: For a particle at point P, angular momentum ⃗l is:
- A) ⃗OC × m ⃗v
- B) ⃗CP × m ⃗v
- C) Sum of ⃗OC × m ⃗v and ⃗CP × m ⃗v
- D) m ⃗v
- Q3: The torque ⃗τ is related to angular acceleration ⃗α by:
- A) ⃗τ = I ⃗α
- B) ⃗τ = m ⃗a
- C) ⃗τ = ⃗L
- D) ⃗τ = ⃗r × ⃗p
Answer Key
- Q1: B - Angular momentum is sum of cross products of position and momentum vectors.
- Q2: C - Angular momentum at P is sum of two cross products as per formula.
- Q3: A - Torque equals moment of inertia times angular acceleration.
Memory Aids
- Angular momentum ⃗L = ∑ ⃗r × m ⃗v
- Torque ⃗τ = I ⃗α
- Cross product gives perpendicular vector
General Expression
- Total angular momentum vector L = ∑i=1N vector ri × vector pi
- vector ri: position vector of particle i
- vector pi = mi vector vi: linear momentum of particle i
- Cross product gives vector perpendicular to vector ri and vector pi
- Sum over all particles gives total angular momentum
Angular Momentum for Particle at P
- Position vector: vector r = vector OP = vector OC + vector CP
- Momentum: vector p = m vector v
- Angular momentum: vector l = (vector OC × m vector v) + (vector CP × m vector v)
- vector CP × m vector v = r⊥ (mv) k̂ = Iz
Total Angular Momentum of Rigid Body
- vector L = ∑ vector li = ∑ lz + ∑ (vector OCi × mi vector vi) = vector Lz + vector L⊥
- vector Lz = ∑ r⊥ (mv) k̂ = ∑ (mr2)ω k̂ = Iω k̂
- Time derivative: dvector L/dt = dvector Lz/dt + dvector L⊥/dt
- Since dvector L⊥/dt = 0, dvector L/dt = dvector Lz/dt = d/dt (Iω k̂) = vector τ = I vector α
Solved Examples
- Ex 1: Calculate total angular momentum vector L for a particle with mass m, velocity vector v, and position vector vector r.
- Use vector L = vector r × m vector v
- Calculate cross product and magnitude
Practice Set
- Q1: Total angular momentum vector L is given by:
- A) ∑ mi vector vi
- B) ∑ vector ri × mi vector vi
- C) ∑ vector ri + mi vector vi
- D) ∑ mi vector ri
- Q2: For a particle at point P, angular momentum vector l is:
- A) vector OC × m vector v
- B) vector CP × m vector v
- C) Sum of vector OC × m vector v and vector CP × m vector v
- D) m vector v
- Q3: The torque vector τ is related to angular acceleration vector α by:
- A) vector τ = I vector α
- B) vector τ = m vector a
- C) vector τ = vector L
- D) vector τ = vector r × vector p
Answer Key
- Q1: B - Angular momentum is sum of cross products of position and momentum vectors.
- Q2: C - Angular momentum at P is sum of two cross products as per formula.
- Q3: A - Torque equals moment of inertia times angular acceleration.
Memory Aids
- Angular momentum vector L = ∑ vector r × m vector v
- Torque vector τ = I vector α
- Cross product gives perpendicular vector
General Expression
- Total angular momentum \( \vec{L} = \sum_{i=1}^N \vec{r_i} \times \vec{p_i} \)
- \( \vec{r_i} \): position vector of particle \(i\)
- \( \vec{p_i} = m_i \vec{v_i} \): linear momentum of particle \(i\)
- Cross product gives vector perpendicular to \( \vec{r_i} \) and \( \vec{p_i} \)
- Sum over all particles gives total angular momentum
Angular Momentum for Particle at P
- Position vector: \( \vec{r} = \vec{OP} = \vec{OC} + \vec{CP} \)
- Momentum: \( \vec{p} = m \vec{v} \)
- Angular momentum: \( \vec{l} = (\vec{OC} \times m \vec{v}) + (\vec{CP} \times m \vec{v}) \)
- \( \vec{CP} \times m \vec{v} = r_\perp (mv) \hat{k} = I_z \)
Total Angular Momentum of Rigid Body
- \( \vec{L} = \sum \vec{l_i} = \sum l_z + \sum (\vec{OC_i} \times m_i \vec{v_i}) = \vec{L_z} + \vec{L_\perp} \)
- \( \vec{L_z} = \sum r_\perp (mv) \hat{k} = \sum (mr^2) \omega \hat{k} = I \omega \hat{k} \)
- Time derivative: \( \frac{d\vec{L}}{dt} = \frac{d\vec{L_z}}{dt} + \frac{d\vec{L_\perp}}{dt} \)
- Since \( \frac{d\vec{L_\perp}}{dt} = 0 \), \( \frac{d\vec{L}}{dt} = \frac{d\vec{L_z}}{dt} = \frac{d}{dt} (I \omega \hat{k}) = \vec{\tau} = I \vec{\alpha} \)
Solved Examples
- Ex 1: Calculate total angular momentum \( \vec{L} \) for a particle with mass \(m\), velocity \(\vec{v}\), and position vector \(\vec{r}\).
- Use \( \vec{L} = \vec{r} \times m \vec{v} \)
- Calculate cross product and magnitude
Practice Set
- Q1: Total angular momentum \( \vec{L} \) is given by:
- A) \( \sum m_i \vec{v_i} \)
- B) \( \sum \vec{r_i} \times m_i \vec{v_i} \)
- C) \( \sum \vec{r_i} + m_i \vec{v_i} \)
- D) \( \sum m_i \vec{r_i} \)
- Q2: For a particle at point P, angular momentum \( \vec{l} \) is:
- A) \( \vec{OC} \times m \vec{v} \)
- B) \( \vec{CP} \times m \vec{v} \)
- C) Sum of \( \vec{OC} \times m \vec{v} \) and \( \vec{CP} \times m \vec{v} \)
- D) \( m \vec{v} \)
- Q3: The torque \( \vec{\tau} \) is related to angular acceleration \( \vec{\alpha} \) by:
- A) \( \vec{\tau} = I \vec{\alpha} \)
- B) \( \vec{\tau} = m \vec{a} \)
- C) \( \vec{\tau} = \vec{L} \)
- D) \( \vec{\tau} = \vec{r} \times \vec{p} \)
Answer Key
- Q1: B - Angular momentum is sum of cross products of position and momentum vectors.
- Q2: C - Angular momentum at P is sum of two cross products as per formula.
- Q3: A - Torque equals moment of inertia times angular acceleration.
Memory Aids
- Angular momentum \( \vec{L} = \sum \vec{r} \times m \vec{v} \)
- Torque \( \vec{\tau} = I \vec{\alpha} \)
- Cross product gives perpendicular vector
Rolling Motion
Definition and Conditions
- Rolling = rotation + translation
- Pure rolling: velocity of contact point with surface = 0
- Velocity relation: vCM = RωCM
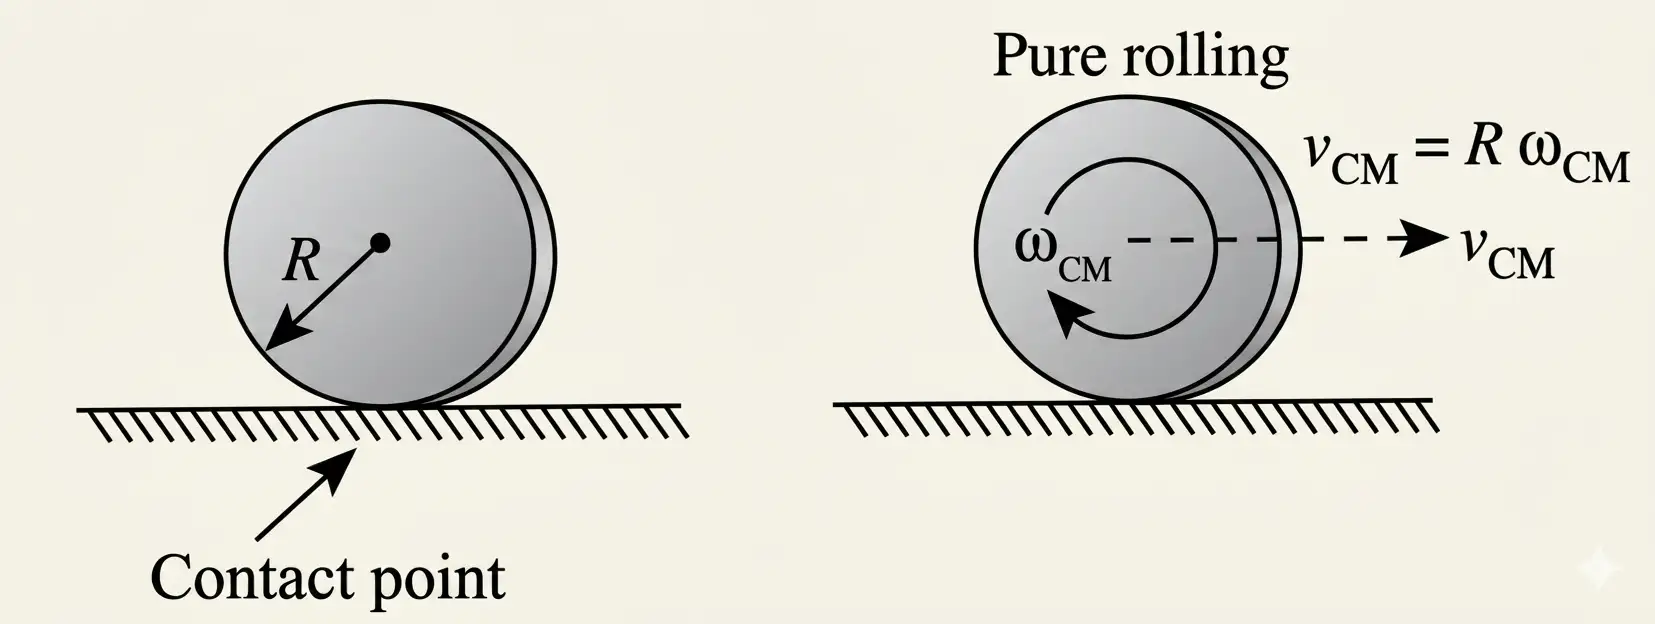
Velocity of Points on Rolling Body
- Velocity of any point: vector v = vector vCM + vector ω × vector R
- At point A: vector vA = 2 vector vCM
- At point B: vector vB = 3/2 vector vCM
- At point C: vector vC = vector vCM
- At point D: vector vD = 3/4 vector vCM
- At point E (contact point): vector vE = 0
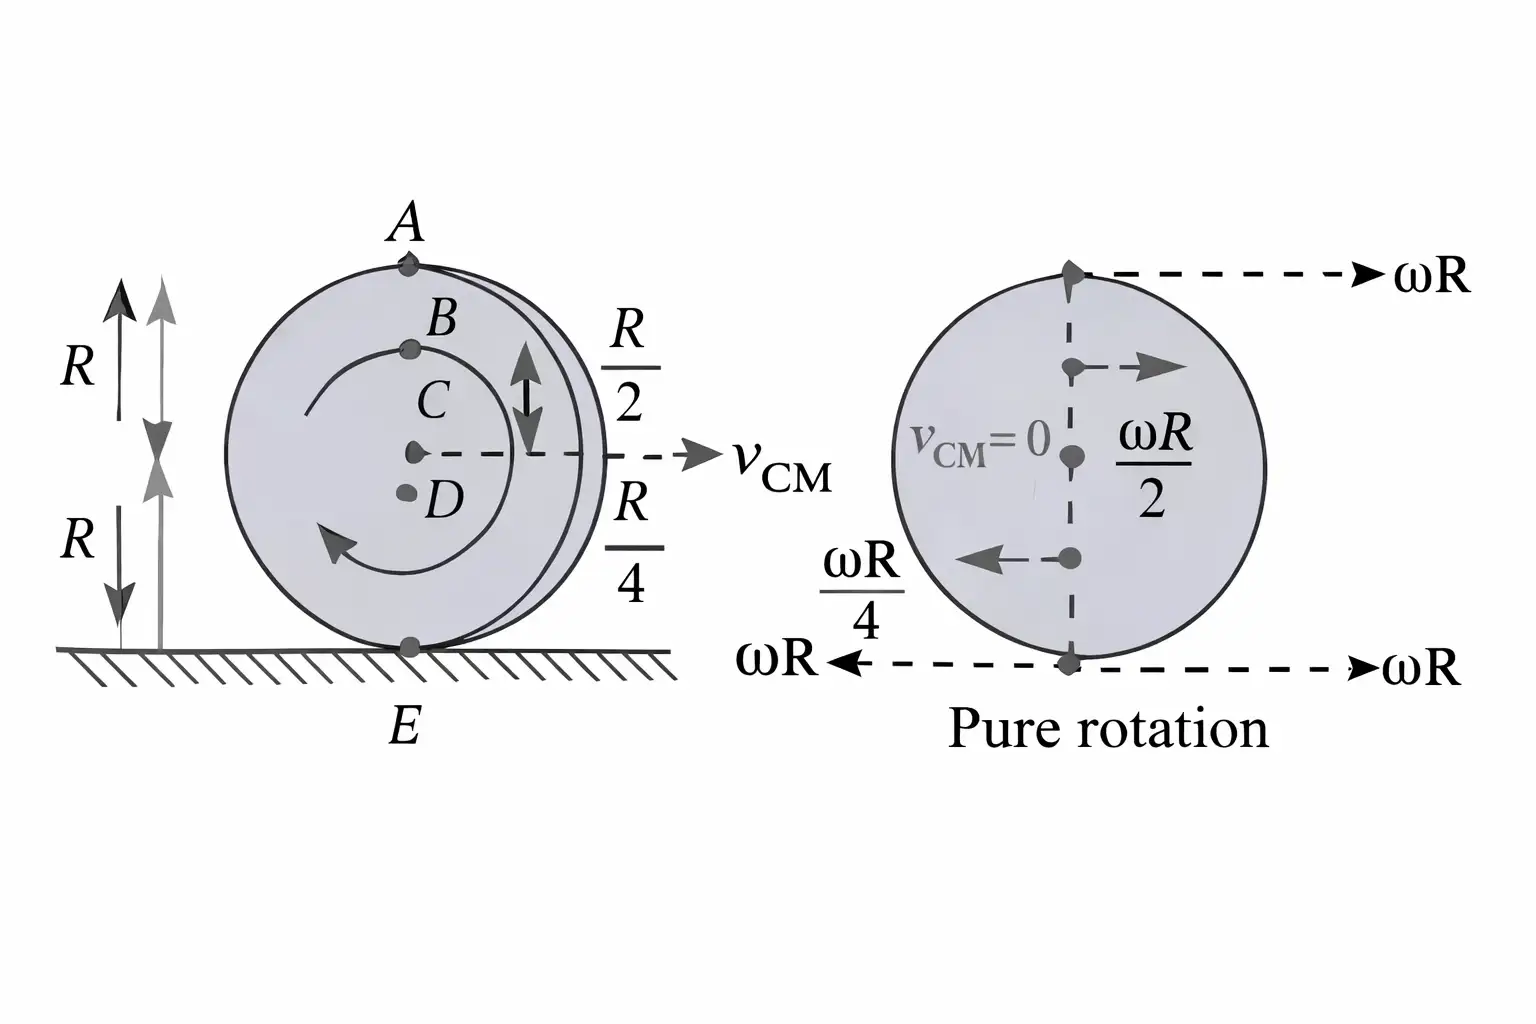
Kinetic Energy in Rolling
- K = 1/2 Iω2 + 1/2 mvCM2 = 1/2 mvCM2 (1 + k2/R2)
- Energy ratio: Ktranslation : Krotation : Krolling = 1 : k2/R2 : (1 + k2/R2)
Solved Examples
- Ex 1: Calculate velocity at point A on rolling wheel with vCM = 5 m/s.
- vA = 2 vCM = 10 m/s
Practice Set
- Q1: Pure rolling means:
- A) Contact point velocity = vCM
- B) Contact point velocity = 0
- C) Wheel does not rotate
- D) Wheel slips on surface
- Q2: Velocity at top point A of rolling wheel is:
- A) vCM
- B) 2 vCM
- C) 1/2 vCM
- D) 0
- Q3: Kinetic energy of rolling is:
- A) 1/2 mvCM2
- B) 1/2 Iω2
- C) 1/2 mvCM2 (1 + k2/R2)
- D) mvCM2
Answer Key
- Q1: B - Pure rolling means zero velocity at contact point.
- Q2: B - Velocity at top is twice the center velocity.
- Q3: C - Rolling kinetic energy includes translation and rotation parts.
Memory Aids
- Pure rolling: vcontact = 0
- Velocity top point = 2 vCM
- Energy: K = 1/2 mvCM2 (1 + k2/R2)
Definition and Conditions
- Rolling = rotation + translation
- Pure rolling: velocity of contact point with surface = 0
- Velocity relation: vCM = RωCM
Velocity of Points on Rolling Body
- Velocity of any point: vector v = vector vCM + vector ω × vector R
- At point A: vector vA = 2 vector vCM
- At point B: vector vB = 3/2 vector vCM
- At point C: vector vC = vector vCM
- At point D: vector vD = 3/4 vector vCM
- At point E (contact point): vector vE = 0
Kinetic Energy in Rolling
- K = 1/2 Iω2 + 1/2 mvCM2 = 1/2 mvCM2 (1 + k2/R2)
- Energy ratio: Ktranslation : Krotation : Krolling = 1 : k2/R2 : (1 + k2/R2)
Solved Examples
- Ex 1: Calculate velocity at point A on rolling wheel with vCM = 5 m/s.
- vA = 2 vCM = 10 m/s
Practice Set
- Q1: Pure rolling means:
- A) Contact point velocity = vCM
- B) Contact point velocity = 0
- C) Wheel does not rotate
- D) Wheel slips on surface
- Q2: Velocity at top point A of rolling wheel is:
- A) vCM
- B) 2 vCM
- C) 1/2 vCM
- D) 0
- Q3: Kinetic energy of rolling is:
- A) 1/2 mvCM2
- B) 1/2 Iω2
- C) 1/2 mvCM2 (1 + k2/R2)
- D) mvCM2
Answer Key
- Q1: B - Pure rolling means zero velocity at contact point.
- Q2: B - Velocity at top is twice the center velocity.
- Q3: C - Rolling kinetic energy includes translation and rotation parts.
Memory Aids
- Pure rolling: vcontact = 0
- Velocity top point = 2 vCM
- Energy: K = 1/2 mvCM2 (1 + k2/R2)
Definition and Conditions
- Rolling = rotation + translation
- Pure rolling: velocity of contact point with surface = 0
- Velocity relation: \( v_{CM} = R \omega_{CM} \)
Velocity of Points on Rolling Body
- Velocity of any point: \( \vec{v} = \vec{v}_{CM} + \vec{\omega} \times \vec{R} \)
- At point A: \( \vec{v}_A = 2 \vec{v}_{CM} \)
- At point B: \( \vec{v}_B = \frac{3}{2} \vec{v}_{CM} \)
- At point C: \( \vec{v}_C = \vec{v}_{CM} \)
- At point D: \( \vec{v}_D = \frac{3}{4} \vec{v}_{CM} \)
- At point E (contact point): \( \vec{v}_E = 0 \)
Kinetic Energy in Rolling
- \( K = \frac{1}{2} I \omega^2 + \frac{1}{2} m v_{CM}^2 = \frac{1}{2} m v_{CM}^2 \left(1 + \frac{k^2}{R^2}\right) \)
- Energy ratio: \( K_{translation} : K_{rotation} : K_{rolling} = 1 : \frac{k^2}{R^2} : \left(1 + \frac{k^2}{R^2}\right) \)
Solved Examples
- Ex 1: Calculate velocity at point A on rolling wheel with \( v_{CM} = 5 \mathrm{m/s} \).
- \( v_A = 2 v_{CM} = 10 \mathrm{m/s} \)
Practice Set
- Q1: Pure rolling means:
- A) Contact point velocity = \( v_{CM} \)
- B) Contact point velocity = 0
- C) Wheel does not rotate
- D) Wheel slips on surface
- Q2: Velocity at top point A of rolling wheel is:
- A) \( v_{CM} \)
- B) \( 2 v_{CM} \)
- C) \( \frac{1}{2} v_{CM} \)
- D) 0
- Q3: Kinetic energy of rolling is:
- A) \( \frac{1}{2} m v_{CM}^2 \)
- B) \( \frac{1}{2} I \omega^2 \)
- C) \( \frac{1}{2} m v_{CM}^2 \left(1 + \frac{k^2}{R^2}\right) \)
- D) \( m v_{CM}^2 \)
Answer Key
- Q1: B - Pure rolling means zero velocity at contact point.
- Q2: B - Velocity at top is twice the center velocity.
- Q3: C - Rolling kinetic energy includes translation and rotation parts.
Memory Aids
- Pure rolling: \( v_{contact} = 0 \)
- Velocity top point = \( 2 v_{CM} \)
- Energy: \( K = \frac{1}{2} m v_{CM}^2 (1 + \frac{k^2}{R^2}) \)
Motion Spherical Body Rough Inclined
Friction and Rolling on Incline
- Minimum friction for pure rolling: μmin = tan θ / (1 + mR2/I)
- If μ = 0, body slips down with acceleration a = g sin θ
- If μ > μmin, pure rolling with acceleration a2 = g sin θ / (1 + I/mR2)
- Friction force magnitude: f = mg sin θ / (1 + mR2/I) (acts upward)
- If μ < μmin, rolling with slipping, acceleration a3 = g sin θ - μg cos θ
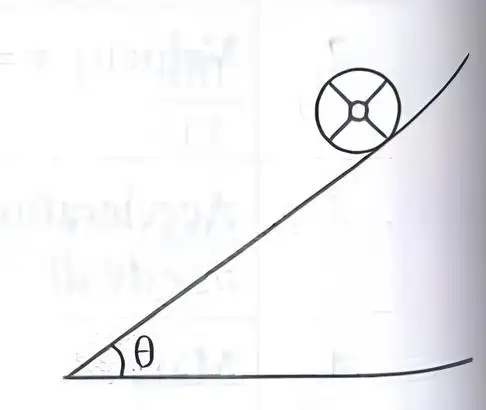
Comparison Pure Rolling vs Pure Sliding
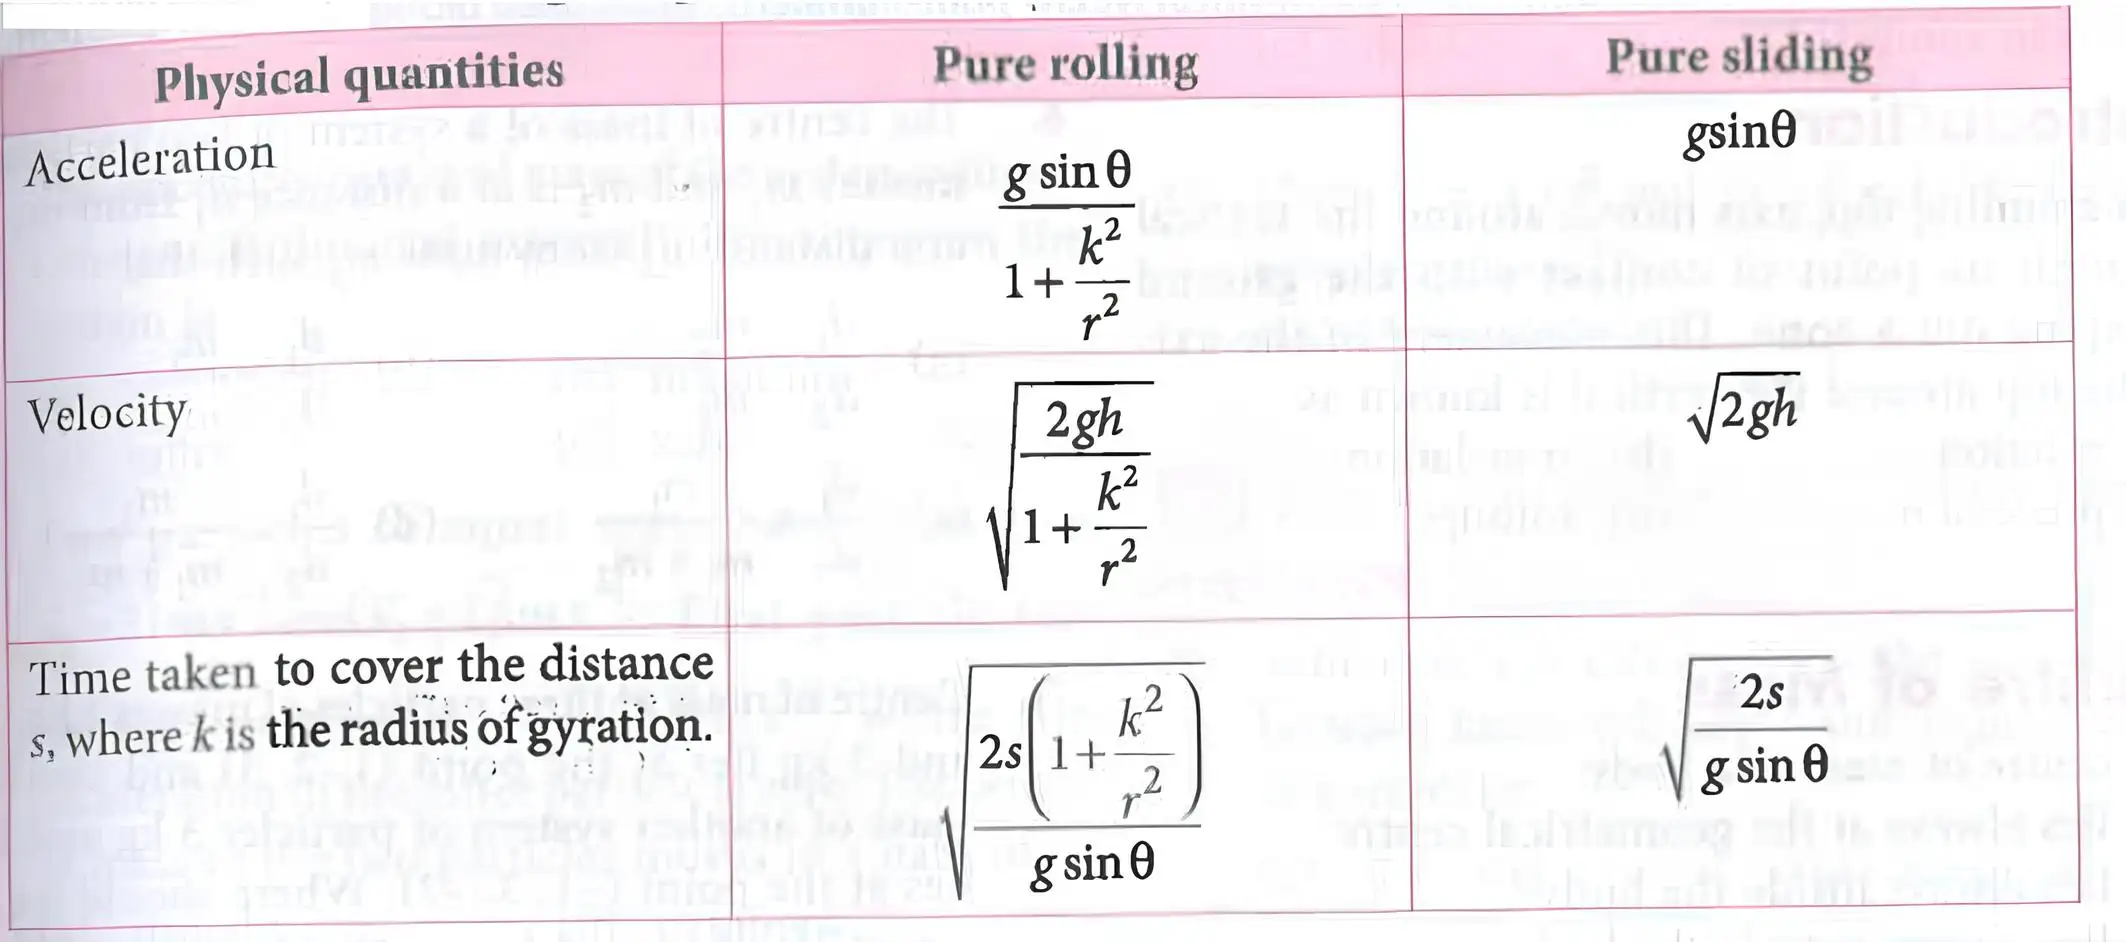
- Acceleration: Rolling < Sliding
- Velocity: Rolling < Sliding
- Time to cover distance: Rolling > Sliding
- Rolling involves rotational inertia, sliding does not
Solved Examples
- Ex 1: Calculate minimum friction coefficient for pure rolling on incline θ = 30°, m = 2 kg, R = 0.5 m, I = 0.25 m R2.
- Use μmin = tan θ / (1 + mR2/I)
- Calculate and substitute values
Practice Set
- Q1: Minimum friction for pure rolling depends on:
- A) tan θ only
- B) m, R, I only
- C) tan θ and mR2/I
- D) None of these
- Q2: If μ = 0, acceleration of body on incline is:
- A) 0
- B) g cos θ
- C) g sin θ
- D) g sin θ / (1 + I/mR2)
- Q3: If μ < μmin, acceleration is:
- A) g sin θ
- B) g sin θ - μg cos θ
- C) g sin θ / (1 + I/mR2)
- D) 0
Answer Key
- Q1: C - Minimum friction depends on slope angle and inertia ratio mR2/I
- Q2: C - Without friction, body slips with acceleration g sin θ
- Q3: B - Rolling with slipping acceleration includes friction term
Memory Aids
- μmin = tan θ / (1 + mR2/I)
- Slip if μ = 0, acceleration g sin θ
- Rolling acceleration < sliding acceleration
Friction and Rolling on Incline
- Minimum friction for pure rolling: μmin = tan θ / (1 + mR2/I)
- If μ = 0, body slips down with acceleration a = g sin θ
- If μ > μmin, pure rolling with acceleration a2 = g sin θ / (1 + I/mR2)
- Friction force magnitude: f = mg sin θ / (1 + mR2/I) (acts upward)
- If μ < μmin, rolling with slipping, acceleration a3 = g sin θ - μg cos θ
Comparison Pure Rolling vs Pure Sliding
- Acceleration: Rolling < Sliding
- Velocity: Rolling < Sliding
- Time to cover distance: Rolling > Sliding
- Rolling involves rotational inertia, sliding does not
Solved Examples
- Ex 1: Calculate minimum friction coefficient for pure rolling on incline θ = 30°, m = 2 kg, R = 0.5 m, I = 0.25 m R2.
- Use μmin = tan θ / (1 + mR2/I)
- Calculate and substitute values
Practice Set
- Q1: Minimum friction for pure rolling depends on:
- A) tan θ only
- B) m, R, I only
- C) tan θ and mR2/I
- D) None of these
- Q2: If μ = 0, acceleration of body on incline is:
- A) 0
- B) g cos θ
- C) g sin θ
- D) g sin θ / (1 + I/mR2)
- Q3: If μ < μmin, acceleration is:
- A) g sin θ
- B) g sin θ - μg cos θ
- C) g sin θ / (1 + I/mR2)
- D) 0
Answer Key
- Q1: C - Minimum friction depends on slope angle and inertia ratio mR2/I
- Q2: C - Without friction, body slips with acceleration g sin θ
- Q3: B - Rolling with slipping acceleration includes friction term
Memory Aids
- μmin = tan θ / (1 + mR2/I)
- Slip if μ = 0, acceleration g sin θ
- Rolling acceleration < sliding acceleration
Friction and Rolling on Incline
- Minimum friction for pure rolling: \( \mu_{min} = \frac{\tan \theta}{1 + \frac{mR^2}{I}} \)
- If \( \mu = 0 \), body slips down with acceleration \( a = g \sin \theta \)
- If \( \mu > \mu_{min} \), pure rolling with acceleration \( a_2 = \frac{g \sin \theta}{1 + \frac{I}{mR^2}} \)
- Friction force magnitude: \( f = \frac{mg \sin \theta}{1 + \frac{mR^2}{I}} \) (acts upward)
- If \( \mu < \mu_{min} \), rolling with slipping, acceleration \( a_3 = g \sin \theta - \mu g \cos \theta \)
Comparison Pure Rolling vs Pure Sliding
- Acceleration: Rolling \( < \) Sliding
- Velocity: Rolling \( < \) Sliding
- Time to cover distance: Rolling \( > \) Sliding
- Rolling involves rotational inertia, sliding does not
Solved Examples
- Ex 1: Calculate minimum friction coefficient for pure rolling on incline \( \theta = 30^\circ \), \( m = 2 \mathrm{kg} \), \( R = 0.5 \mathrm{m} \), \( I = 0.25 m R^2 \).
- Use \( \mu_{min} = \frac{\tan \theta}{1 + \frac{mR^2}{I}} \)
- Calculate and substitute values
Practice Set
- Q1: Minimum friction for pure rolling depends on:
- A) \( \tan \theta \) only
- B) \( m, R, I \) only
- C) \( \tan \theta \) and \( \frac{mR^2}{I} \)
- D) None of these
- Q2: If \( \mu = 0 \), acceleration of body on incline is:
- A) 0
- B) \( g \cos \theta \)
- C) \( g \sin \theta \)
- D) \( \frac{g \sin \theta}{1 + \frac{I}{mR^2}} \)
- Q3: If \( \mu < \mu_{min} \), acceleration is:
- A) \( g \sin \theta \)
- B) \( g \sin \theta - \mu g \cos \theta \)
- C) \( \frac{g \sin \theta}{1 + \frac{I}{mR^2}} \)
- D) 0
Answer Key
- Q1: C - Minimum friction depends on slope angle and inertia ratio \( \frac{mR^2}{I} \)
- Q2: C - Without friction, body slips with acceleration \( g \sin \theta \)
- Q3: B - Rolling with slipping acceleration includes friction term
Memory Aids
- \( \mu_{min} = \frac{\tan \theta}{1 + \frac{mR^2}{I}} \)
- Slip if \( \mu = 0 \), acceleration \( g \sin \theta \)
- Rolling acceleration \( < \) sliding acceleration
NEET Physics — ALL CHAPTERS
1
Basic Mathematics
2
Units and Measurement
3
Motion in a Straight Line
4
Motion in a Plane
5
Laws of Motion
6
Work, Energy and Power
7
System of Particles and Rotational Motion
8
Gravitation
9
Mechanical Properties of Solids
10
Mechanical Properties of Fluids
11
Thermal Properties of Matter
12
Thermodynamics
13
Kinetic Theory
14
Oscillations
15
Waves
16
Electric Charges and Fields
17
Electrostatic Potential and Capacitance
18
Current Electricity
19
Moving Charges and Magnetism
20
Magnetism and Matter
21
Electromagnetic Induction
22
Alternating Current
23
Electromagnetic Waves
24
Ray Optics and Optical Instruments
25
Wave Optics
26
Dual Nature of Radiation and Matter
27
Atoms
28
Nuclei
29
Semiconductor Electronics: Materials, Devices and Simple Circuits